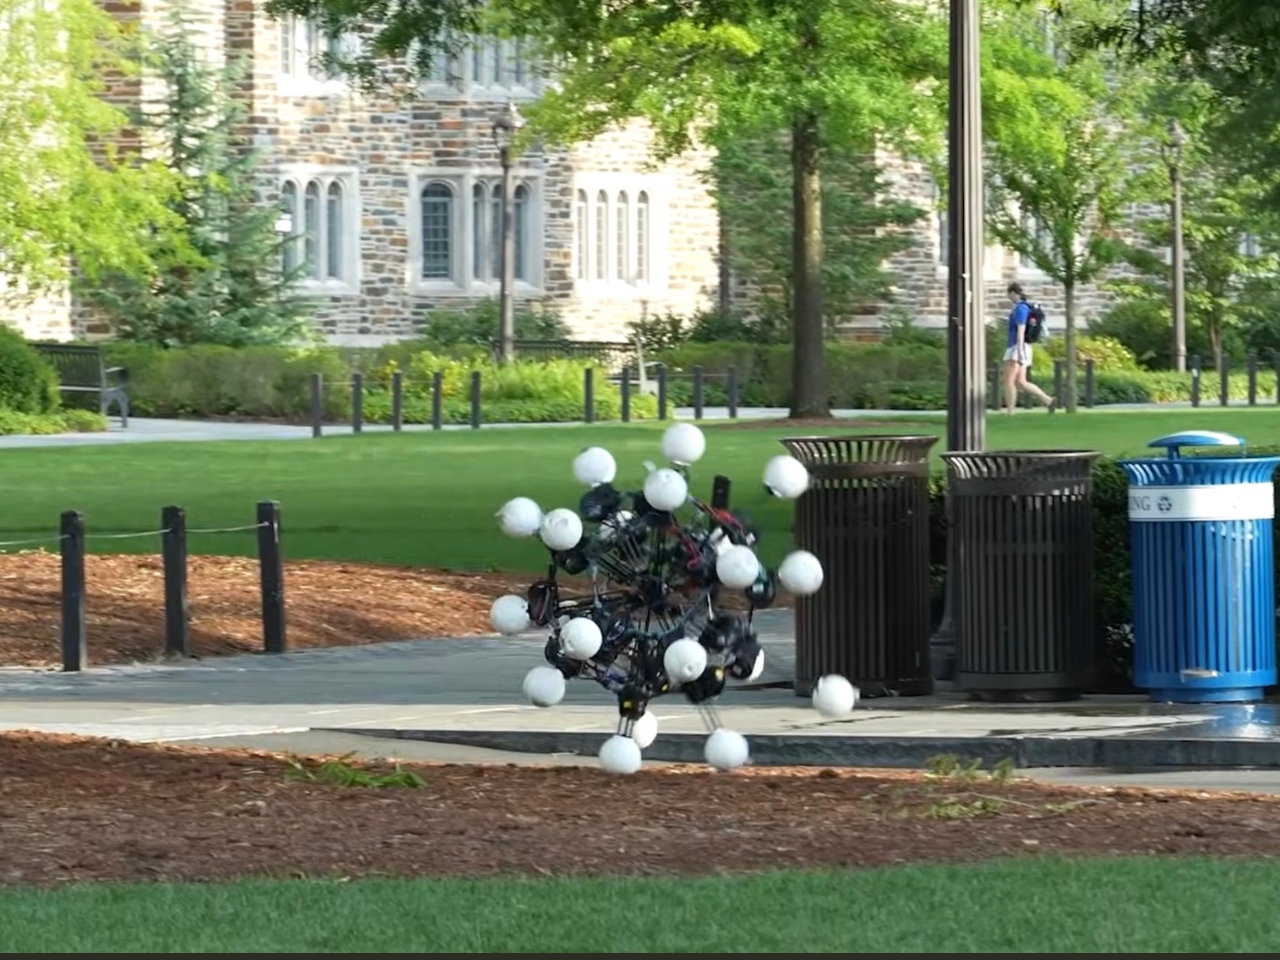
The Air Purifier That Rolls Toward Smoke Before It Fills the Room

Air purifiers have quietly become household staples, tucked into corners and set to auto, doing their work without much acknowledgment. The fundamental assumption behind every stationary model is that polluted air will eventually drift past the filter if you wait long enough. That’s not entirely wrong, but it means the unit is always reacting to something that’s already spread rather than catching it at the source.

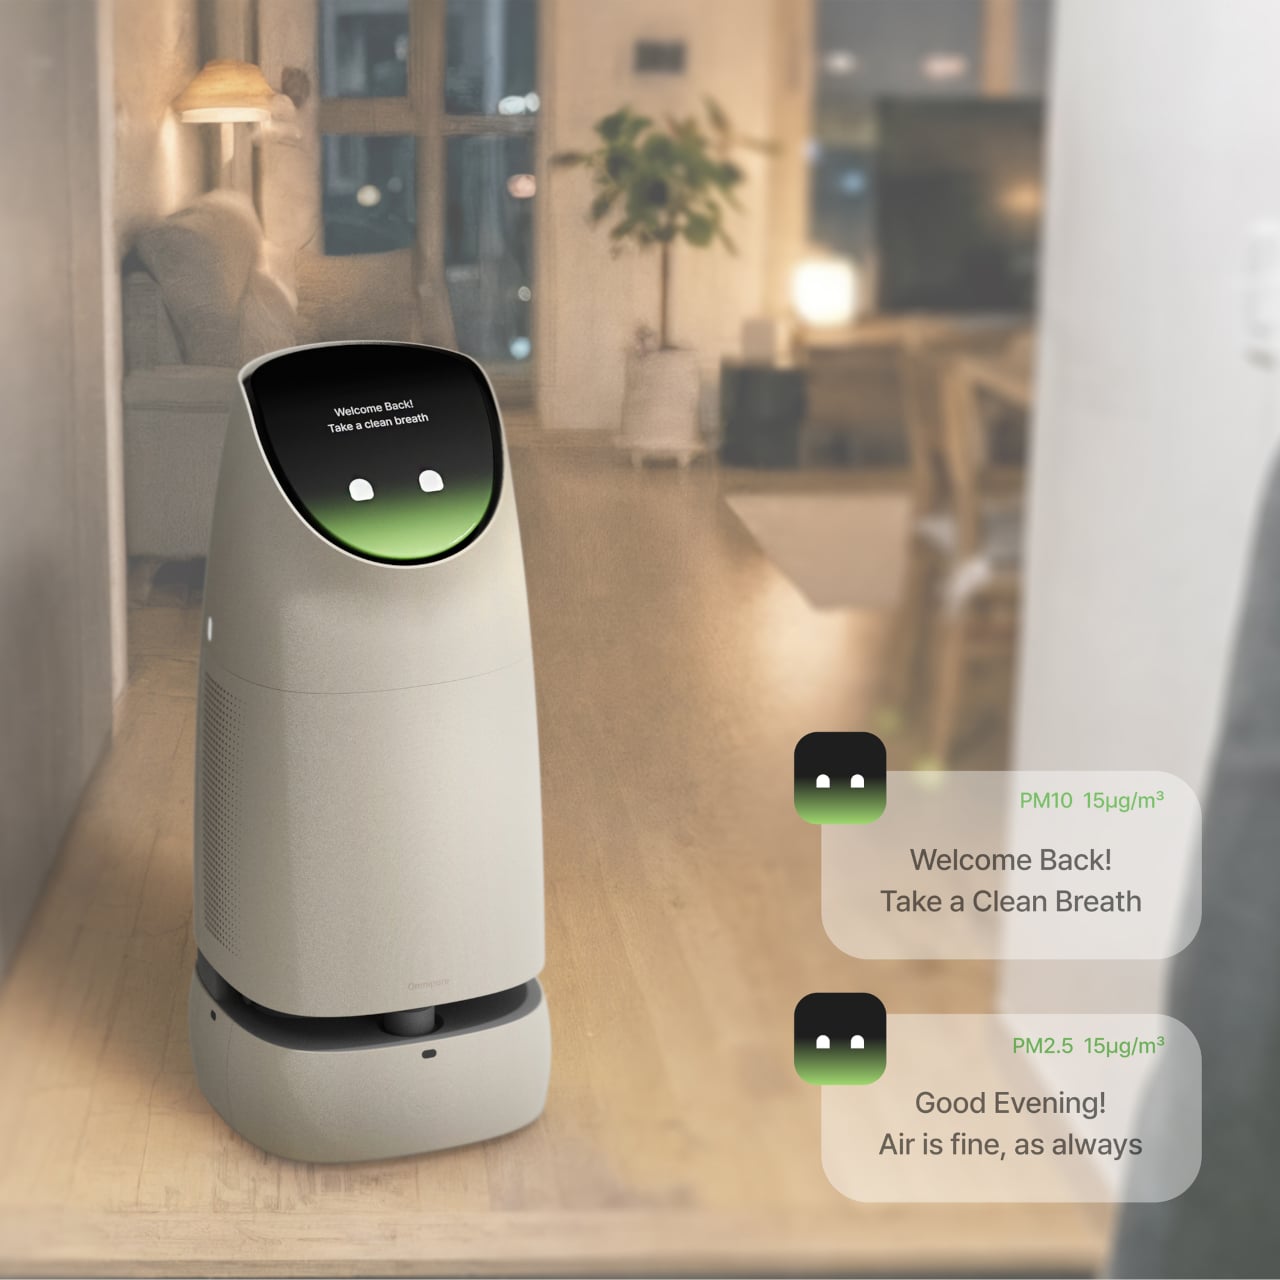
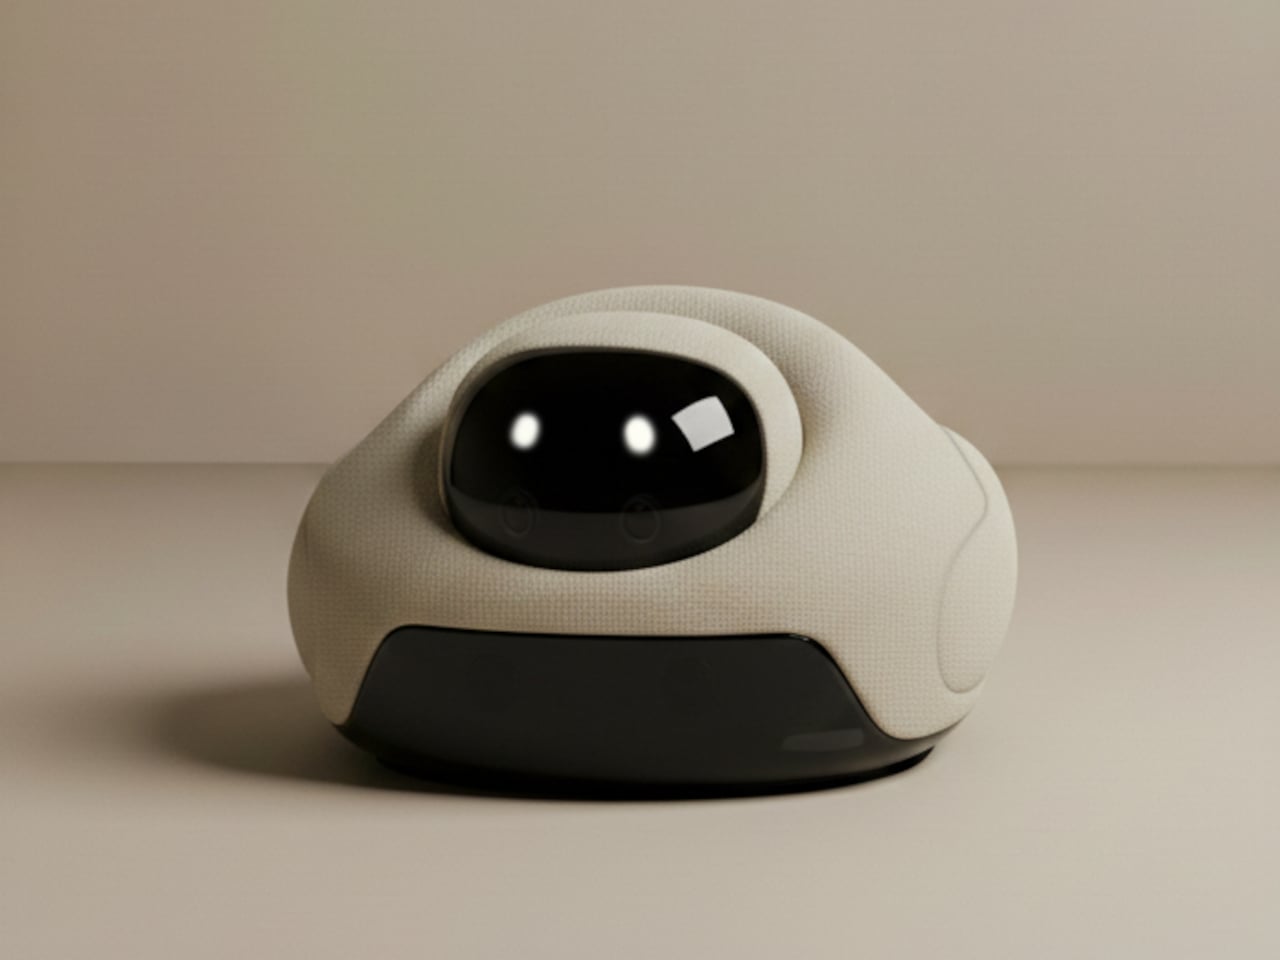
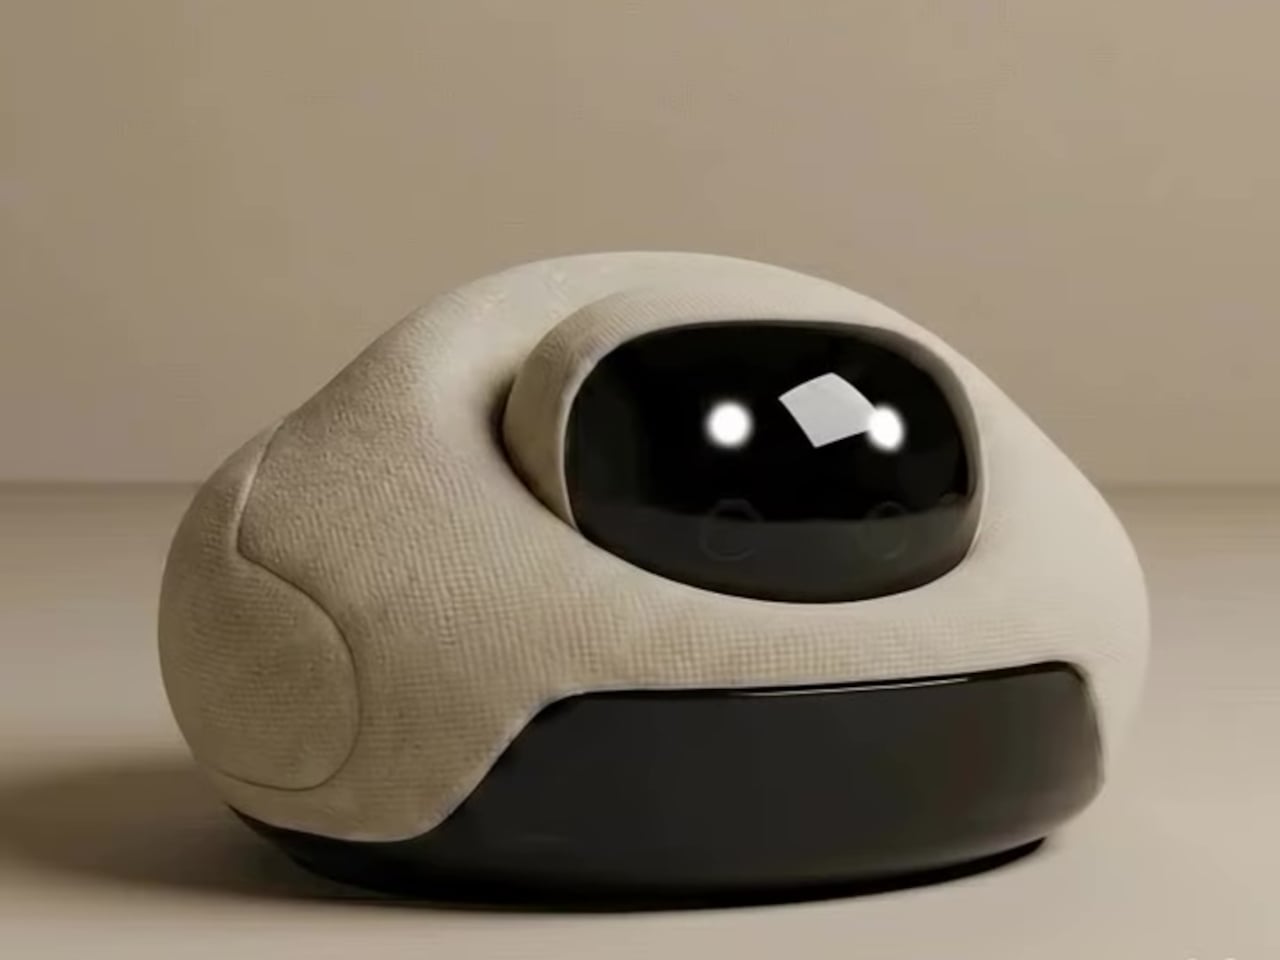
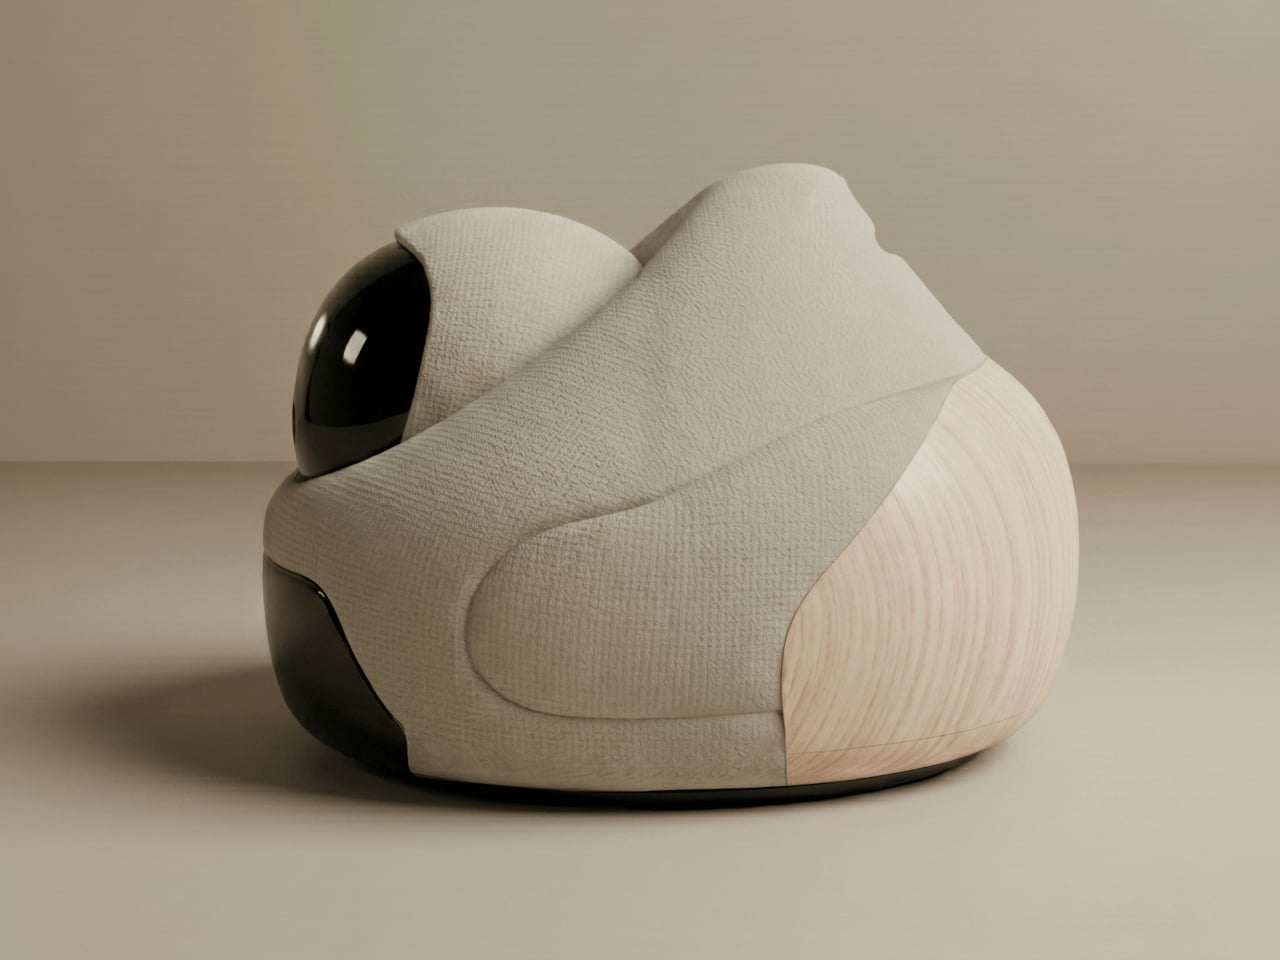
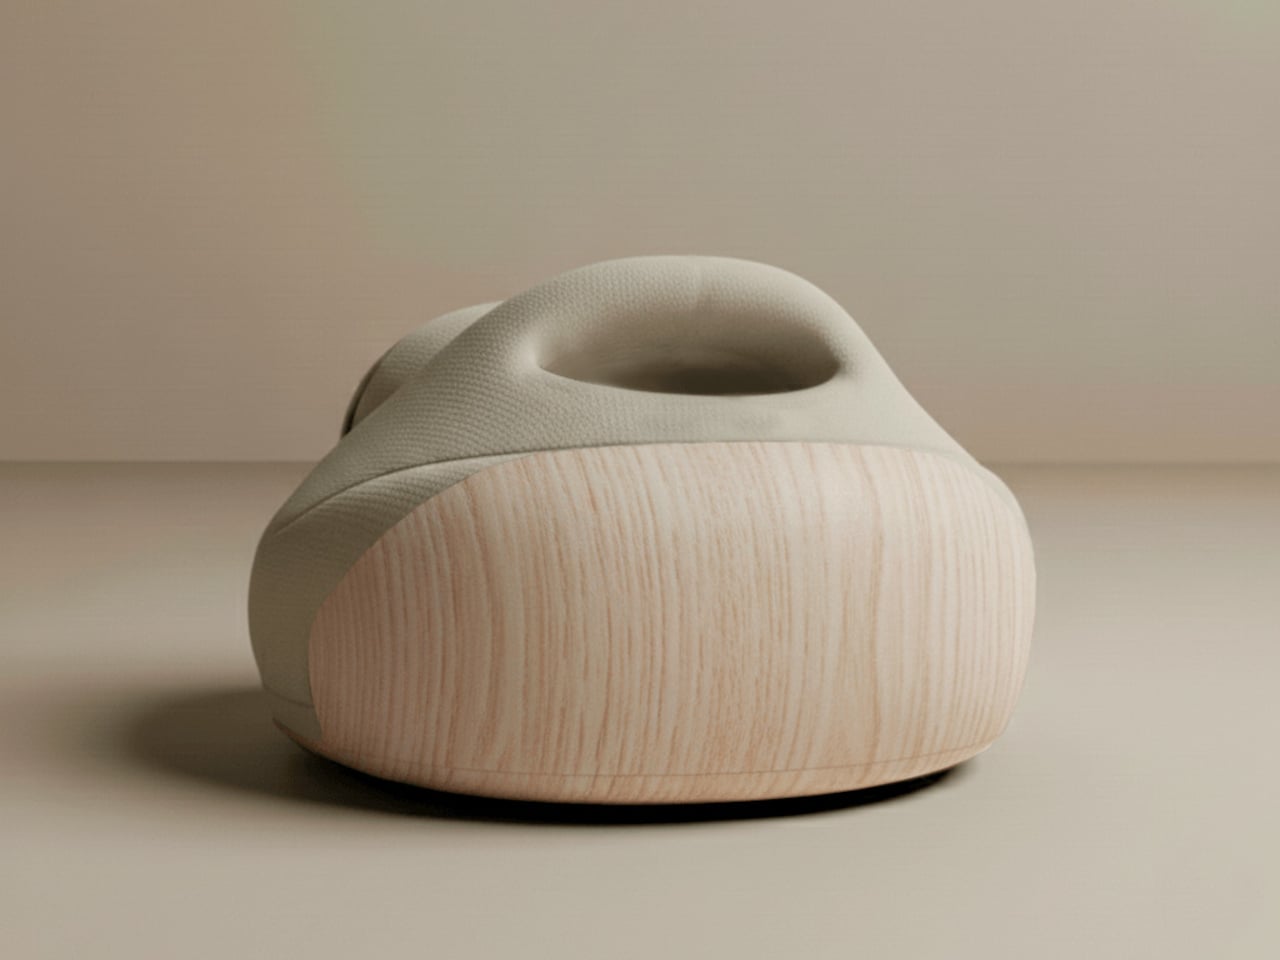
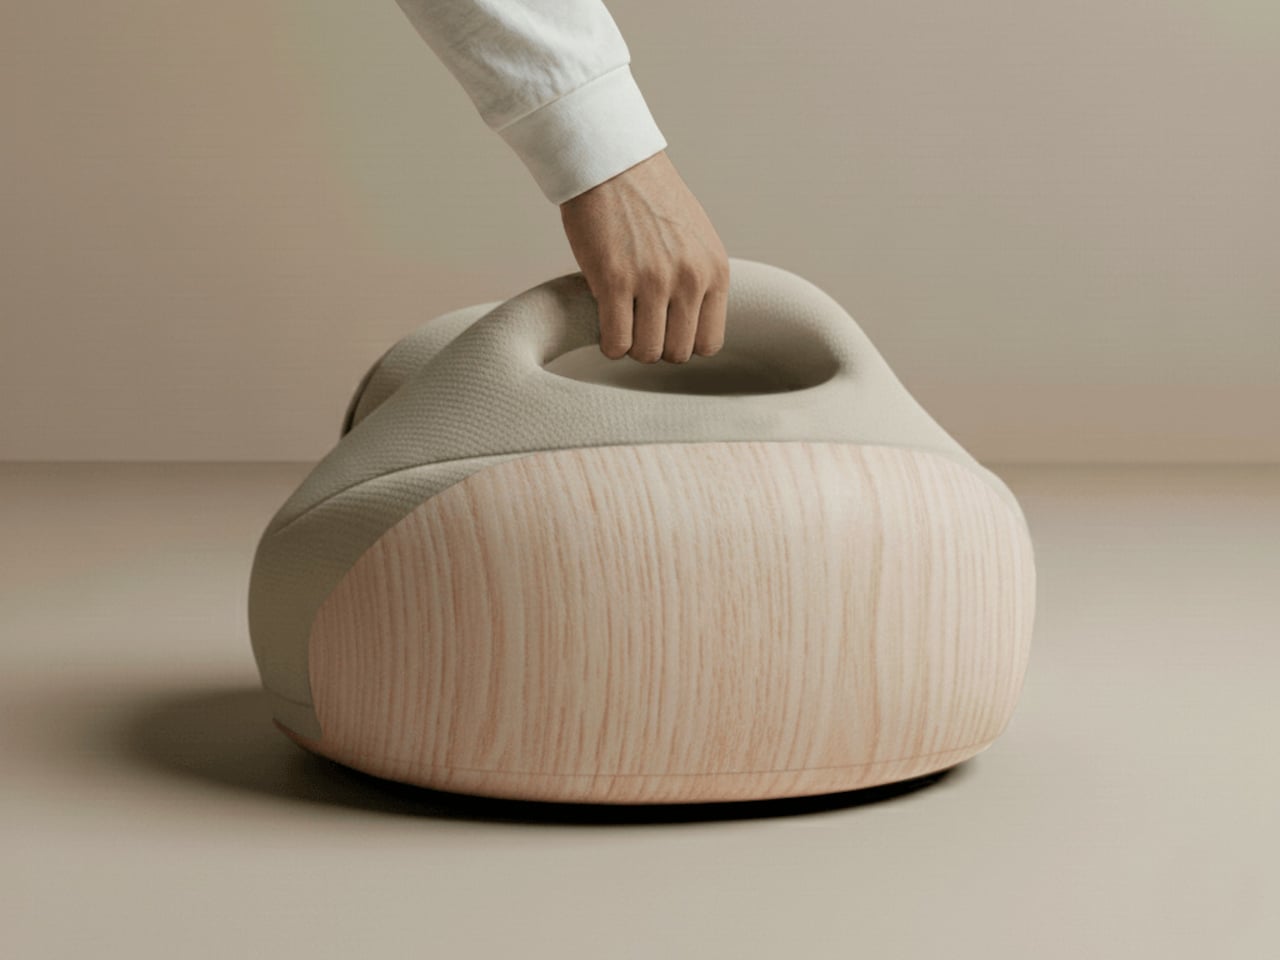
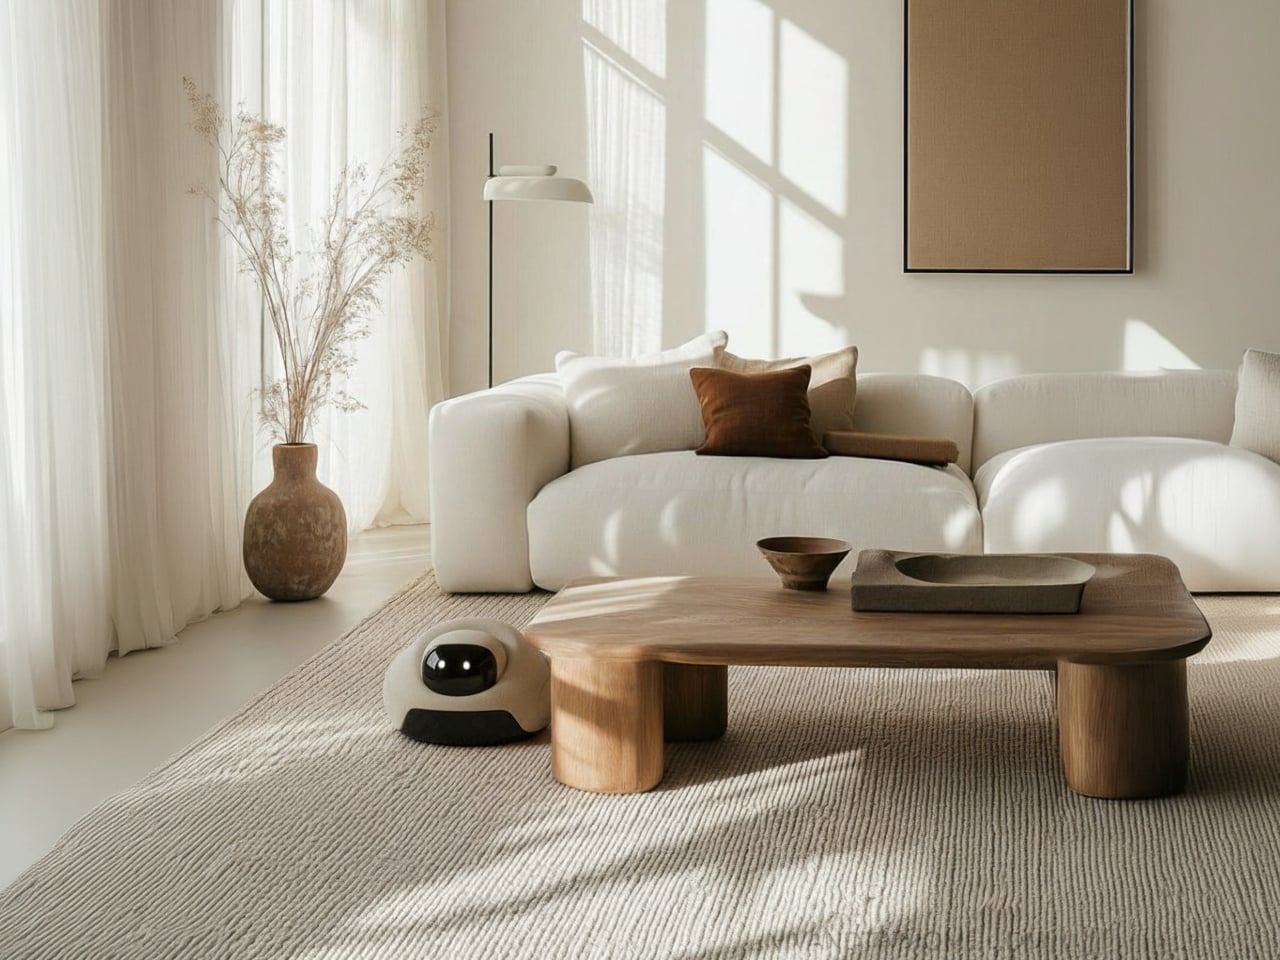
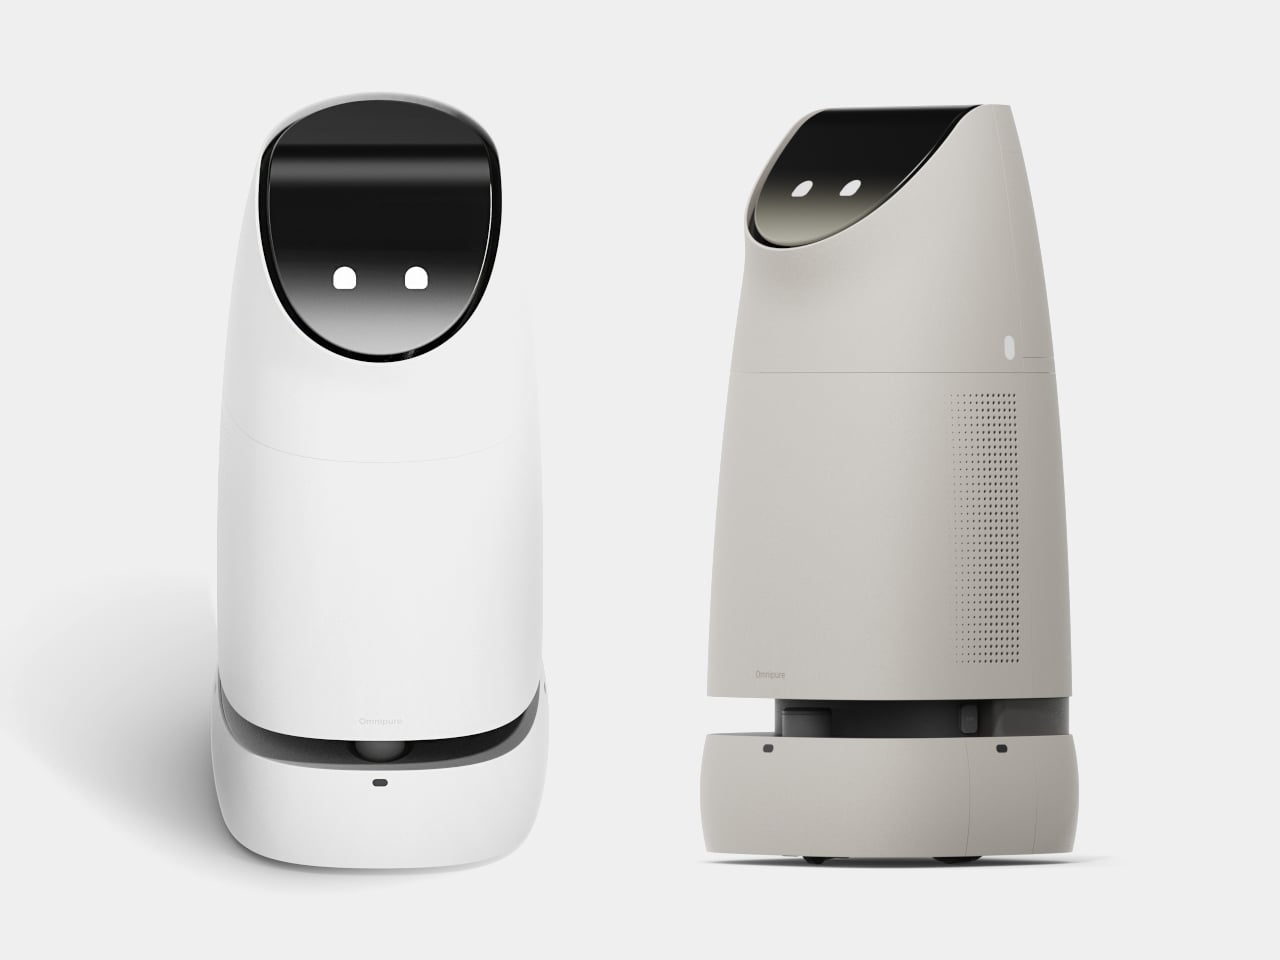
Omnipure reframes the whole premise. Rather than sitting in one corner hoping the air comes to it, this autonomous robot concept maps the home, learns the occupant’s routines, and moves toward pollution before it has a chance to disperse. Catching cooking smoke at the stove rather than after it fills the room is the kind of meaningful difference that makes a purifier genuinely useful rather than marginally helpful.

Designer: Kyuhong Kim
The behavior is where the design makes its most interesting decisions. When someone walks through the front door, Omnipure rolls to the entryway and greets them while clearing entryway dust at the same time. Framing that as a welcome rather than a clinical alert is a deliberate choice. A robot charging toward you the moment you arrive home communicates something quite different from one that simply seems glad you’re back.
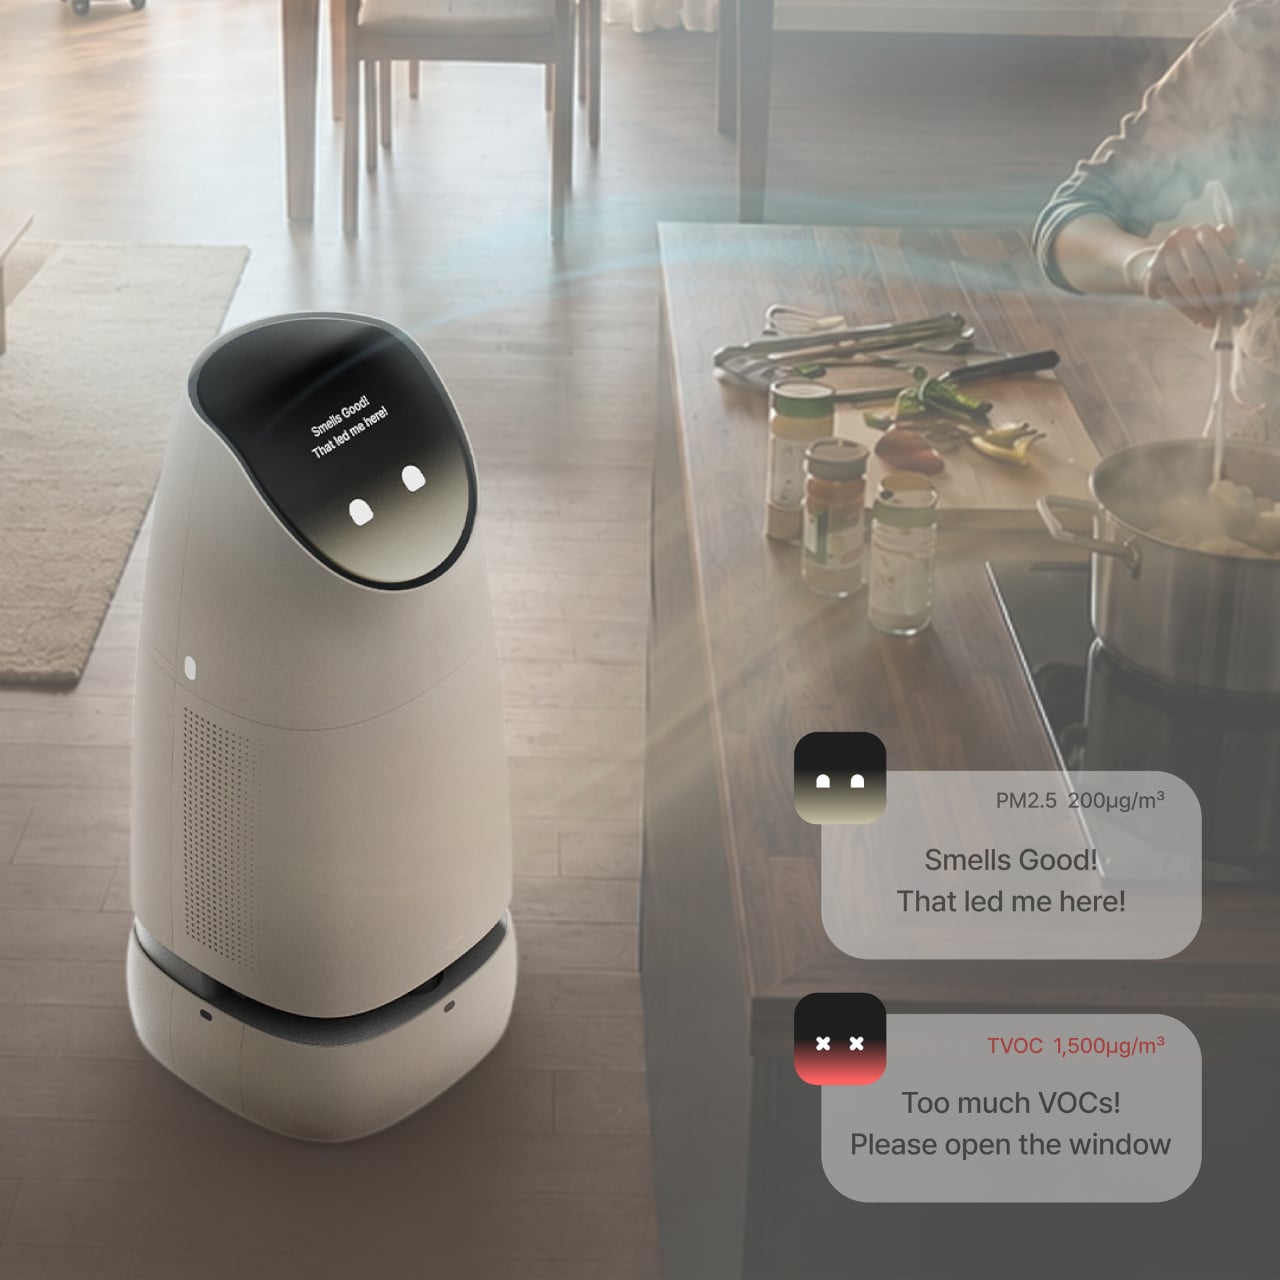
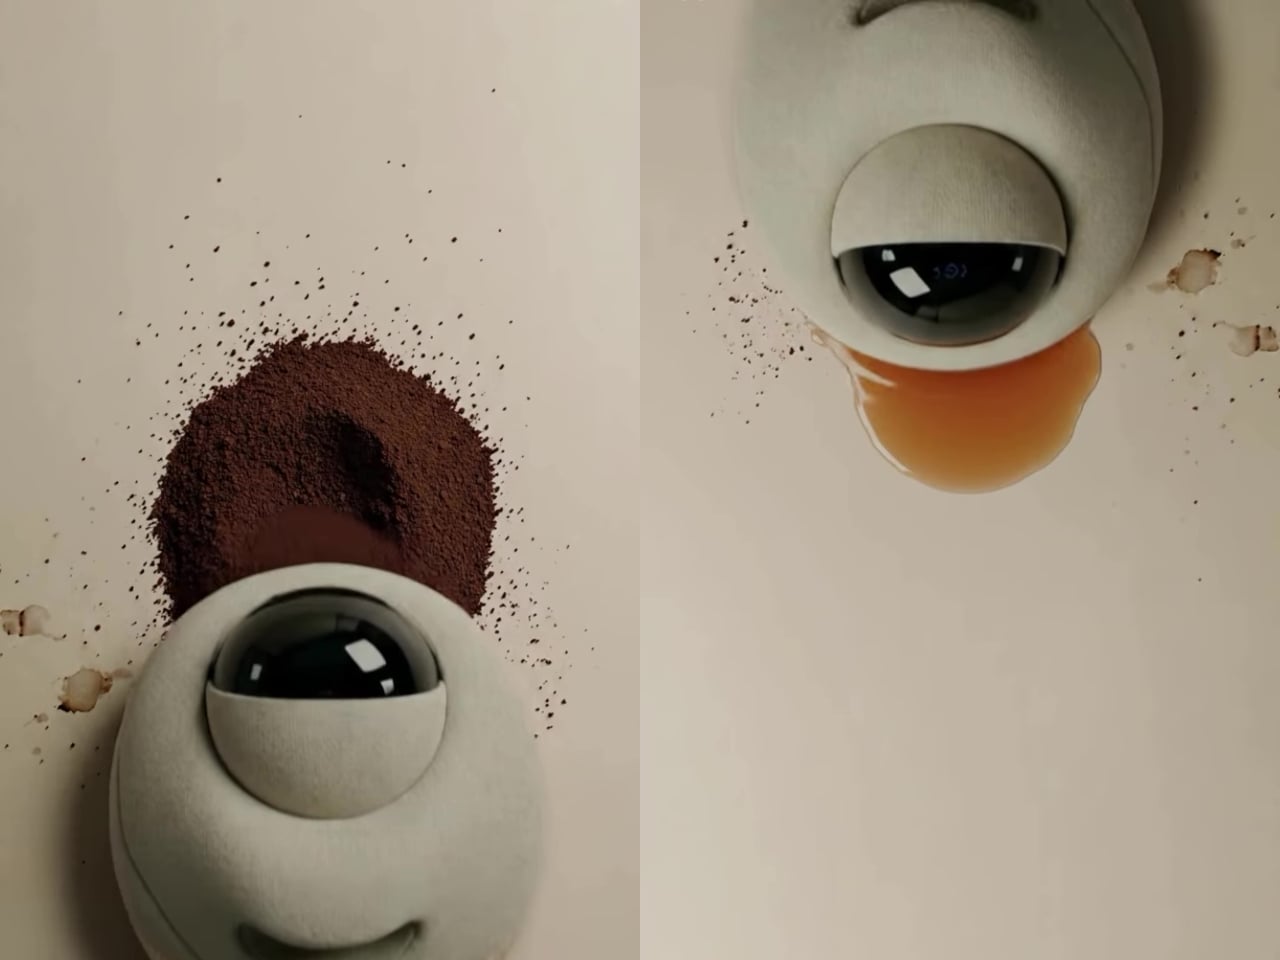
The kitchen scenario captures the same thinking. When cooking raises PM2.5 levels or volatile organic compounds spike from a hot pan, Omnipure navigates toward the source and announces its arrival with “Smells Good!” rather than an alarm. If TVOC levels climb too high, it suggests opening a window rather than filtering at maximum capacity, because the better response to a ventilation problem isn’t a better filter.
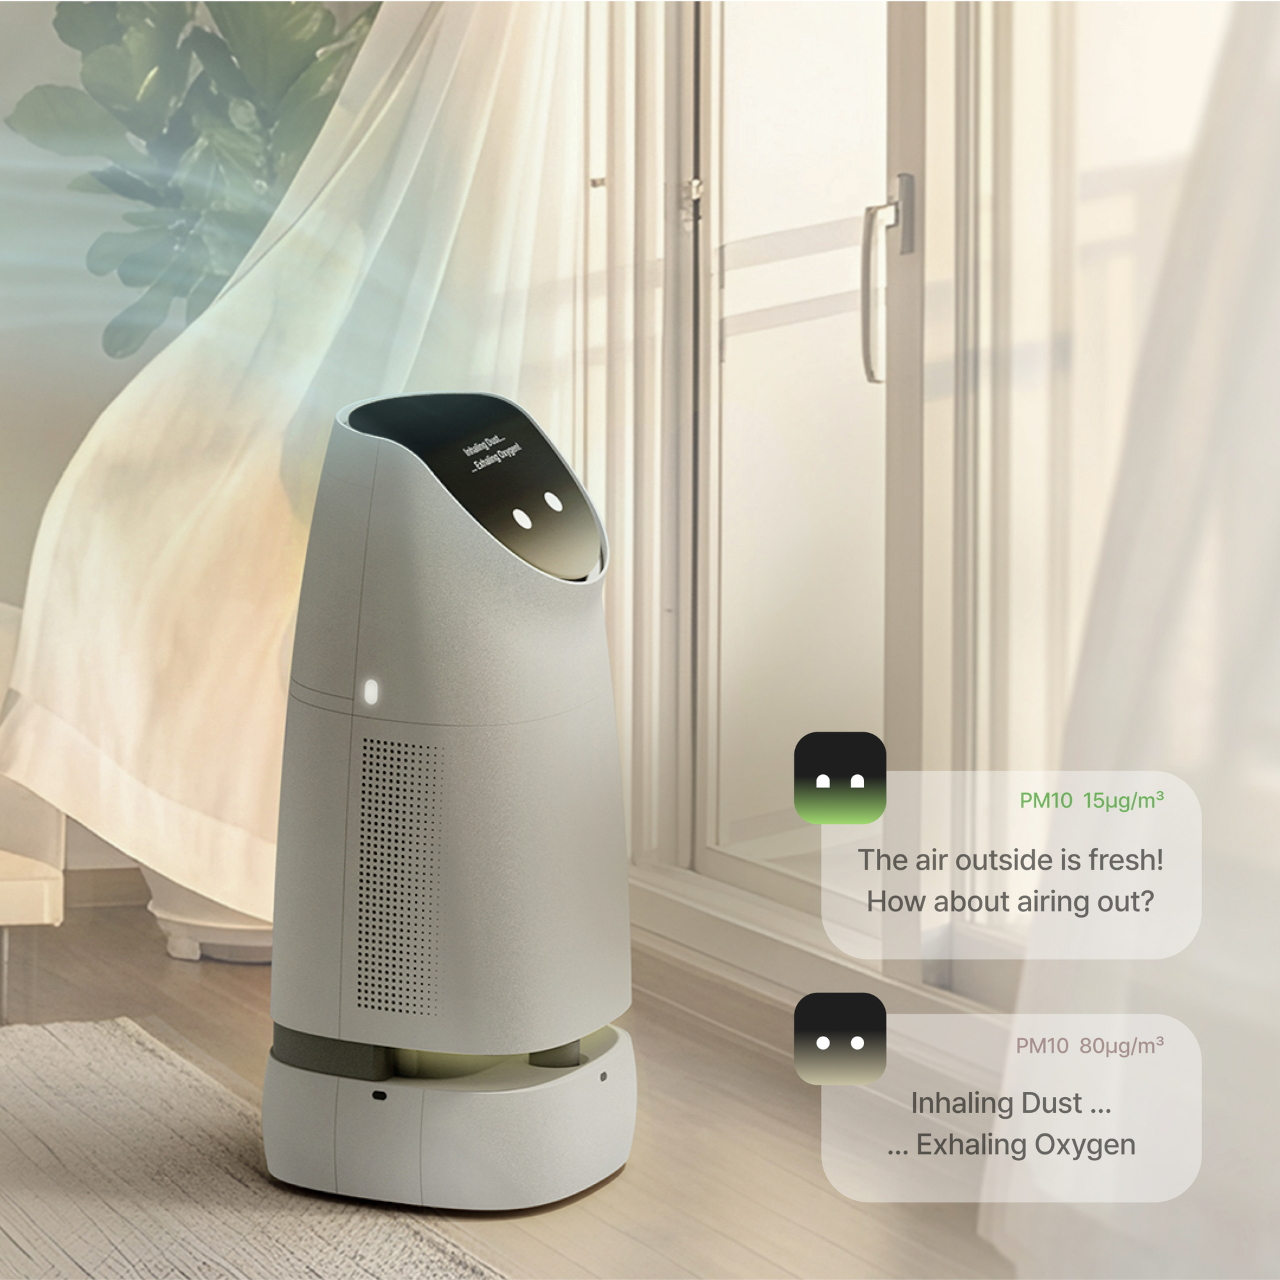
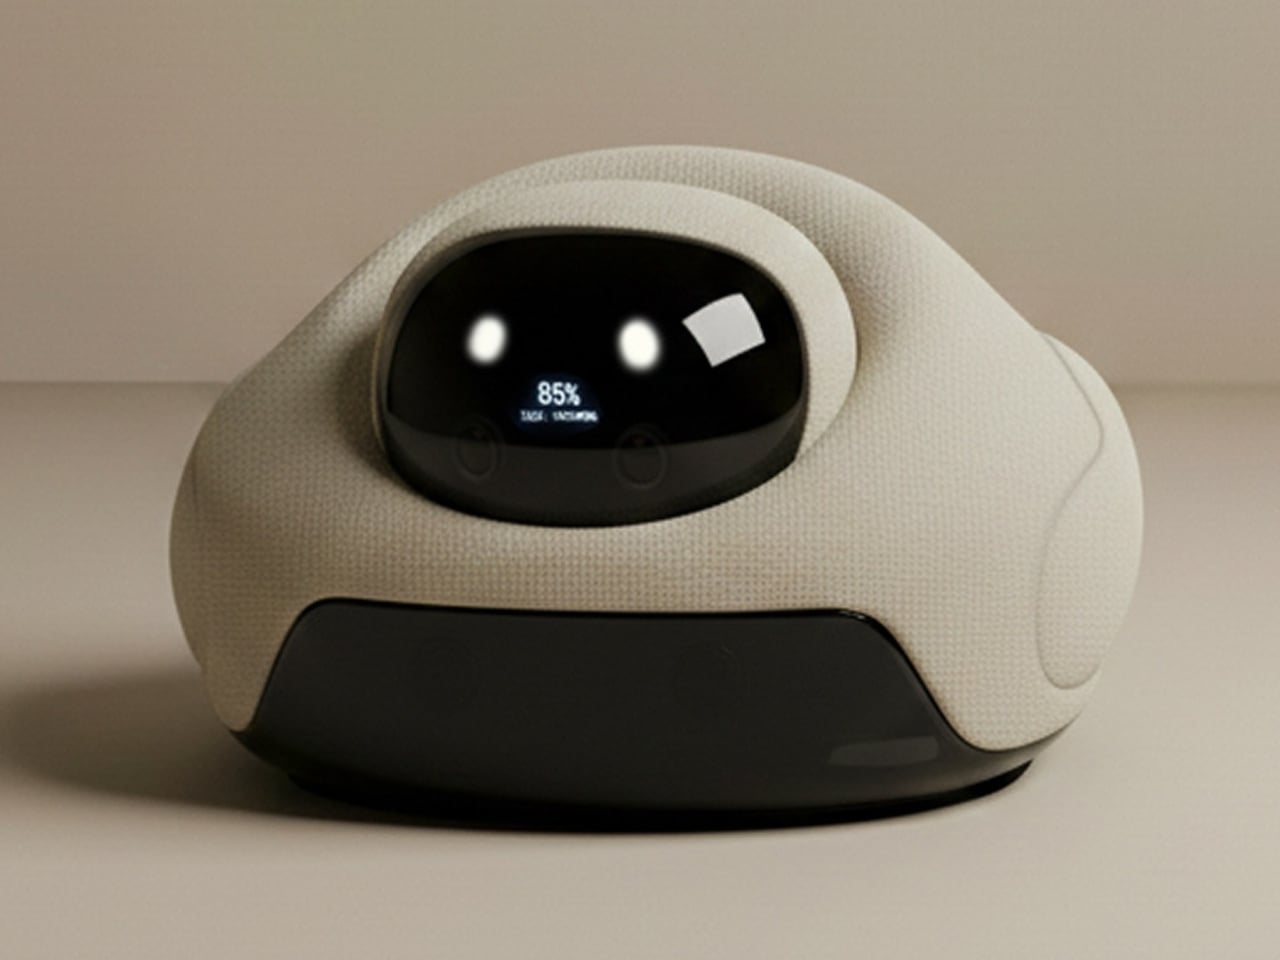
The ventilation behavior adds another dimension. Rather than treating indoor air as automatically preferable to outdoor air, Omnipure monitors both and suggests airing out when outdoor conditions are favorable. When a window is opened, it positions itself in the airflow to filter incoming air before it circulates. The messages it displays at these moments frame its function as a conversation rather than a status readout.
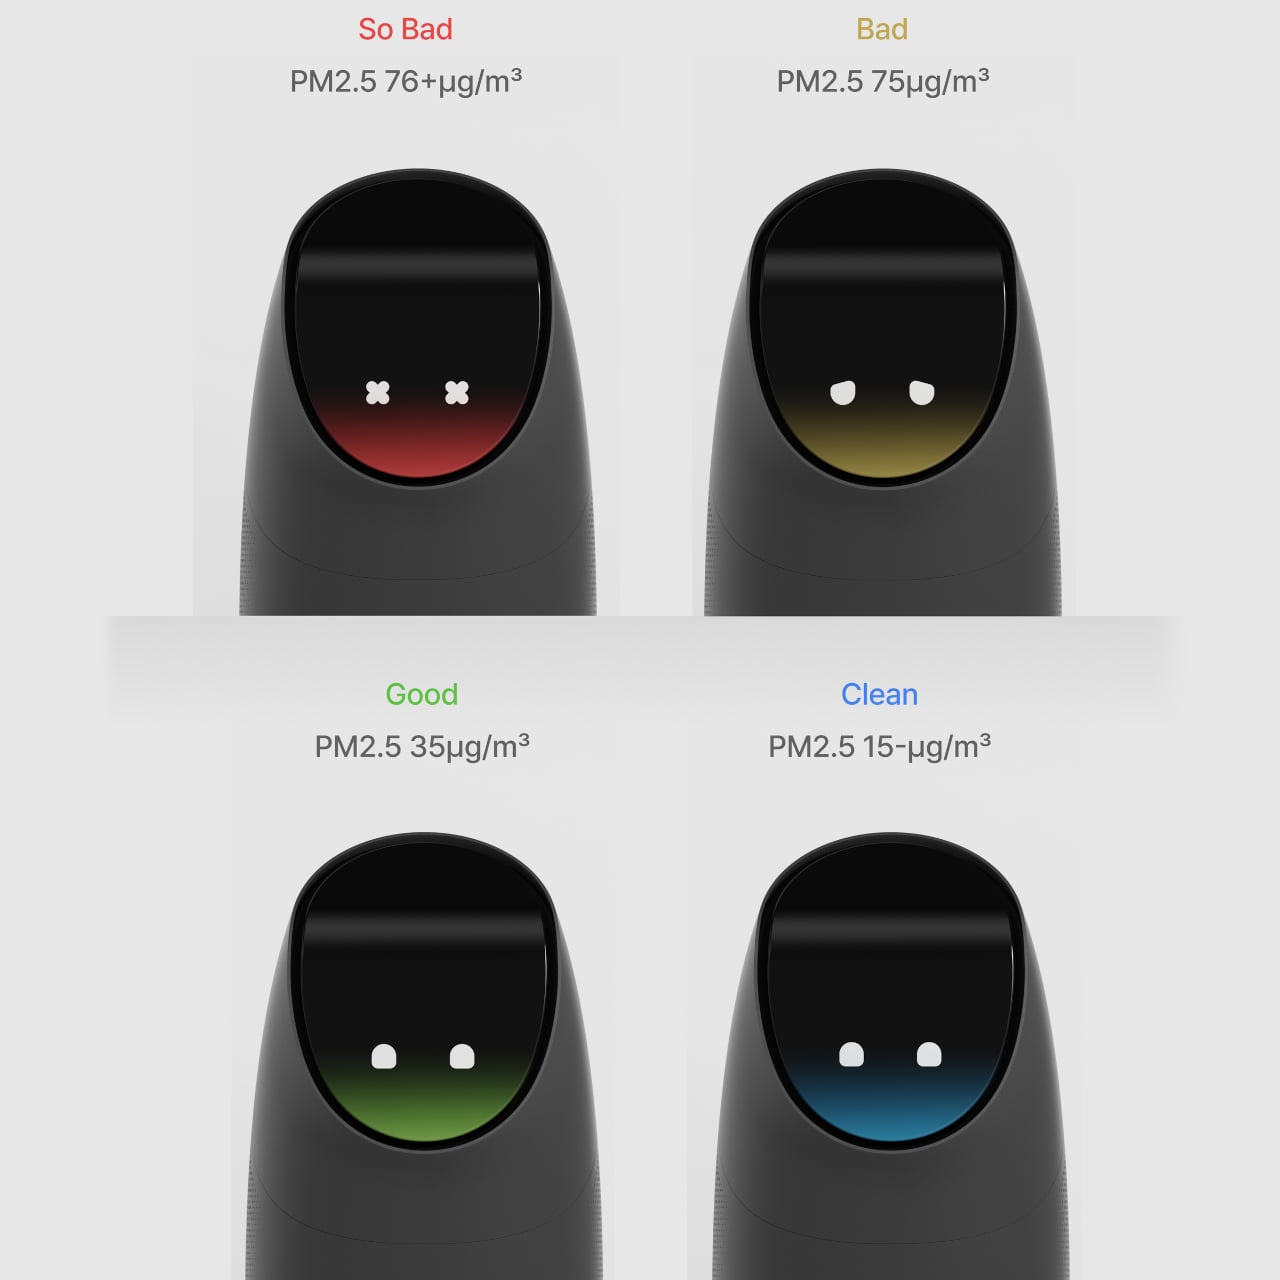
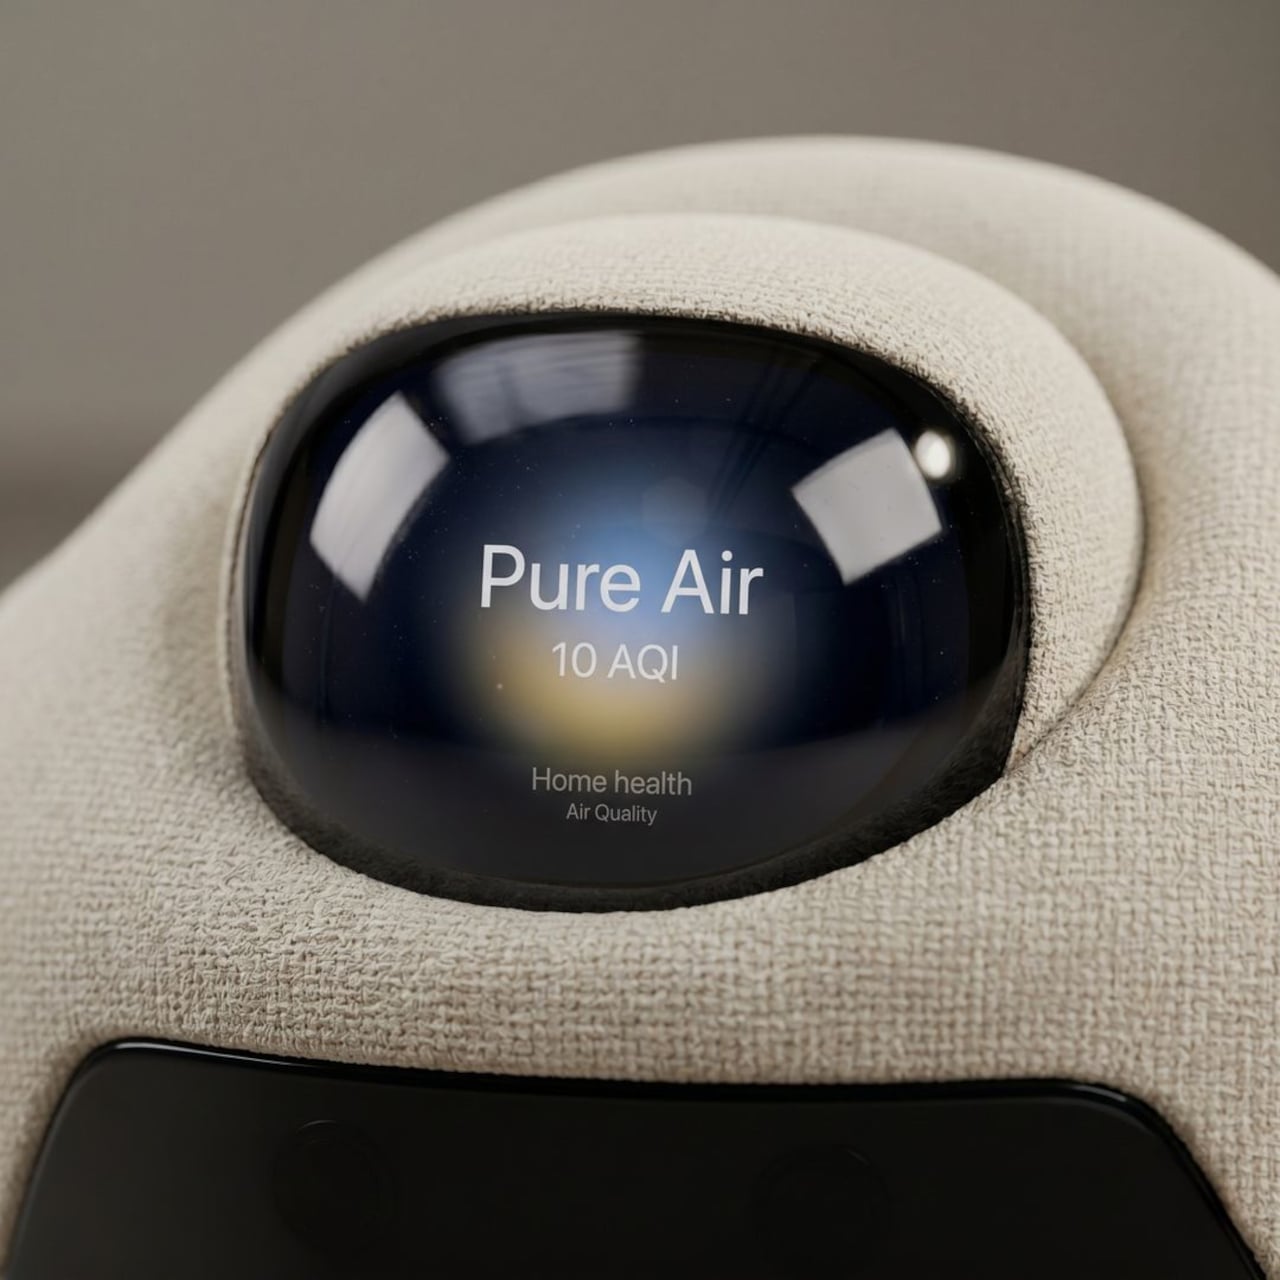
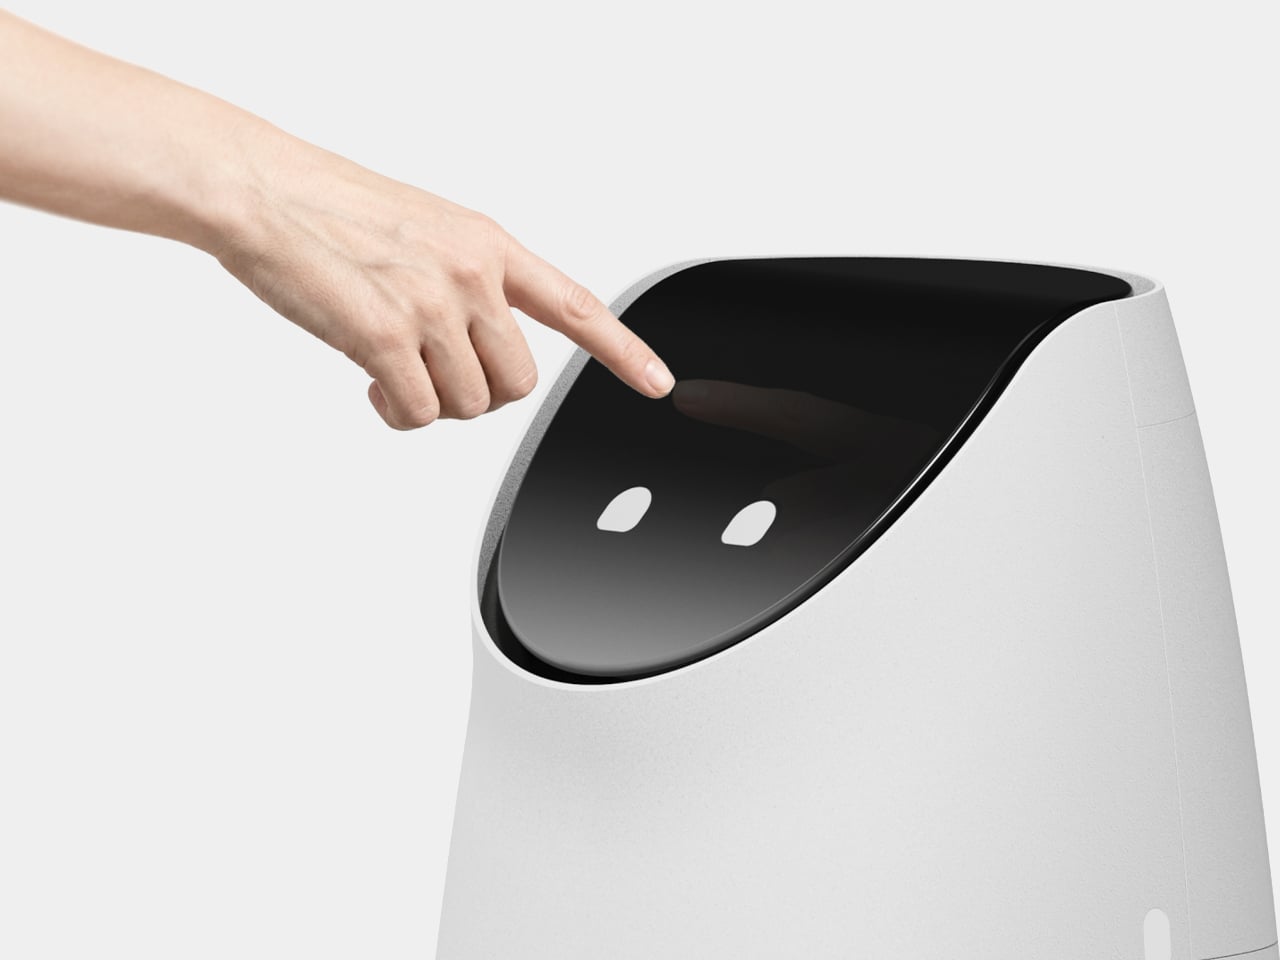
The face display communicates air quality through four states tied to PM2.5 levels. Clean air below 15 μg/m³ reads as a blue glow with relaxed eyes, acceptable conditions around 35 μg/m³ show green, poor air at 75 μg/m³ appears amber, and hazardous readings above 76 μg/m³ trigger a red glow with X-shaped eyes. A glance across the room is enough to know what you’re breathing without unlocking a phone.
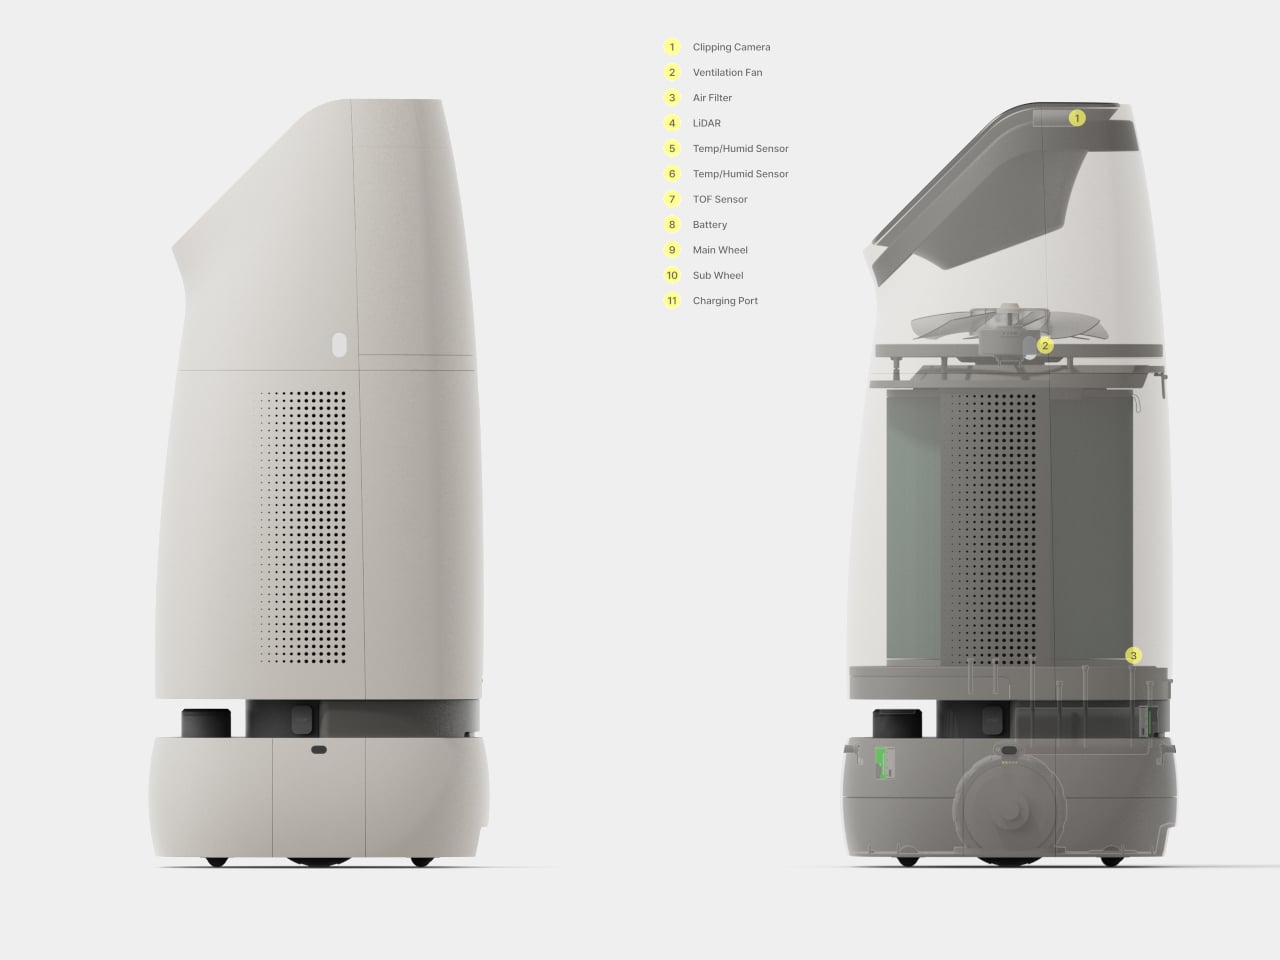
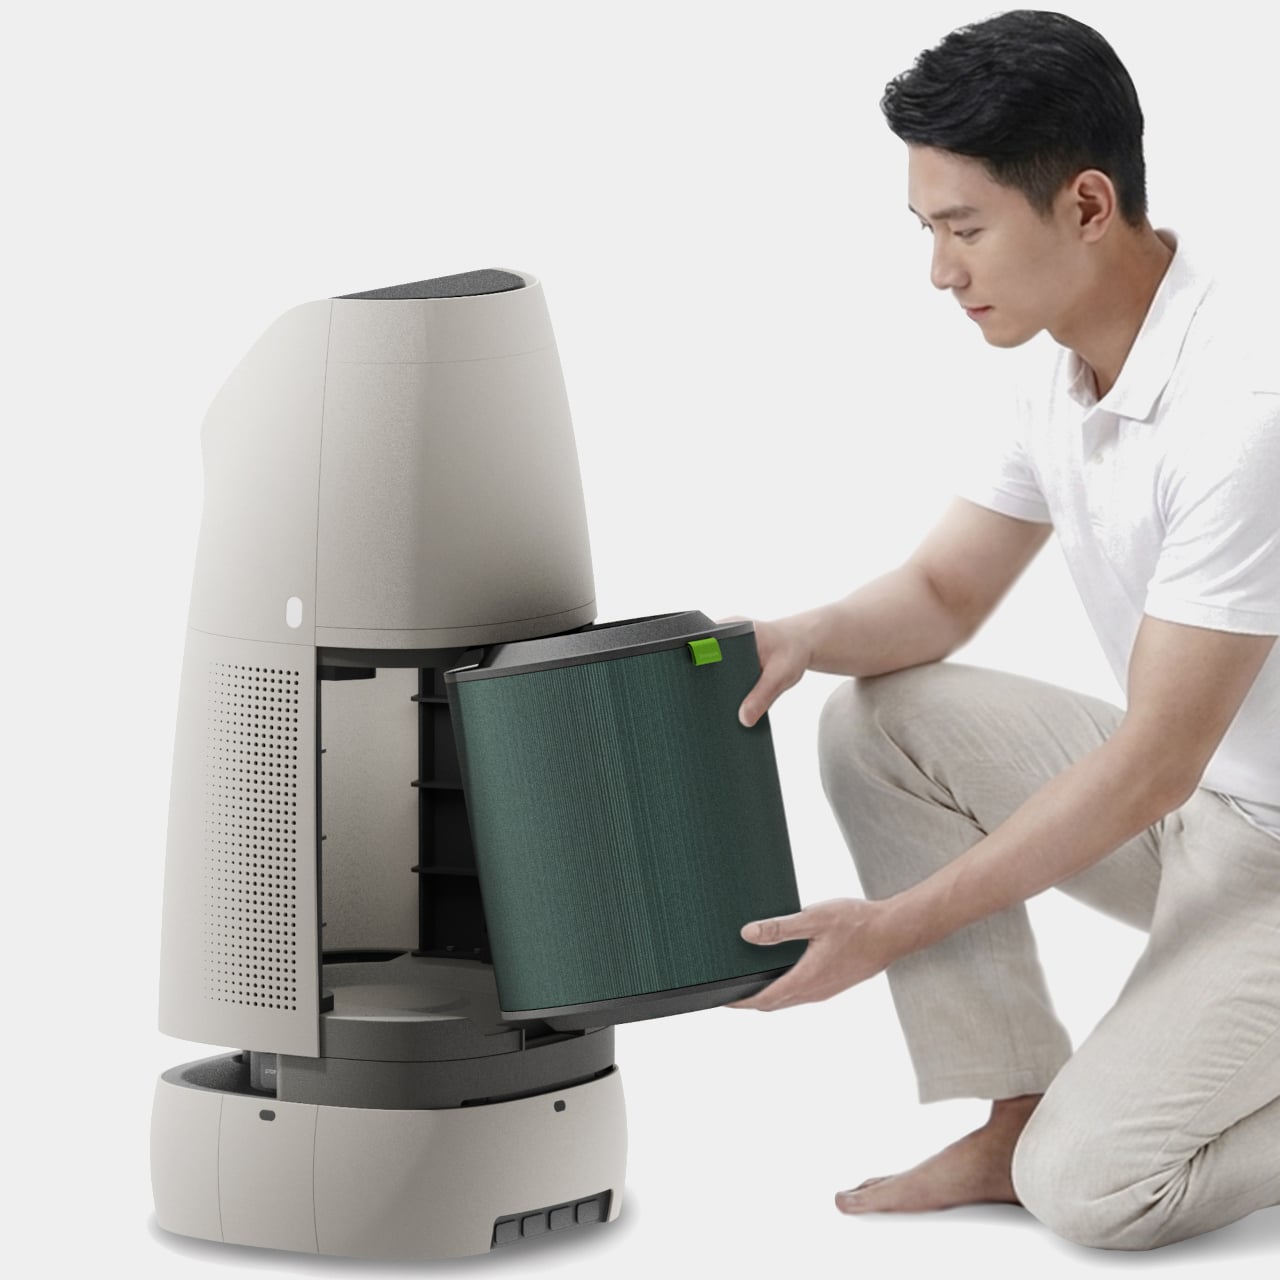
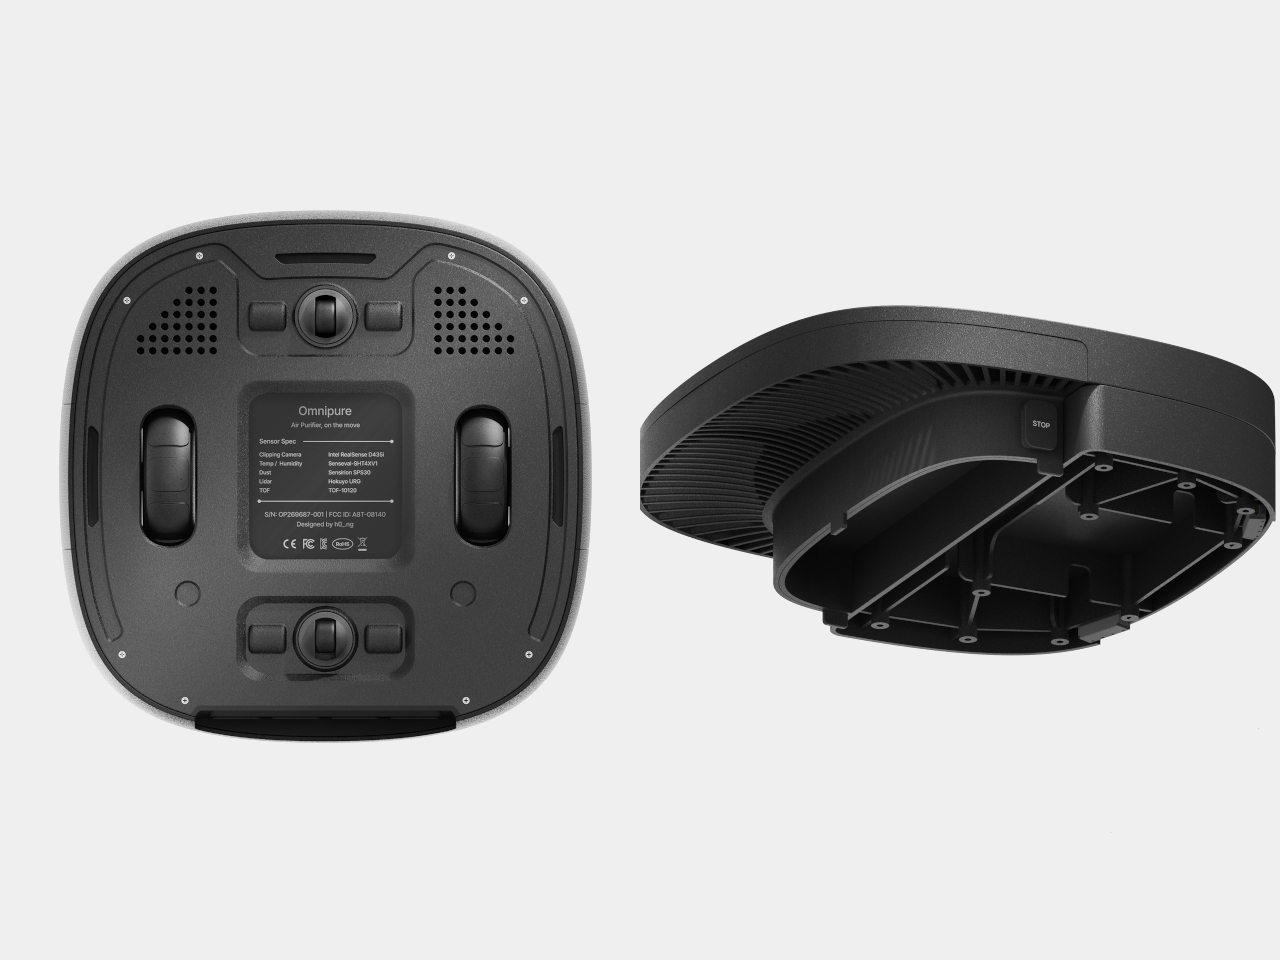
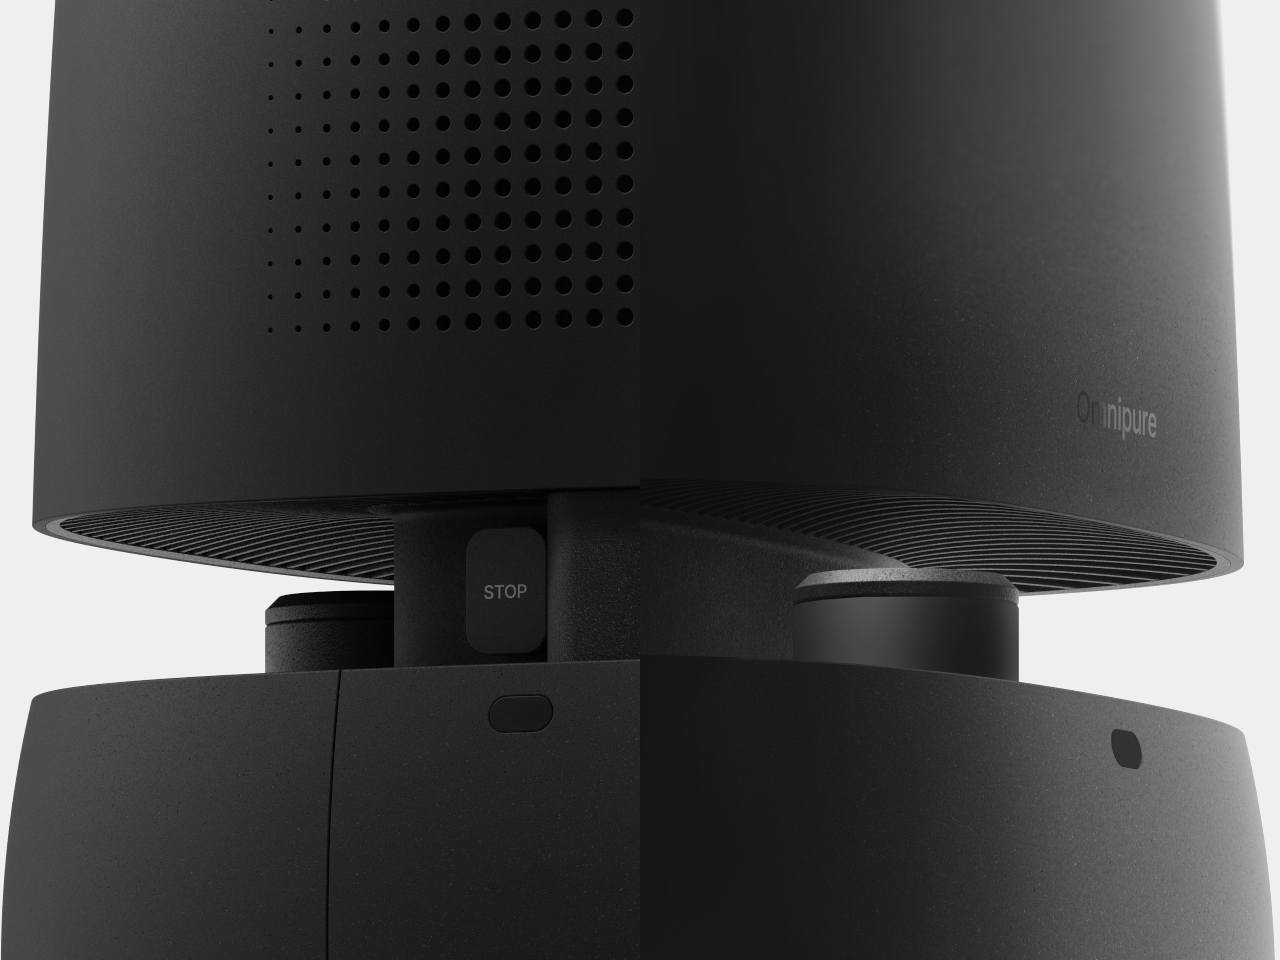
Internally, Omnipure runs on LiDAR and time-of-flight sensors for navigation, a clipping camera, dual temperature and humidity sensors, and a centrifugal ventilation fan drawing air through a large replaceable filter housed in the lower body. The filter slides out from the side for maintenance, which turns what’s usually a buried, tool-required task into something that takes about as long as changing an ink cartridge.
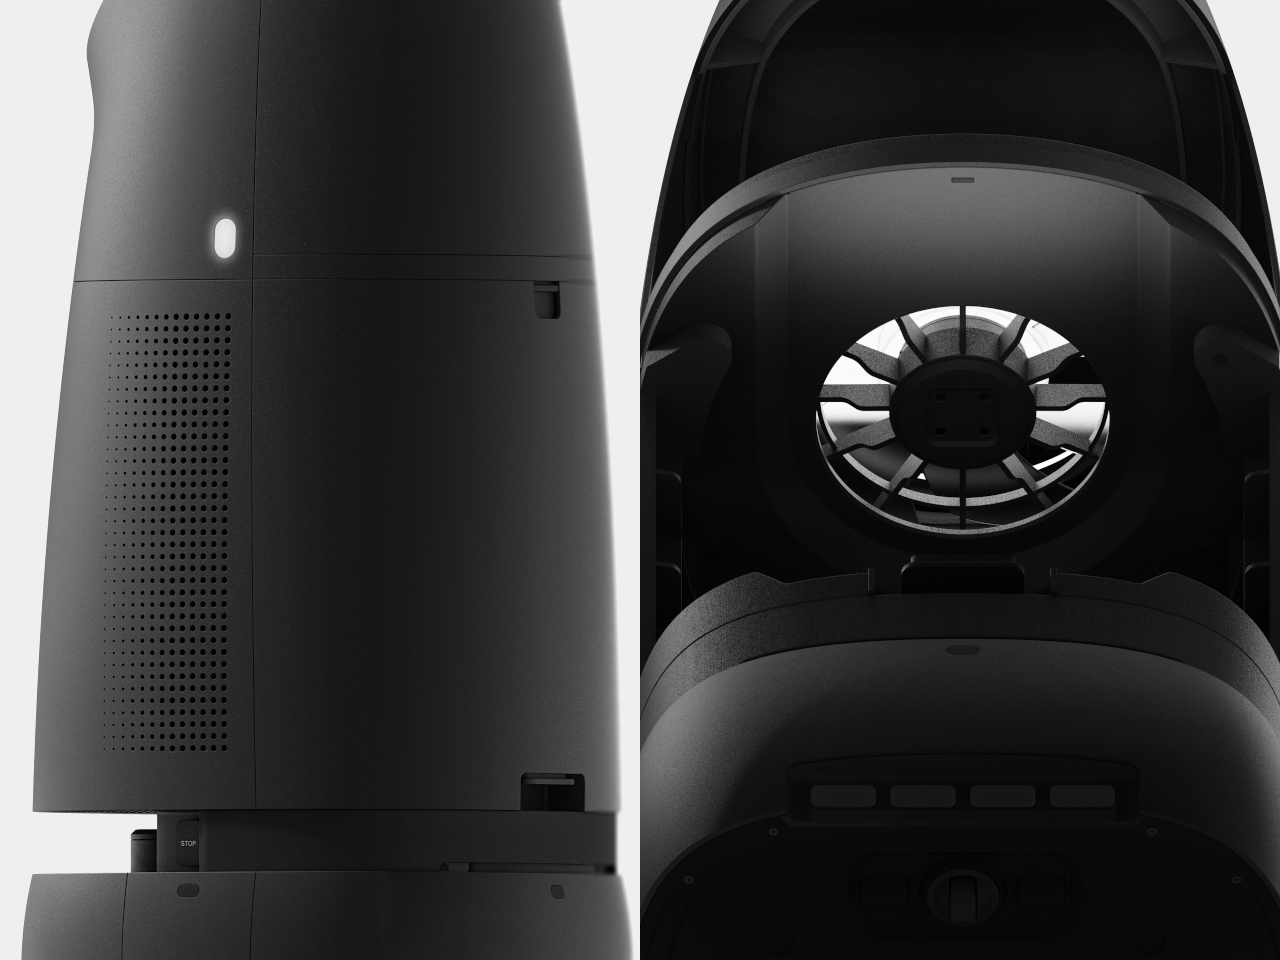
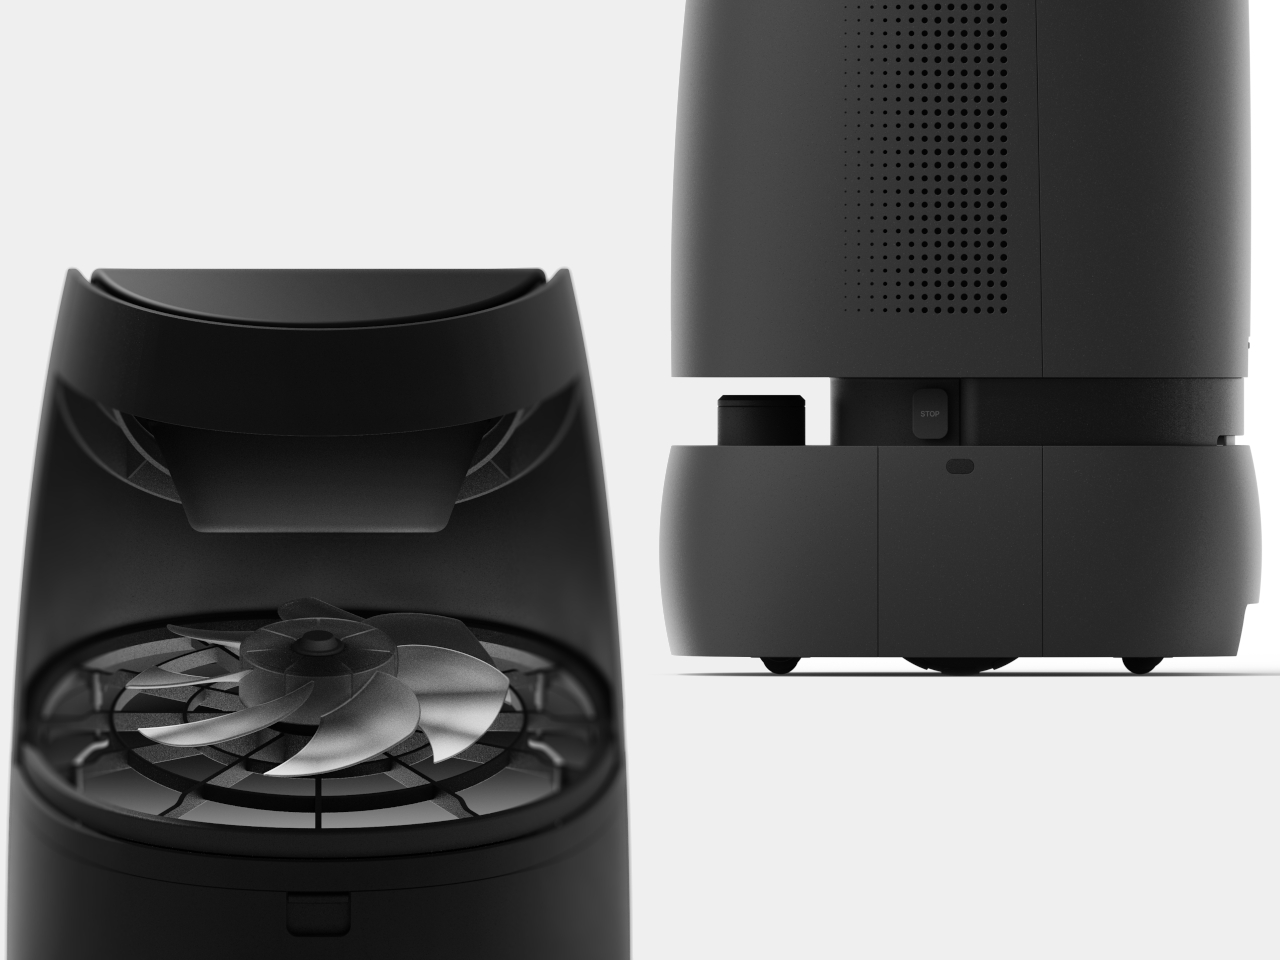
Omnipure is a concept rather than a product on shelves. But the problem it identifies is real: stationary purifiers can only clean the air that eventually reaches them. A device that maps a home, learns activity patterns, and positions itself where pollution is forming solves a fundamentally different problem from one that simply runs on auto in a corner, hoping the air comes to it.
The post The Air Purifier That Rolls Toward Smoke Before It Fills the Room first appeared on Yanko Design.
Harvard Students Built a Lamp That Taught a Robot to Make Art

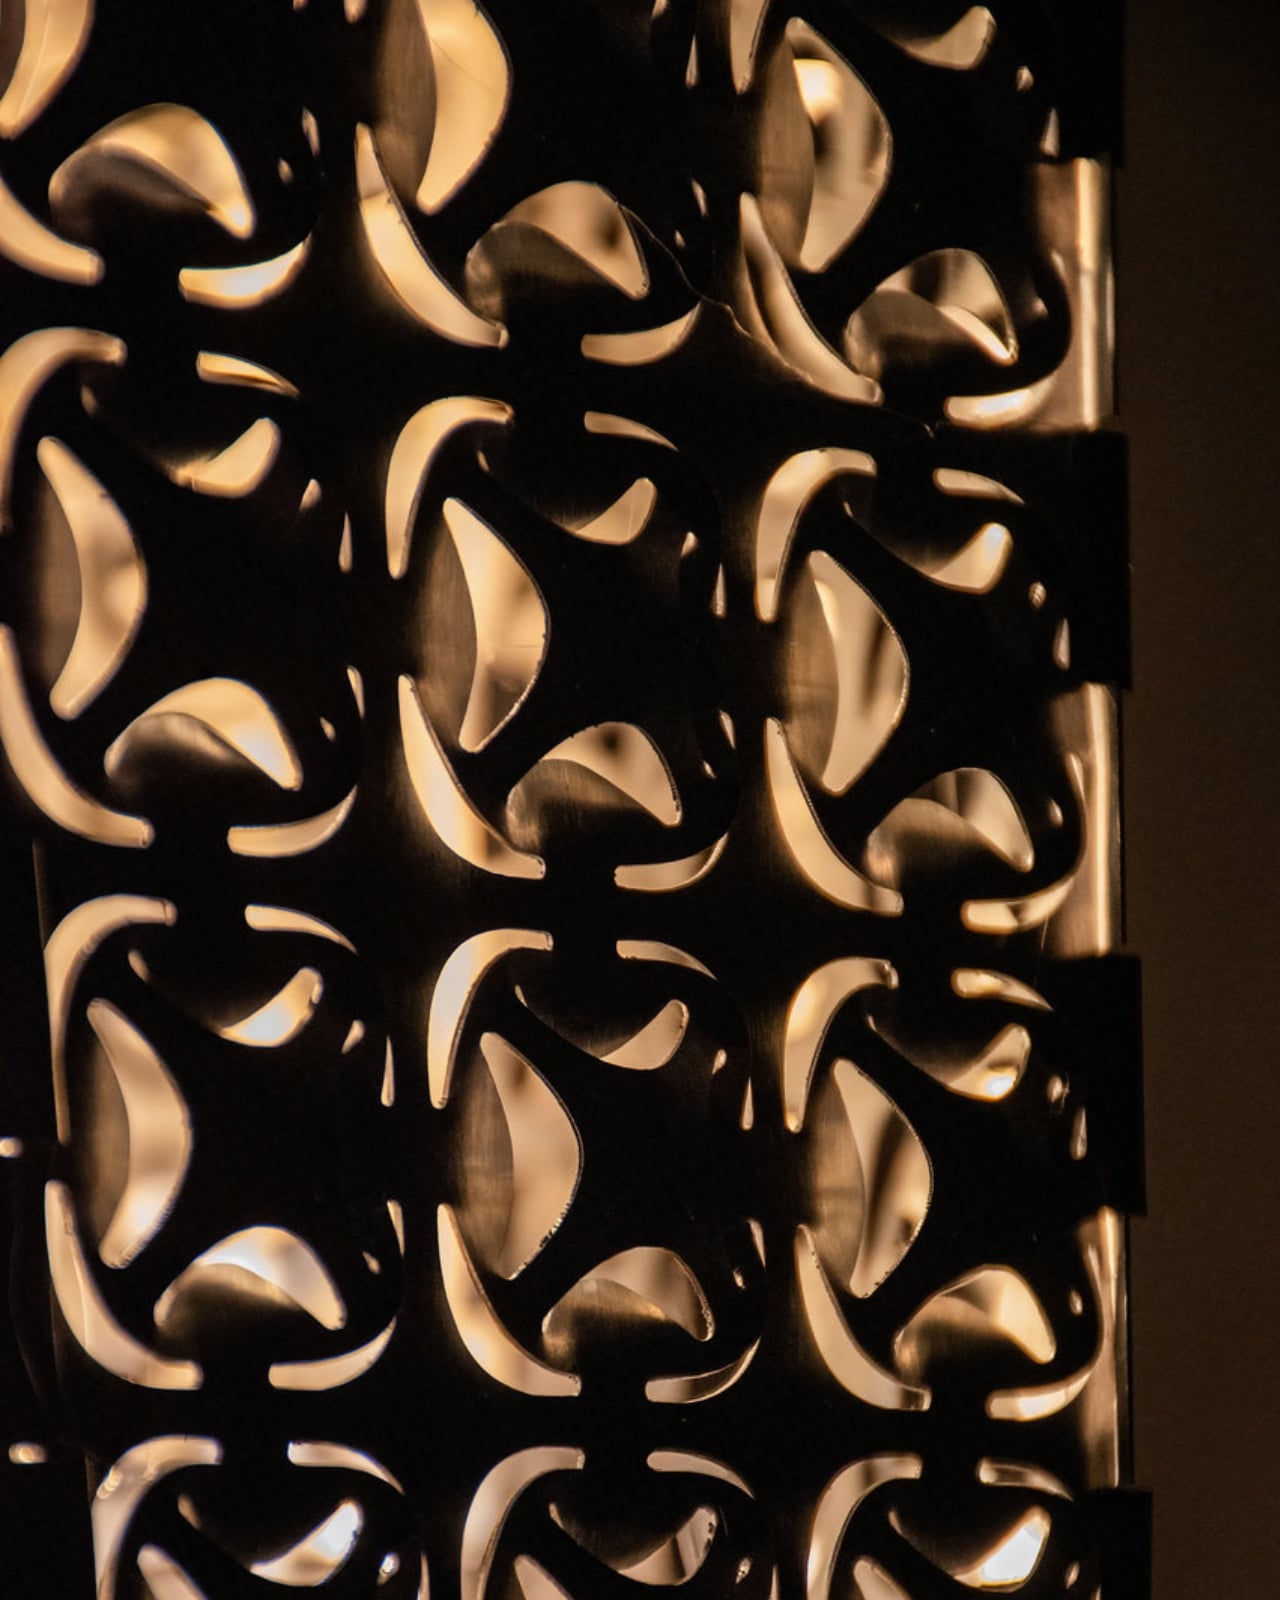
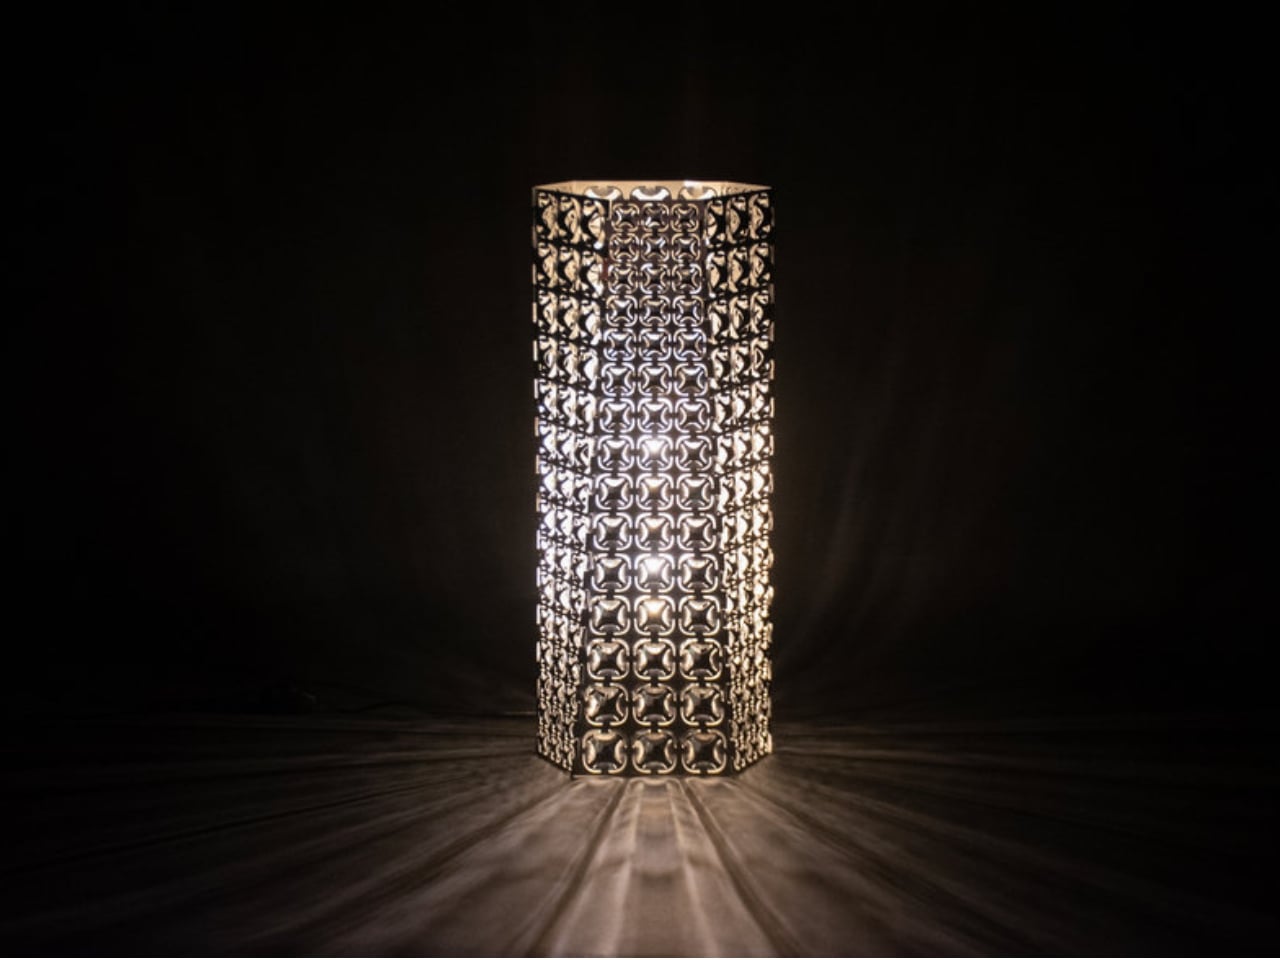
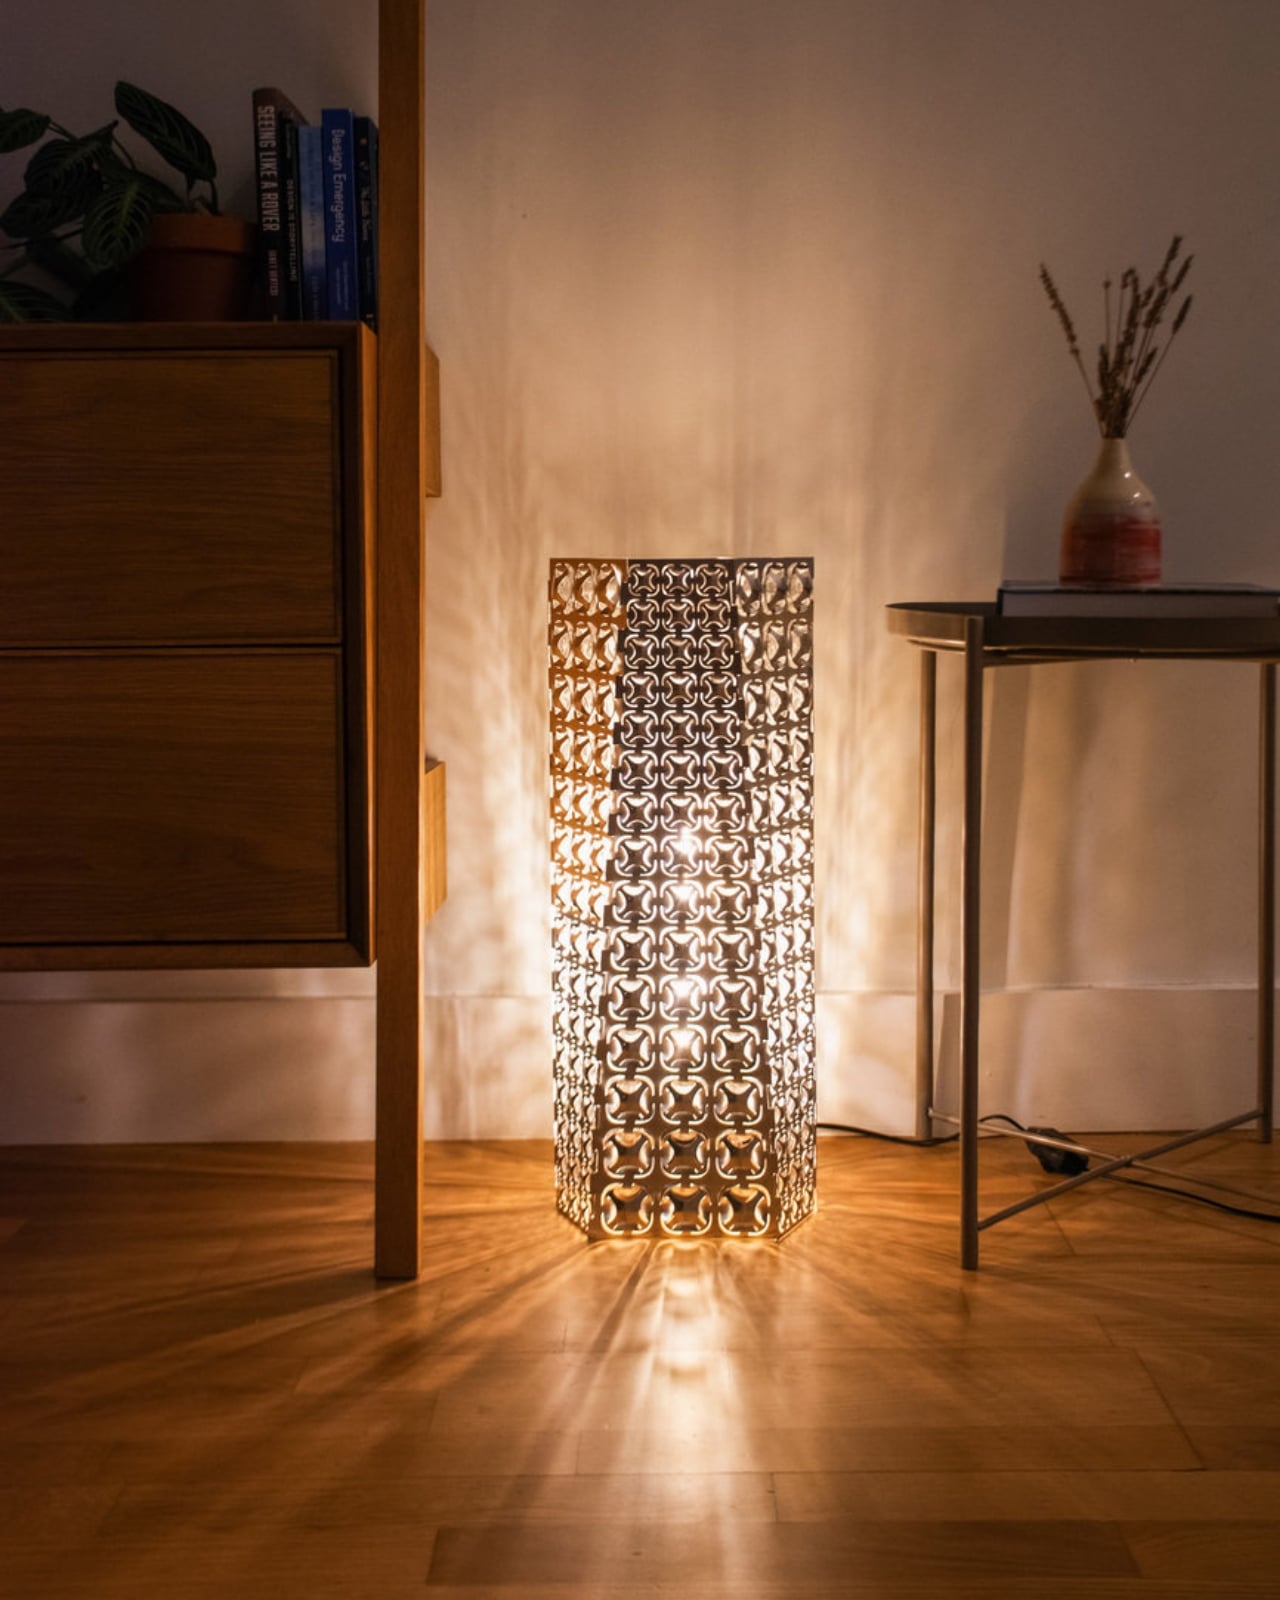
There are moments in design when your first thought isn’t “how does it work” but “how does it feel.” Hikarigami is one of those objects. Created by four Harvard Graduate School of Design students, Luke Fiorante, Joseph Fujinami, Annie Xing, and Chi Zhang, it’s a luminaire that looks, at first glance, like an intricate metal tower carved by a very patient and very precise hand. But the story behind it is far more interesting than the object alone, and the object itself is already extraordinary.

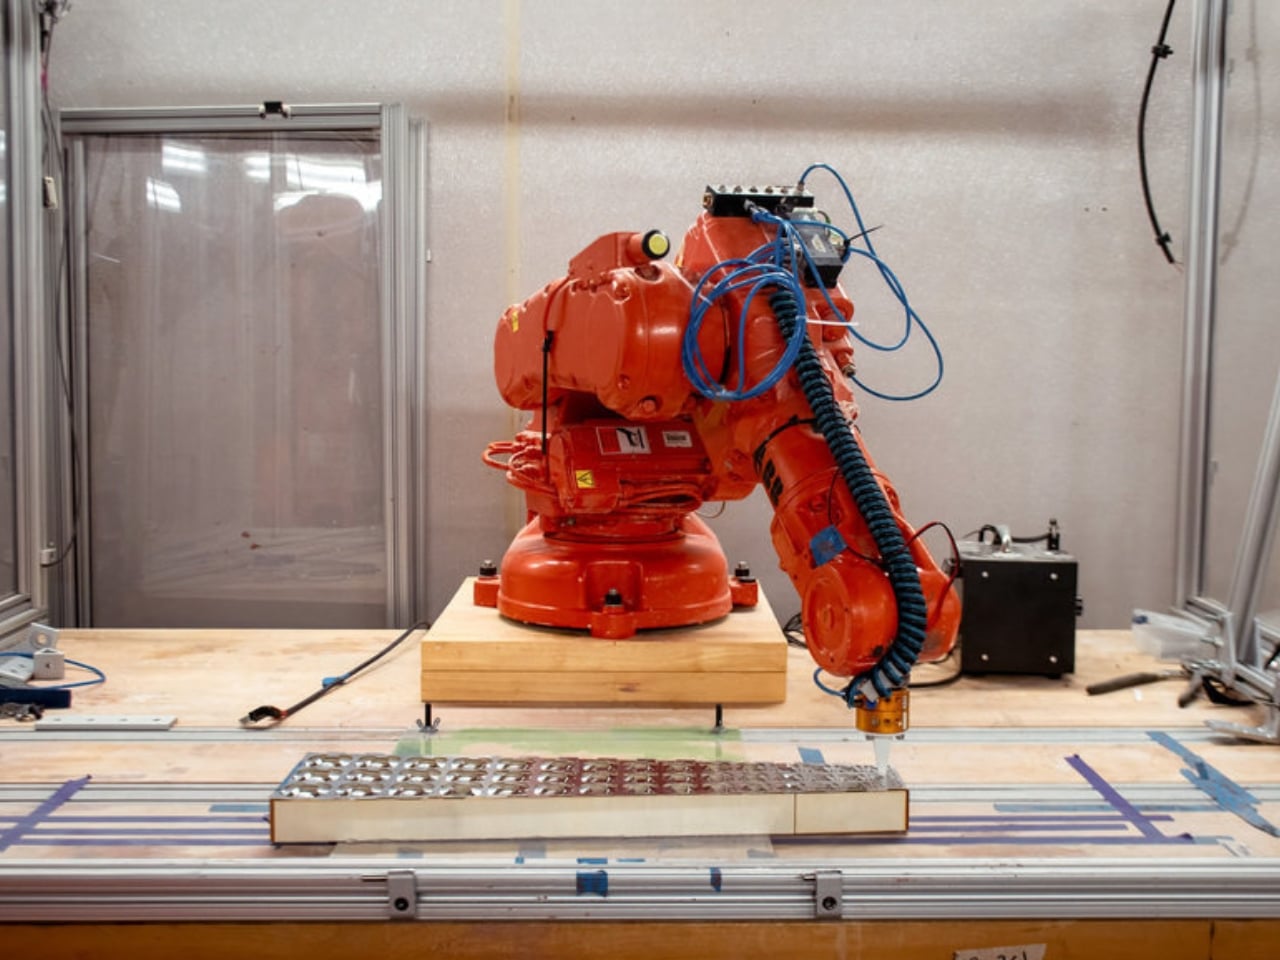
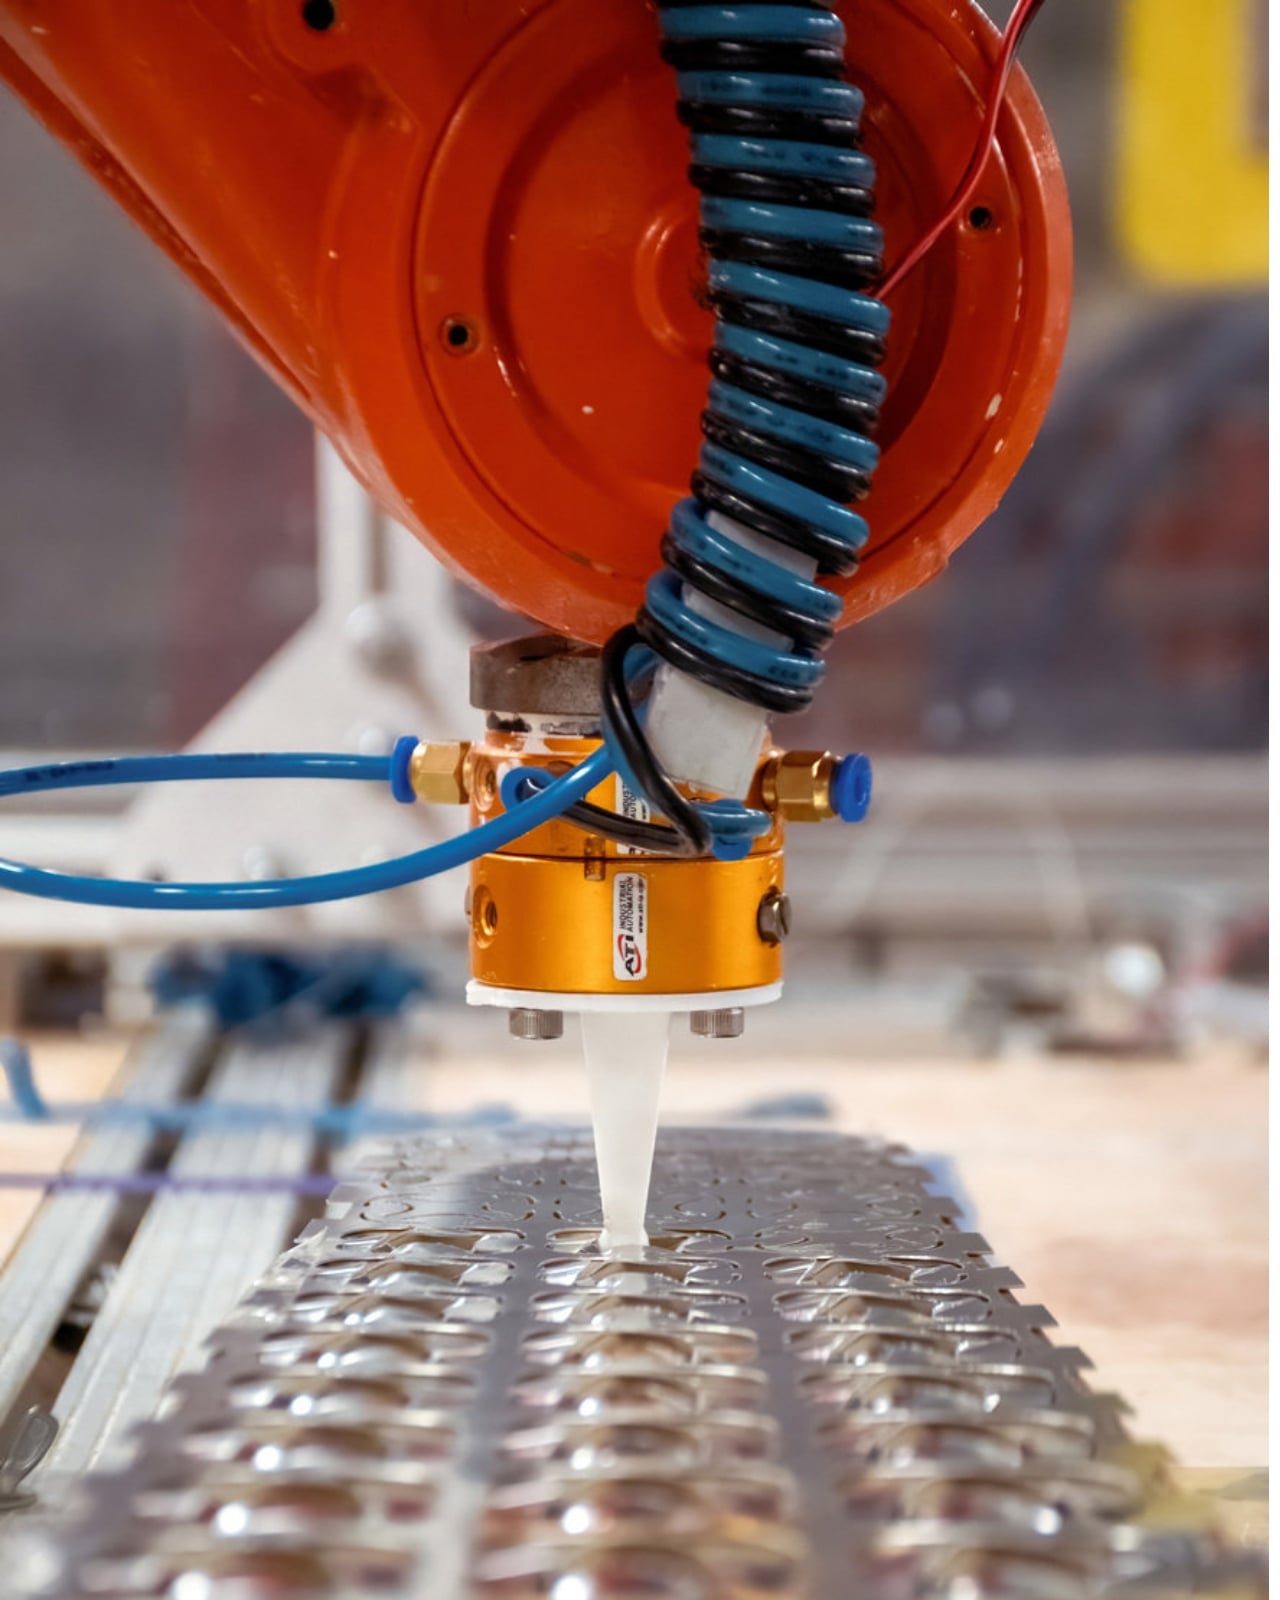
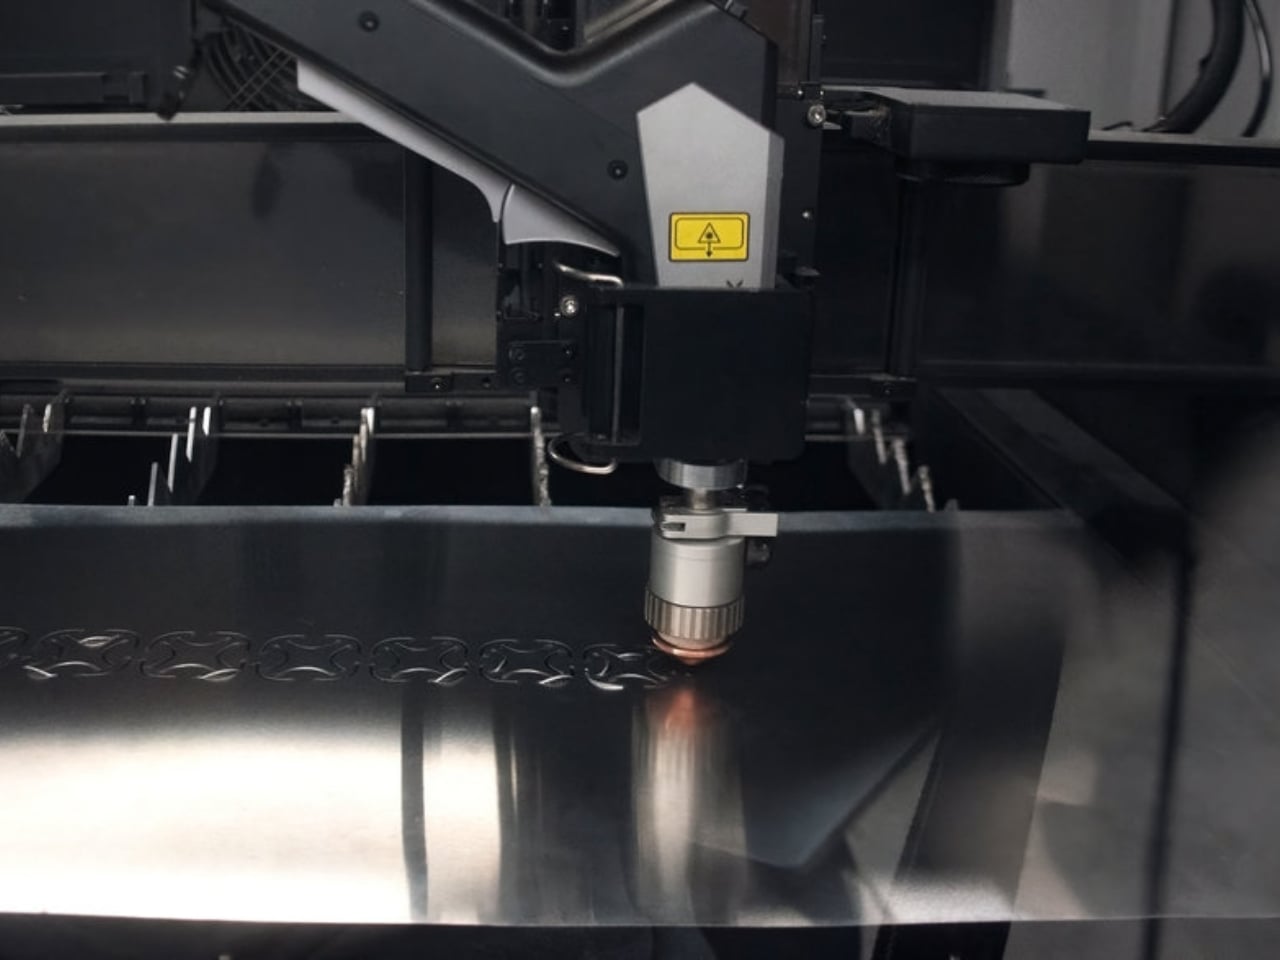
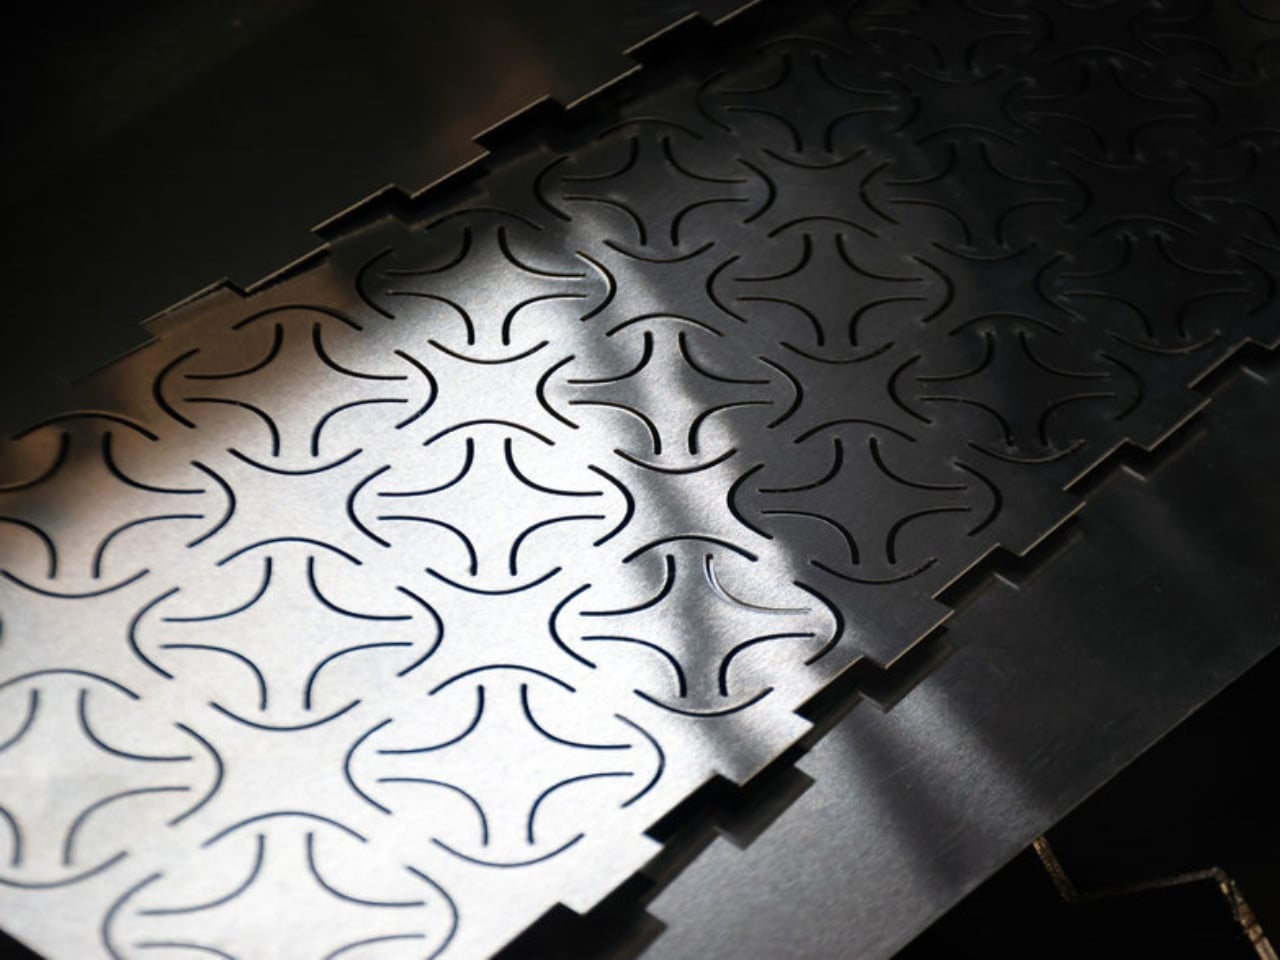
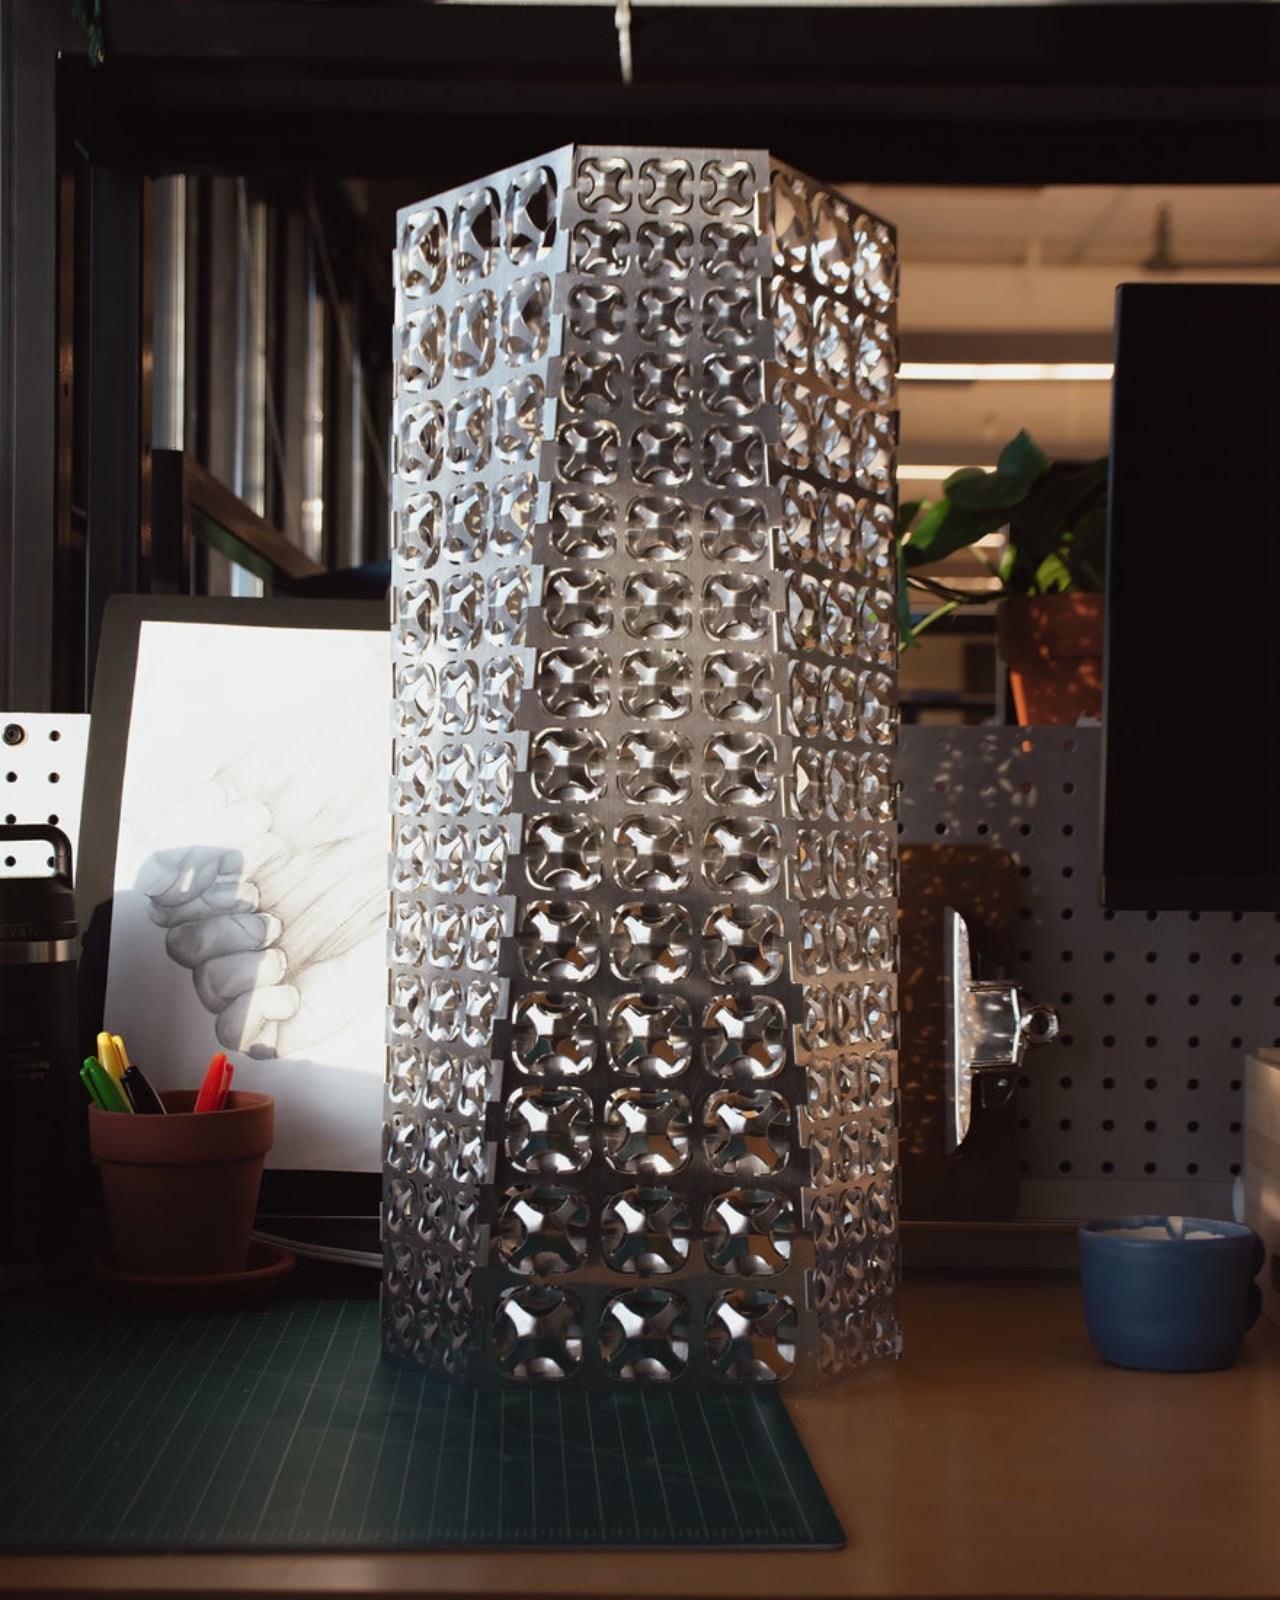
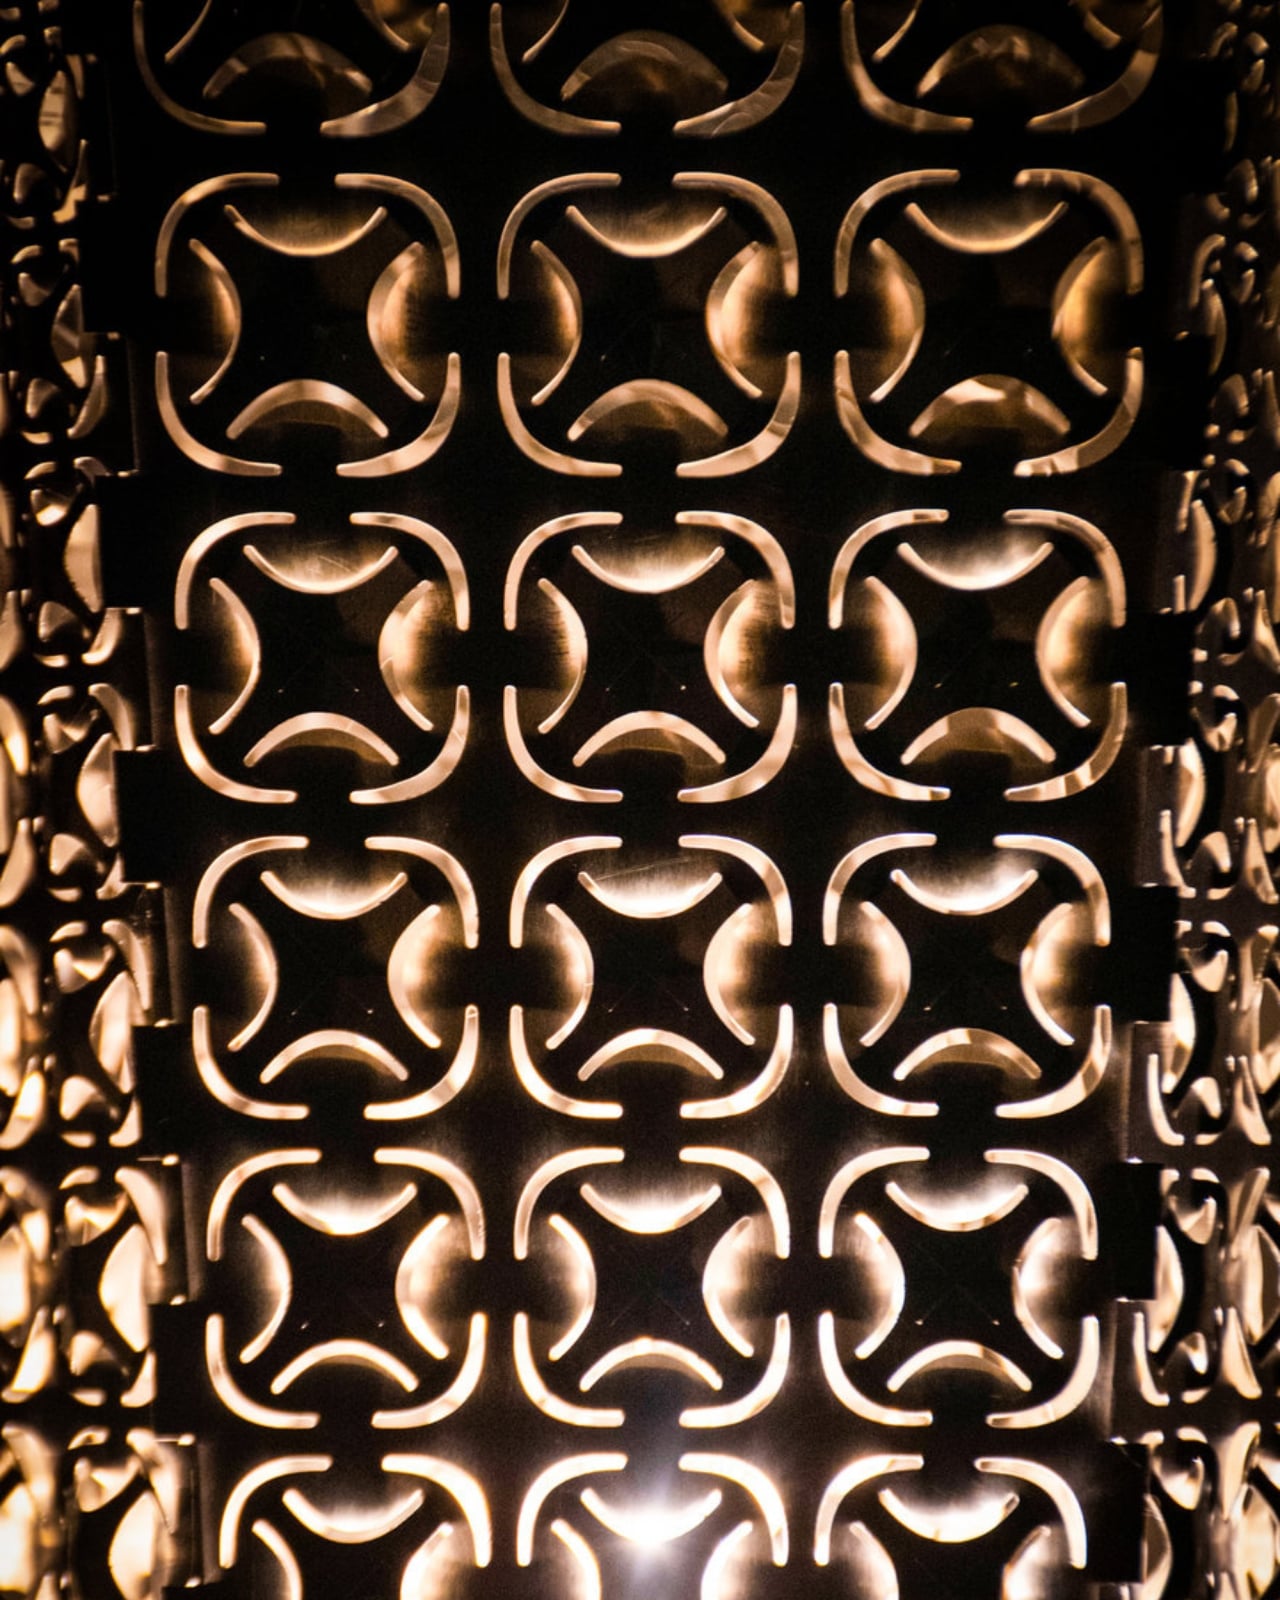
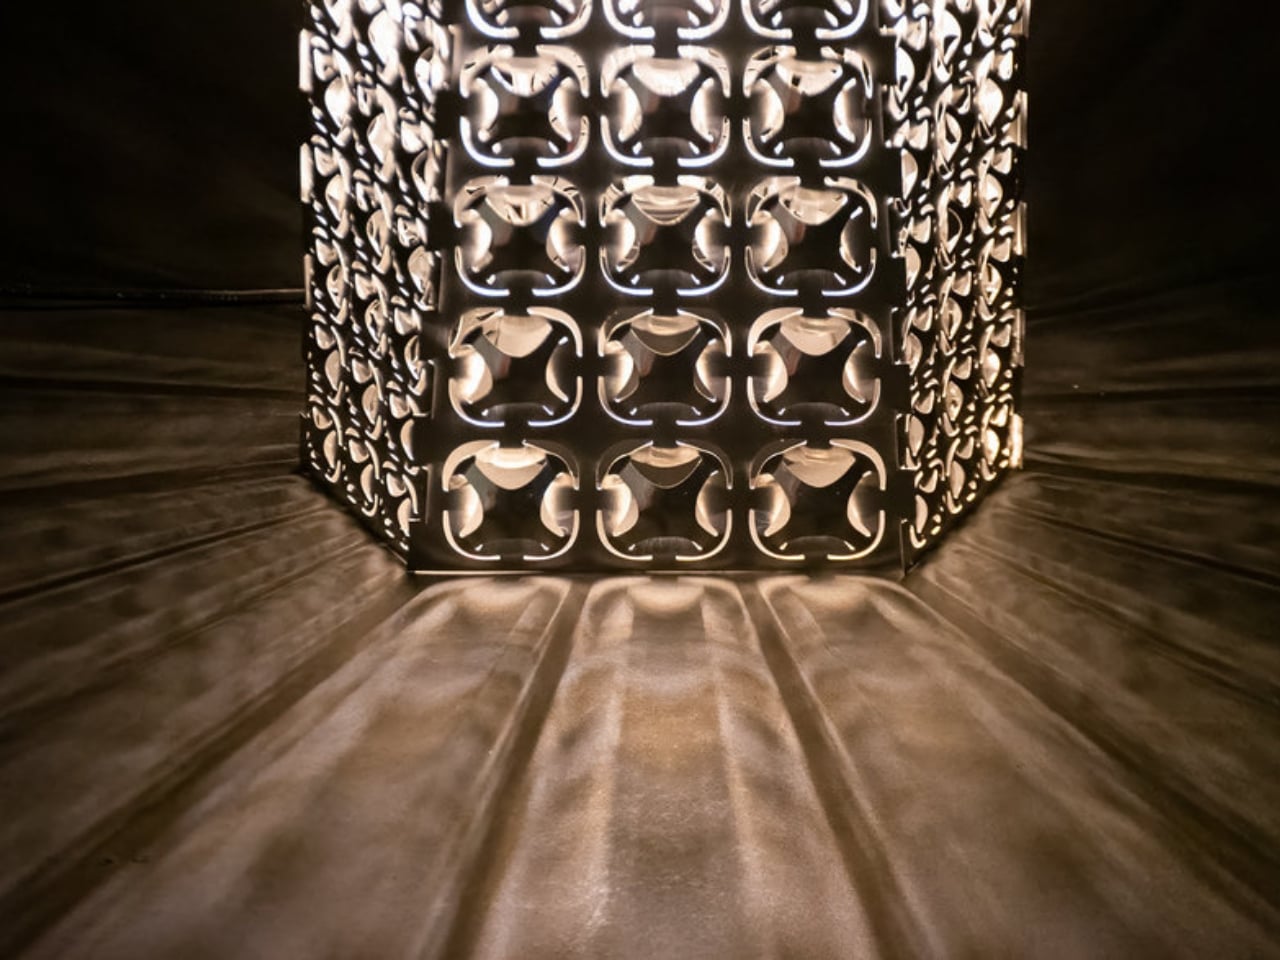
The name is a portmanteau of two Japanese words: hikari, meaning light, and kirigami, the traditional art of cutting and folding a single sheet of material into three-dimensional form. The fusion isn’t just poetic; it’s structural. The team took that ancient paper-craft logic and translated it into sheet aluminum, using an industrial robotic arm to press, deform, and expand the metal into a lattice of thousands of individual cells. Each cell is unique. Each one catches light differently. And every fold was made without a mold.

Designers: Luke Fiorante, Joseph Fujinami, Annie Xing, Chi Zhang

That last part is the quiet revolution tucked inside this project. Traditional metal forming depends on expensive, custom-made dies and molds, static tools that lock a design into one fixed shape and require significant capital before a single piece can be produced. Hikarigami throws that model out entirely. The team developed a custom script called Machina, which programs the robot to adjust its actuation depth for every single cell in the lattice. Because the cells vary in size across the panel, a uniform press would cause the metal to fail. The script scales the force to each cell’s geometry, working right up to the material’s yield limit without crossing it. It’s precision at a scale that a human hand simply couldn’t replicate.

But precision isn’t the point. Craft is. The team was genuinely asking whether robotic automation could learn the intuitions of handmaking: the responsiveness to material, the calibration to context, the sense that a gesture should change depending on where you are in the process. Most industrial fabrication doesn’t care about any of that. Hikarigami does. And to me, that’s the more interesting question.

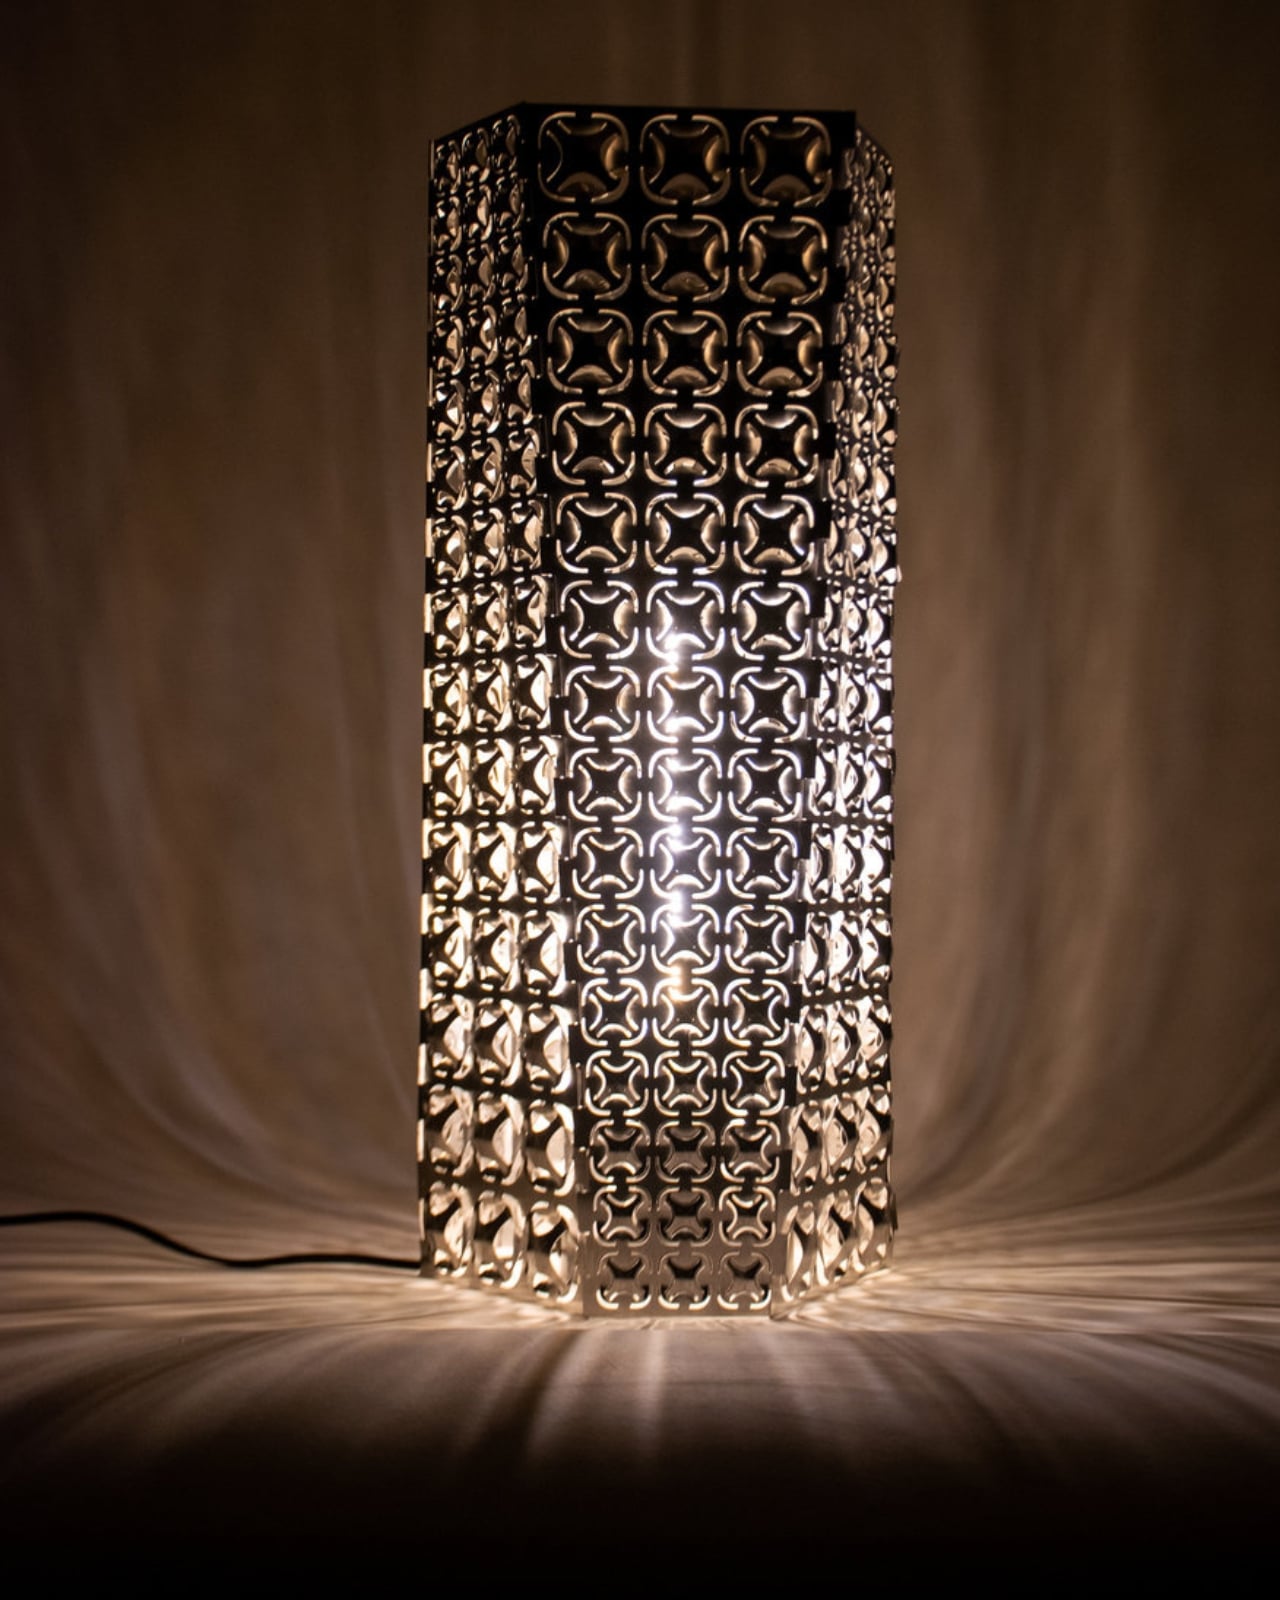
The result is a tower made of six identical aluminum panels with no fasteners, no adhesives. The panels interlock through tabs built directly into the geometry, which means the whole assembly is a single material: pure aluminum, fully recyclable, and designed to age gracefully. The team noted that over time, the aluminum will develop a patina shaped by its environment. The lamp doesn’t resist change. It participates in it.

When you turn it on, the experience shifts completely. During the day, Hikarigami reads as architectural, almost industrial, the kind of object that would feel at home in a gallery or a thoughtfully designed living space. At night, with the central LED filament lit, the aluminum skin opens up. The thousands of robotically formed apertures cast overlapping pools of shadow and caustic highlights across every nearby surface. The room becomes part of the lamp. The lamp becomes the room.

It’s worth noting that this is a student project, and I find that genuinely refreshing. It won in the sustainability category at one of design’s most respected annual competitions, and it also picked up a notable distinction in furniture and lighting. For work produced inside an academic program, the level of technical and conceptual rigor here is striking. Beyond the accolades, Hikarigami feels significant because it takes a position. It argues, quietly but clearly, that sustainable design doesn’t have to mean sacrificing beauty or experimentation. That mold-free fabrication can be expressive. That a robot can be a collaborator, not a replacement.

The team divided their roles with intention: Xing led computational design and fabrication, Fiorante handled robotic toolpath programming, Fujinami managed structural assembly, and Zhang contributed to the robotic fabrication process. Together they didn’t just design a lamp. They designed a process, and the lamp emerged from it. That’s the kind of thinking that tends to outlast the object itself.

The post Harvard Students Built a Lamp That Taught a Robot to Make Art first appeared on Yanko Design.
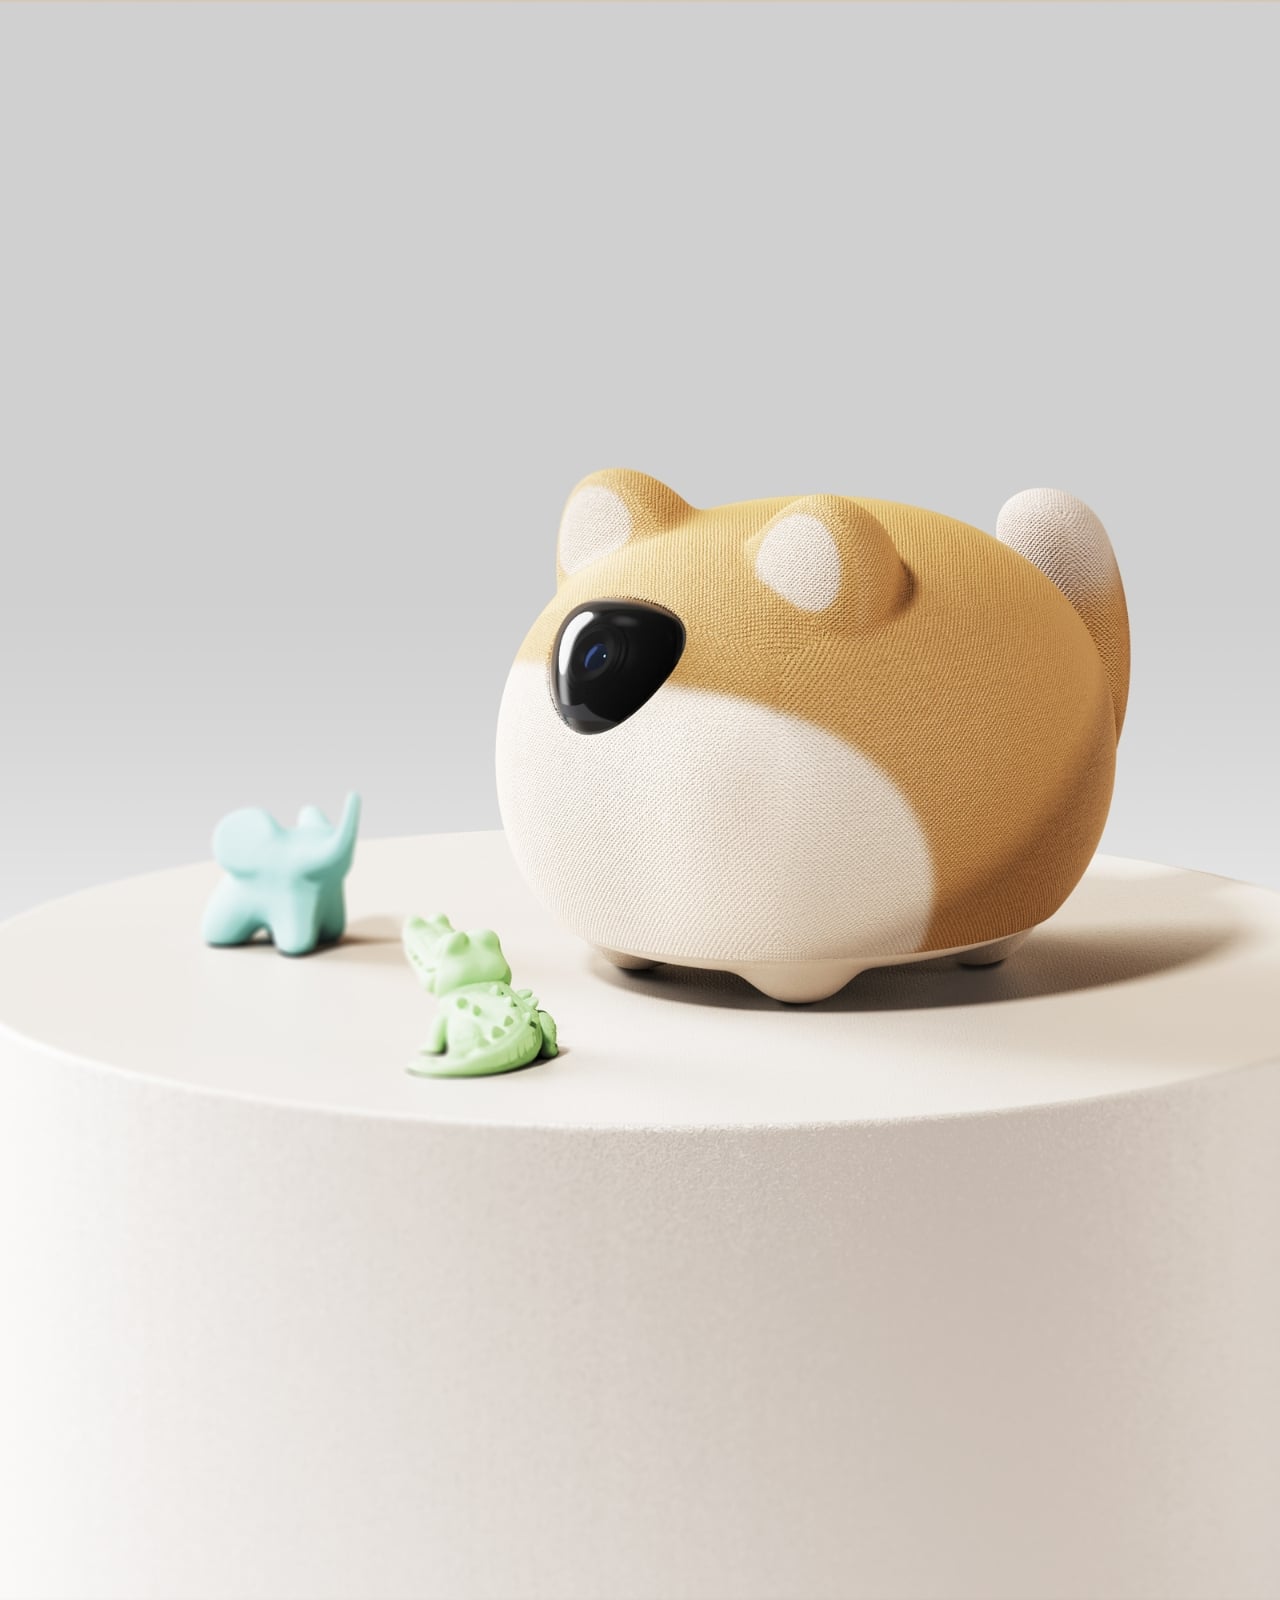
XiaoBu Wants to Be the Most Personal Thing on Your Desk

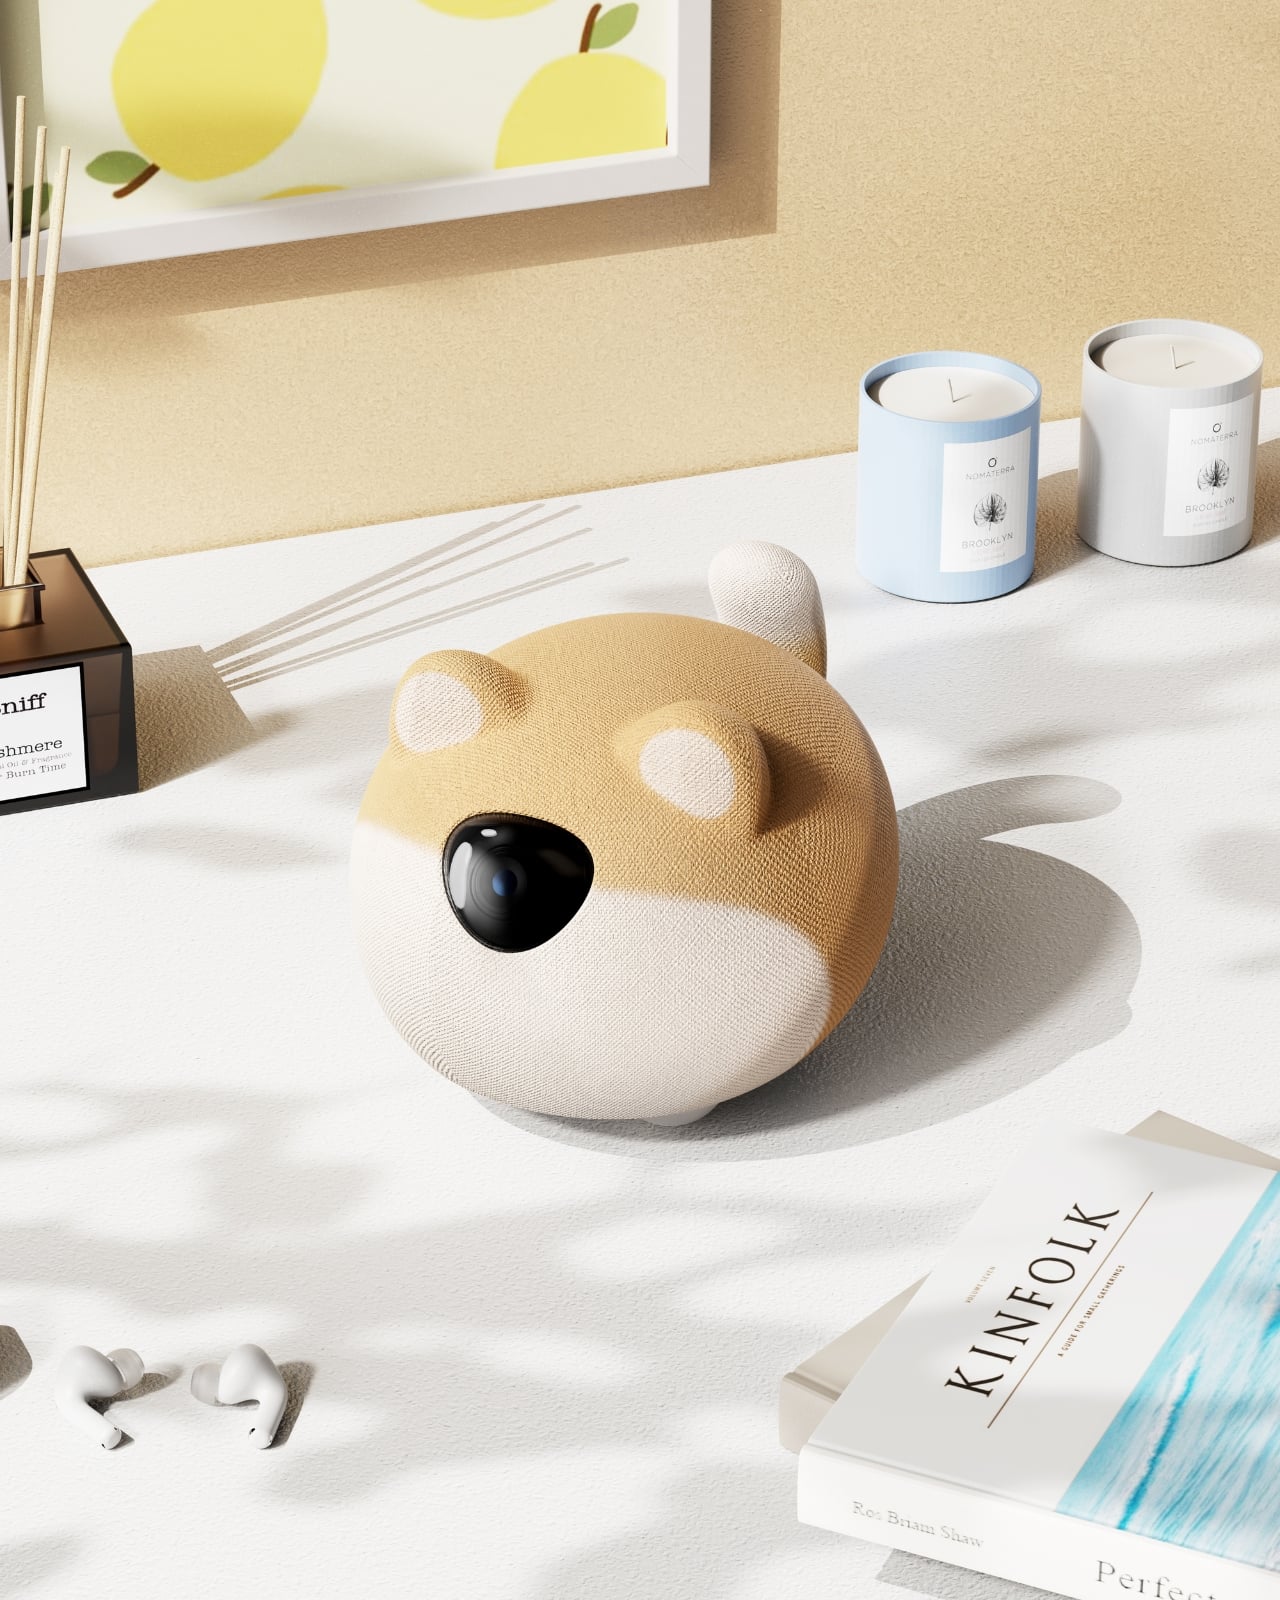
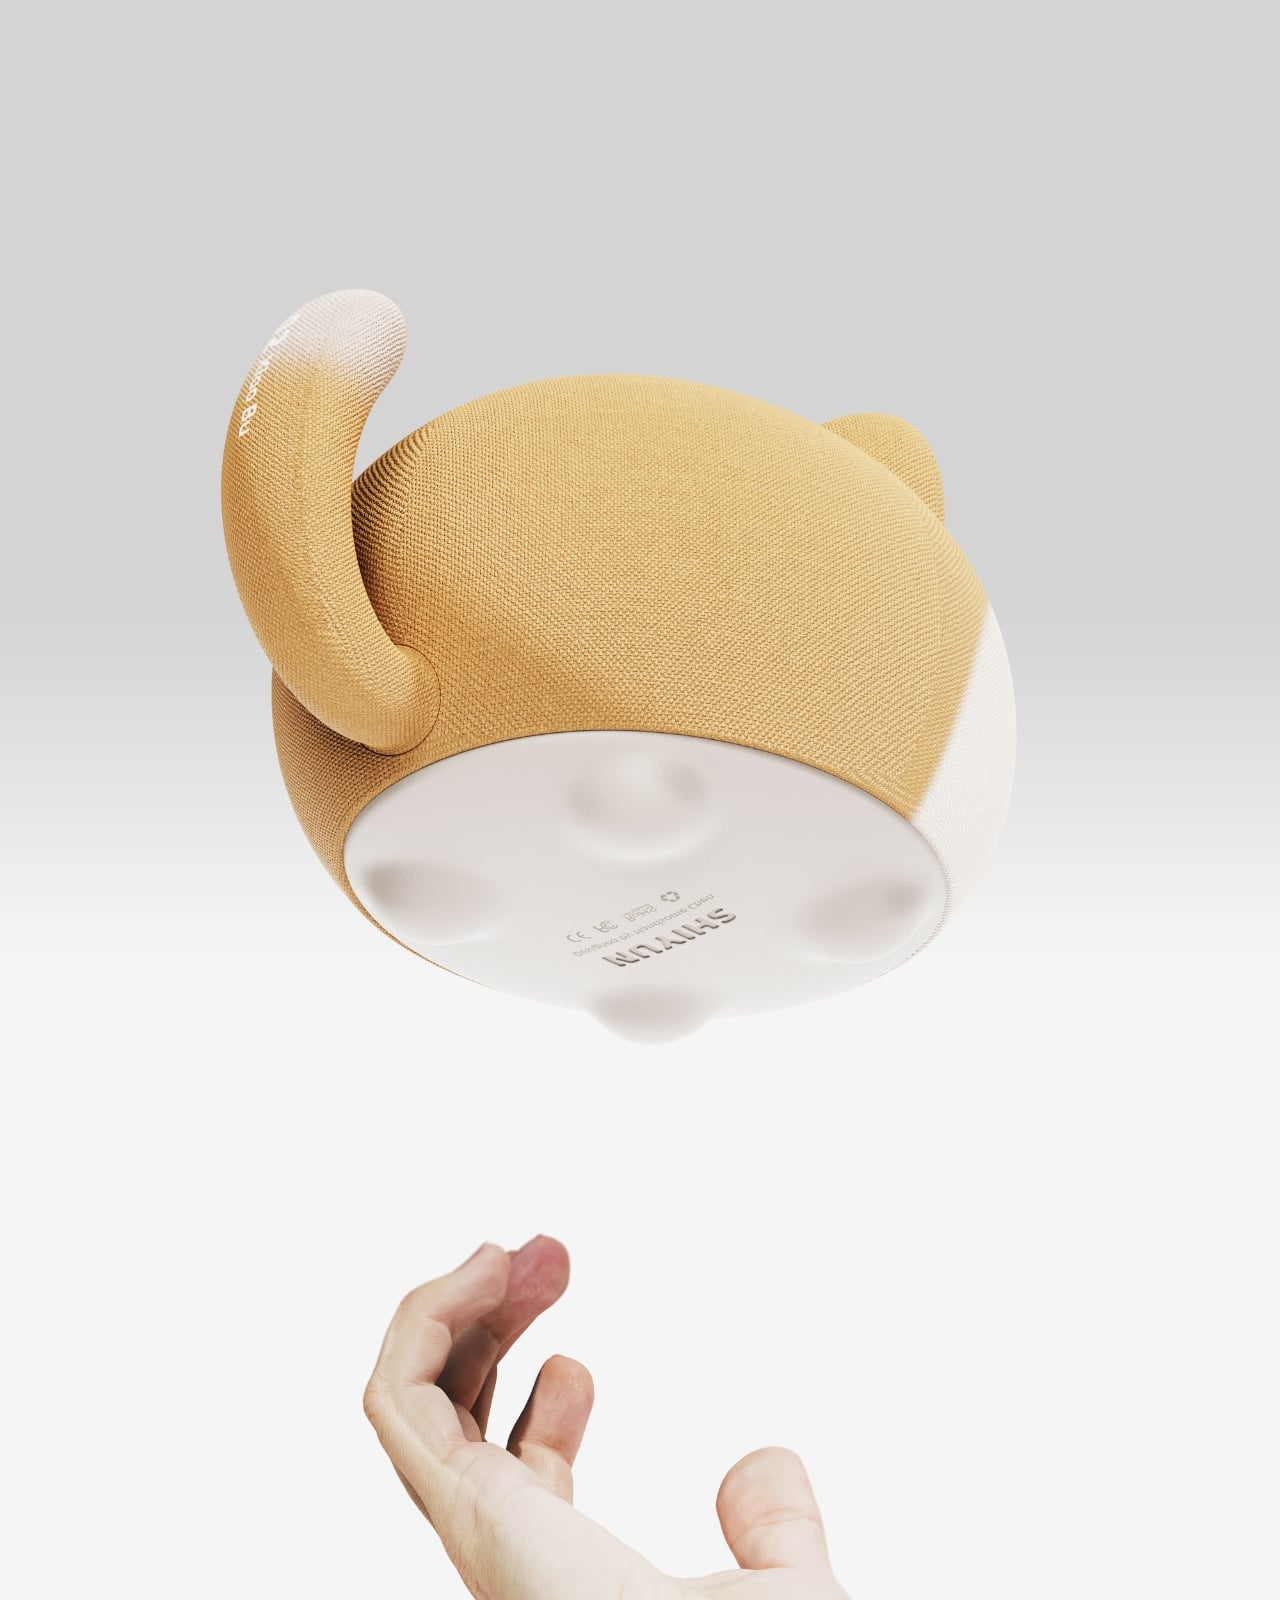
We’ve reached a point where our desks have become a form of personal expression. The plant you chose, the pen holder you 3D-printed, the specific coffee mug that only leaves when it’s being washed – these things say something about who you are. XiaoBu, a desktop companion robot concept by Handsome Chen, is betting that your next statement piece might just say “hello” back.

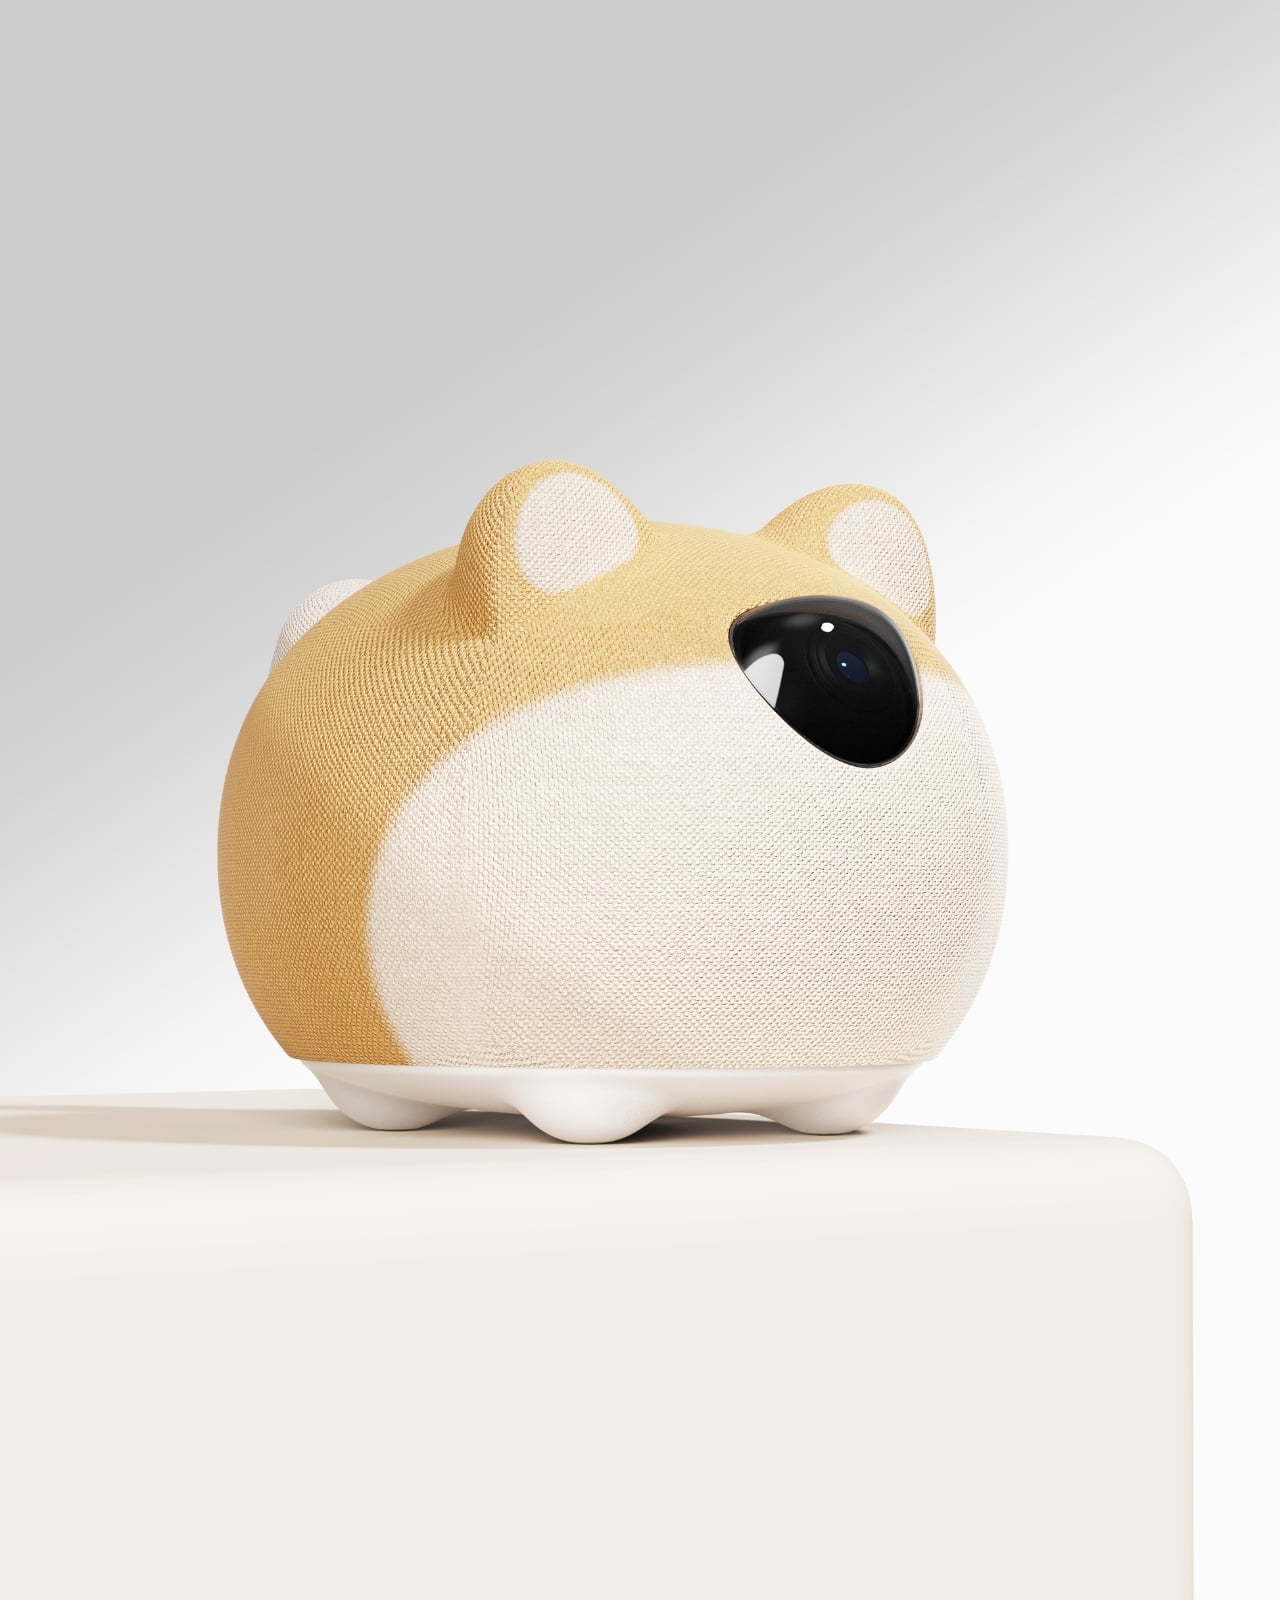
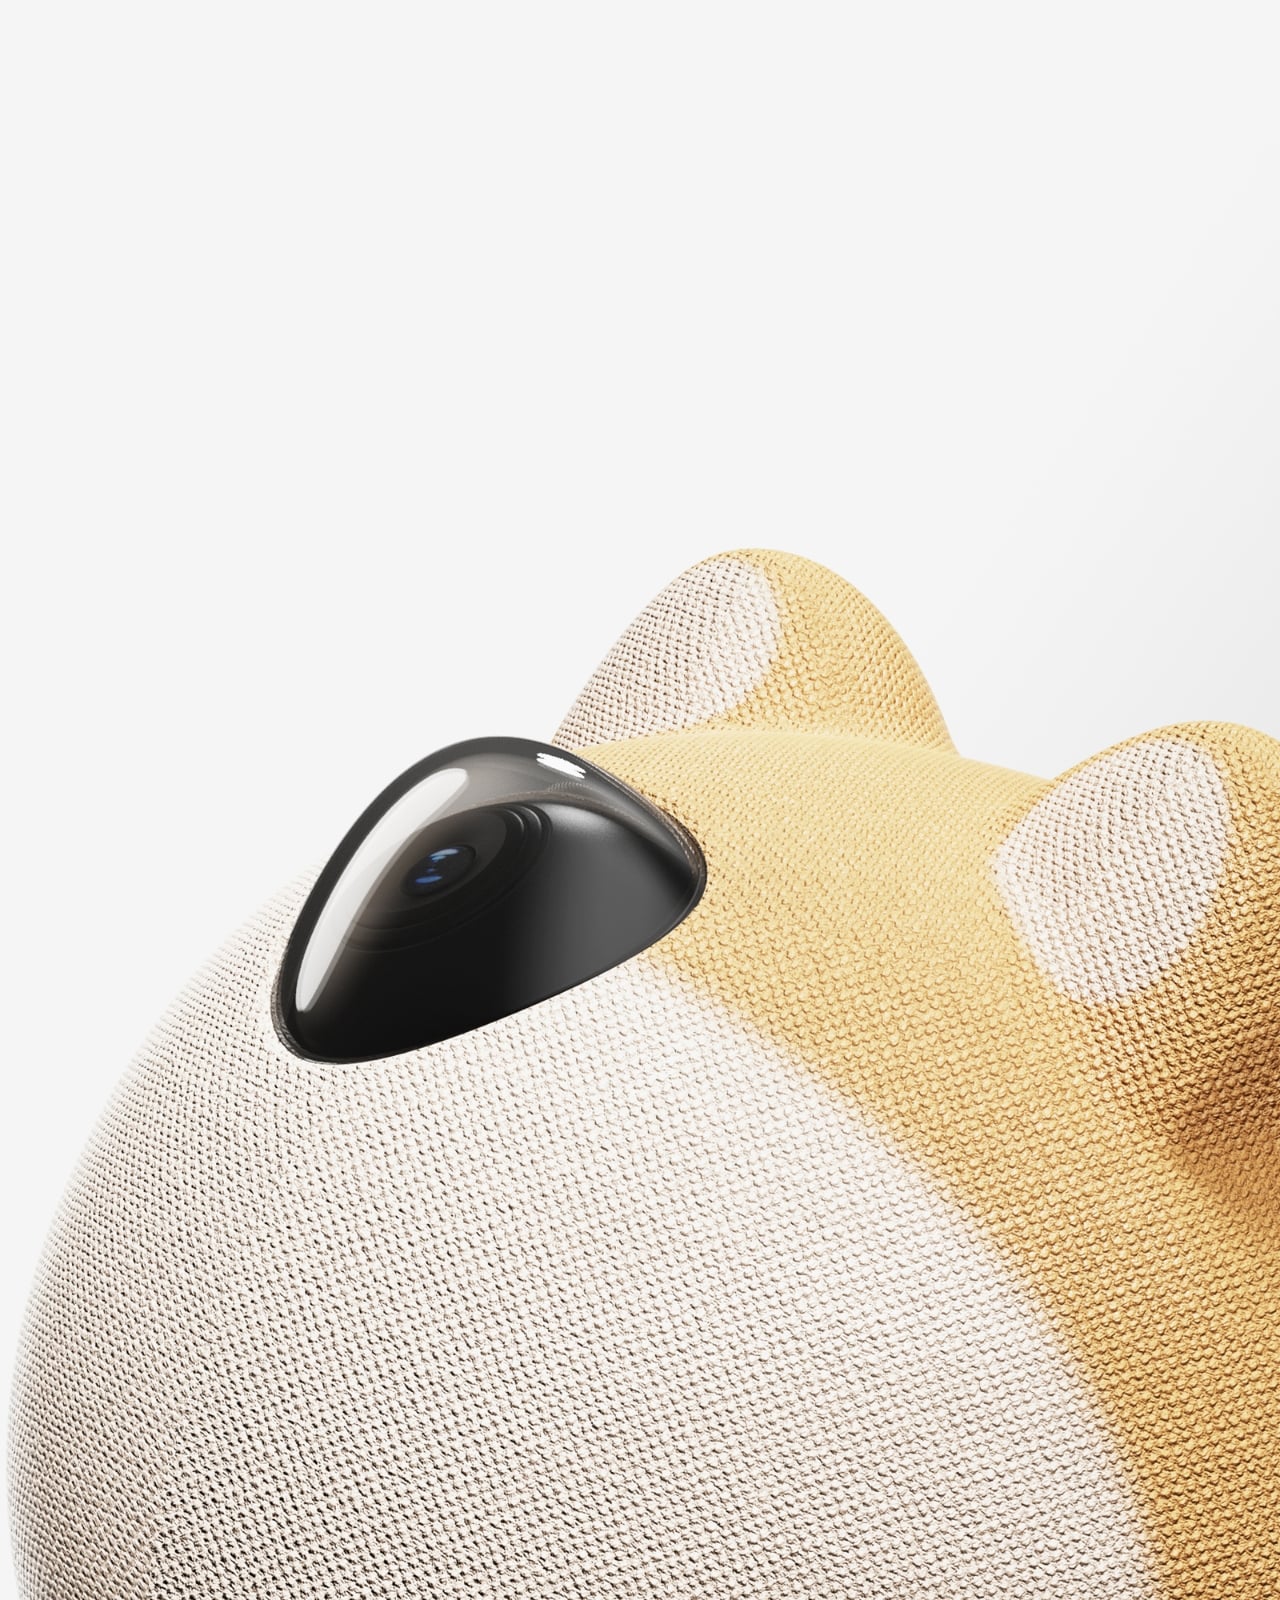
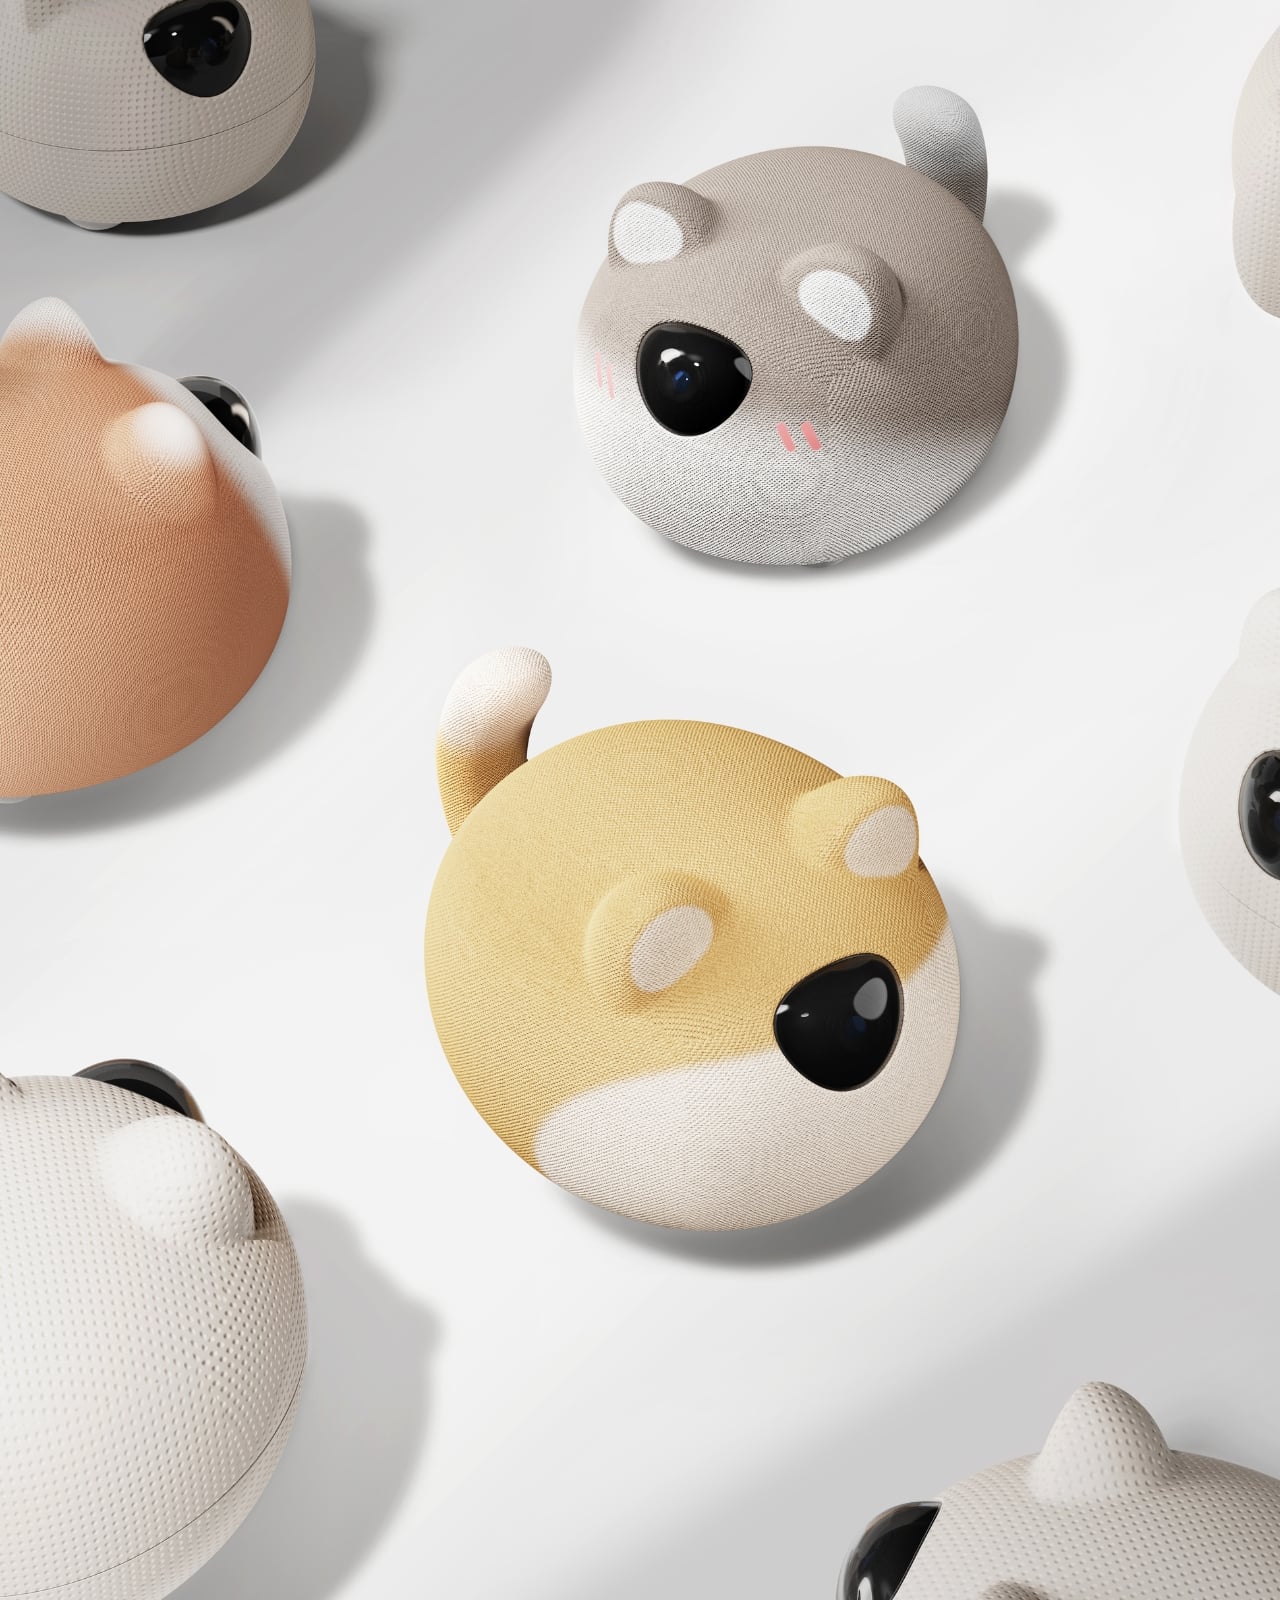
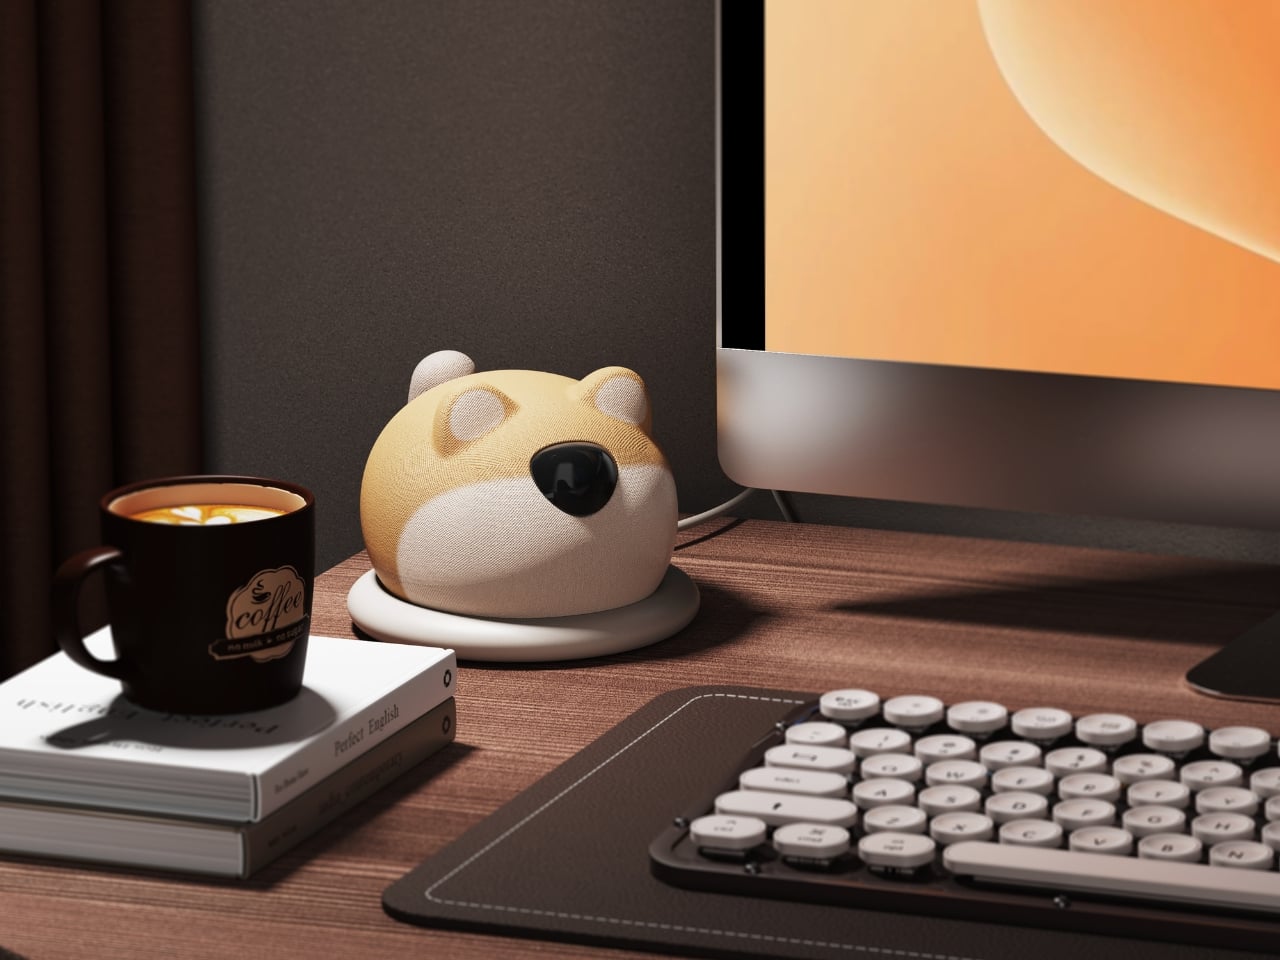
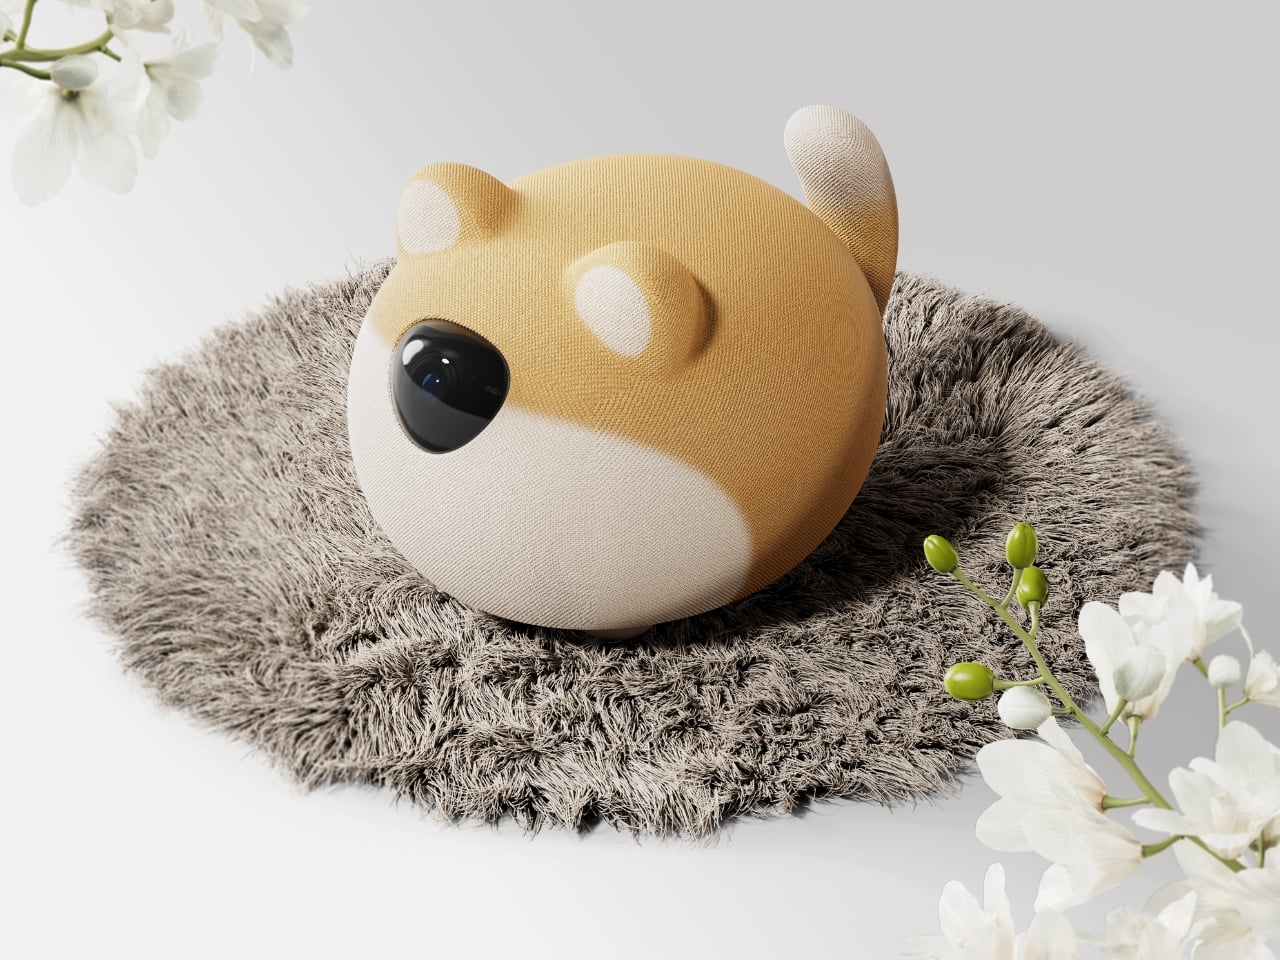
XiaoBu is not a smart speaker with a face. It’s not a Tamagotchi with an engineering degree. It’s a desktop robot that pulls together three things that usually live separately: audio function, emotional interaction, and replaceable fabric skins. The combination is what makes it feel genuinely interesting rather than like another product designed to solve a problem no one actually had. Sit with the concept for a moment, though, and the sum starts to feel quite different from its parts.

Designer: Handsome Chen

The fabric skins are the detail that stopped me mid-scroll. Most companion robots lean hard into hard plastic shells – which makes sense from a durability standpoint, but creates a certain coldness that works against the whole “companion” pitch. XiaoBu takes the opposite direction. By making the outer layer soft and swappable, it invites you to treat it less like a gadget and more like a small, quietly present roommate you can dress according to your mood. That shift in material logic carries a real design philosophy behind it: the idea that emotional connection often starts with touch, texture, and familiarity. It’s the difference between something you pick up because you need it and something you keep because it just feels right having it nearby.

The trend toward desktop companion robots has been building steadily for some time. Products like EMO and Eilik have already carved out a niche for people who want their desk to feel a little more alive – but those largely stick to the personality-through-expression model, where a tiny LED screen becomes the entire emotional vocabulary of the machine. XiaoBu’s approach is quieter and, I’d argue, more considered. It’s not performing for you. It’s designed to live alongside you, and the form reflects that distinction deliberately.

Handsome Chen, the Xi’an-based designer behind the concept, describes XiaoBu as breaking the “static limitations” of traditional desktop objects. It’s a deceptively simple framing, but it gets at something real. Most things on your desk are passive. They sit. They wait. They do nothing unless you reach for them. A companion robot, by design, has to earn its place differently – not just by being useful, but by being present in a way that feels intentional rather than intrusive.

I’ll be upfront: I’m a little skeptical of the word “companion” being attached to consumer tech. It’s an easy word to deploy and a hard promise to keep. But XiaoBu’s design, at least conceptually, seems to understand that emotional resonance can’t be engineered through features alone. It has to be built into the form, the texture, the way the object occupies space. The replaceable skins aren’t just a customization feature – they’re an acknowledgment that the relationship between a person and their space is fluid and always evolving, and the things they keep close should be allowed to evolve too.

What makes XiaoBu feel genuinely fresh in this growing category is that it doesn’t try to impress you with complexity. It doesn’t seem to be chasing a checklist of AI capabilities or competing on specs. The design conversation starts with softness, with audio warmth, with the kind of small, considered decisions that make an object feel like it belongs to you rather than to a product category.

Whether XiaoBu ever moves past concept into production is a separate question, and one I genuinely hope gets answered. Right now it lives on Behance, accumulating thousands of appreciations from people who clearly recognize the same thing I did: that sometimes the most interesting design isn’t the one with the most features. It’s the one that makes you feel like someone actually thought about what it means to share space with you.

The post XiaoBu Wants to Be the Most Personal Thing on Your Desk first appeared on Yanko Design.
Forget Humanoids: Eno Might Be the Robot We Actually Need

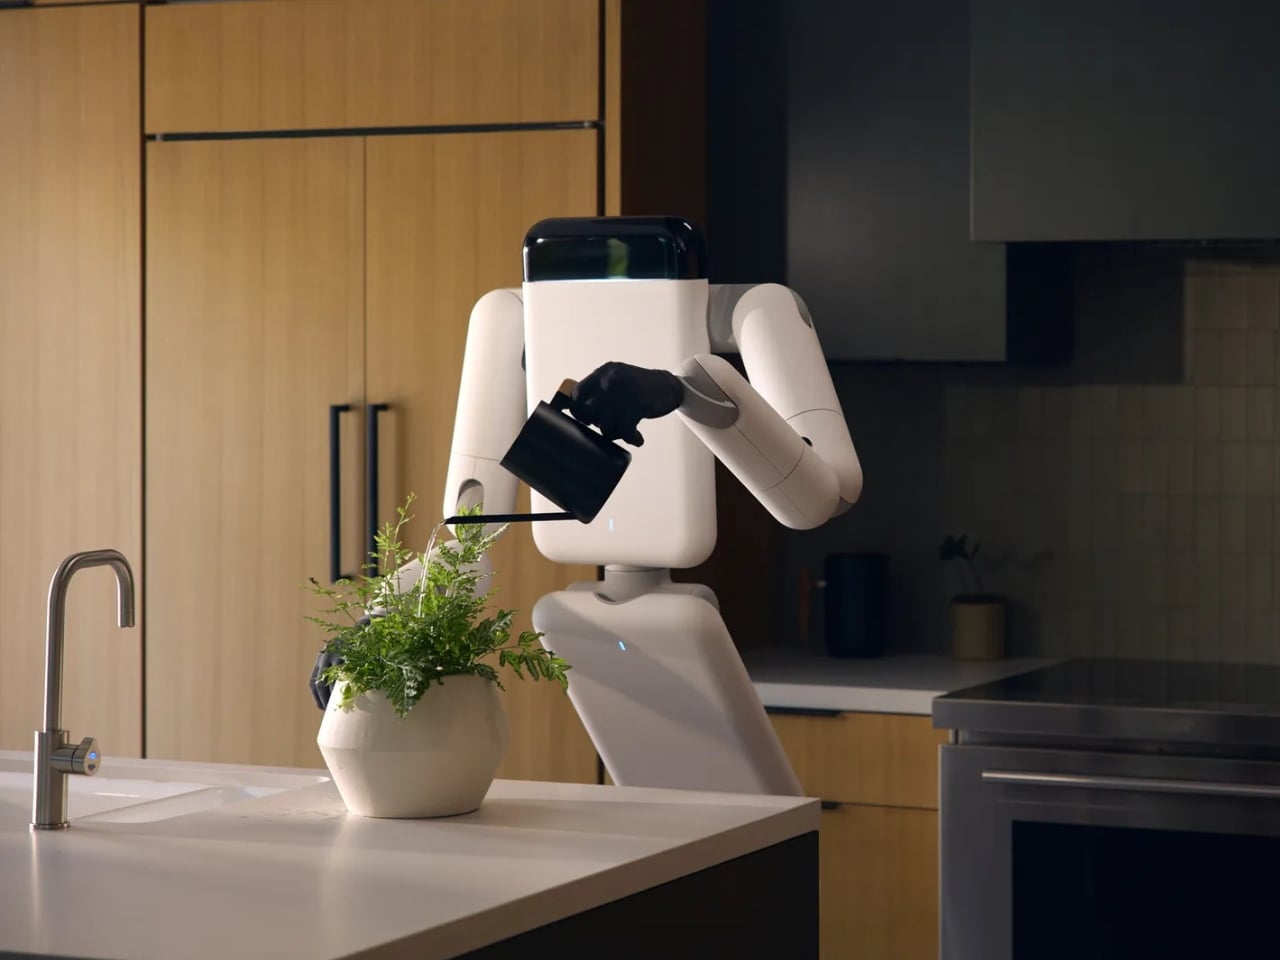
The robot race has been moving in one direction for a while now: two legs, a head, and a shape that clearly spent considerable time studying what a person looks like. It’s a logical instinct. Factories, hospitals, and homes were all designed with human proportions in mind, so a robot built like a human should, theoretically, slot right in. But a growing argument exists that this whole approach might be overthought, and Genesis AI’s new Eno robot is making that case louder than most.

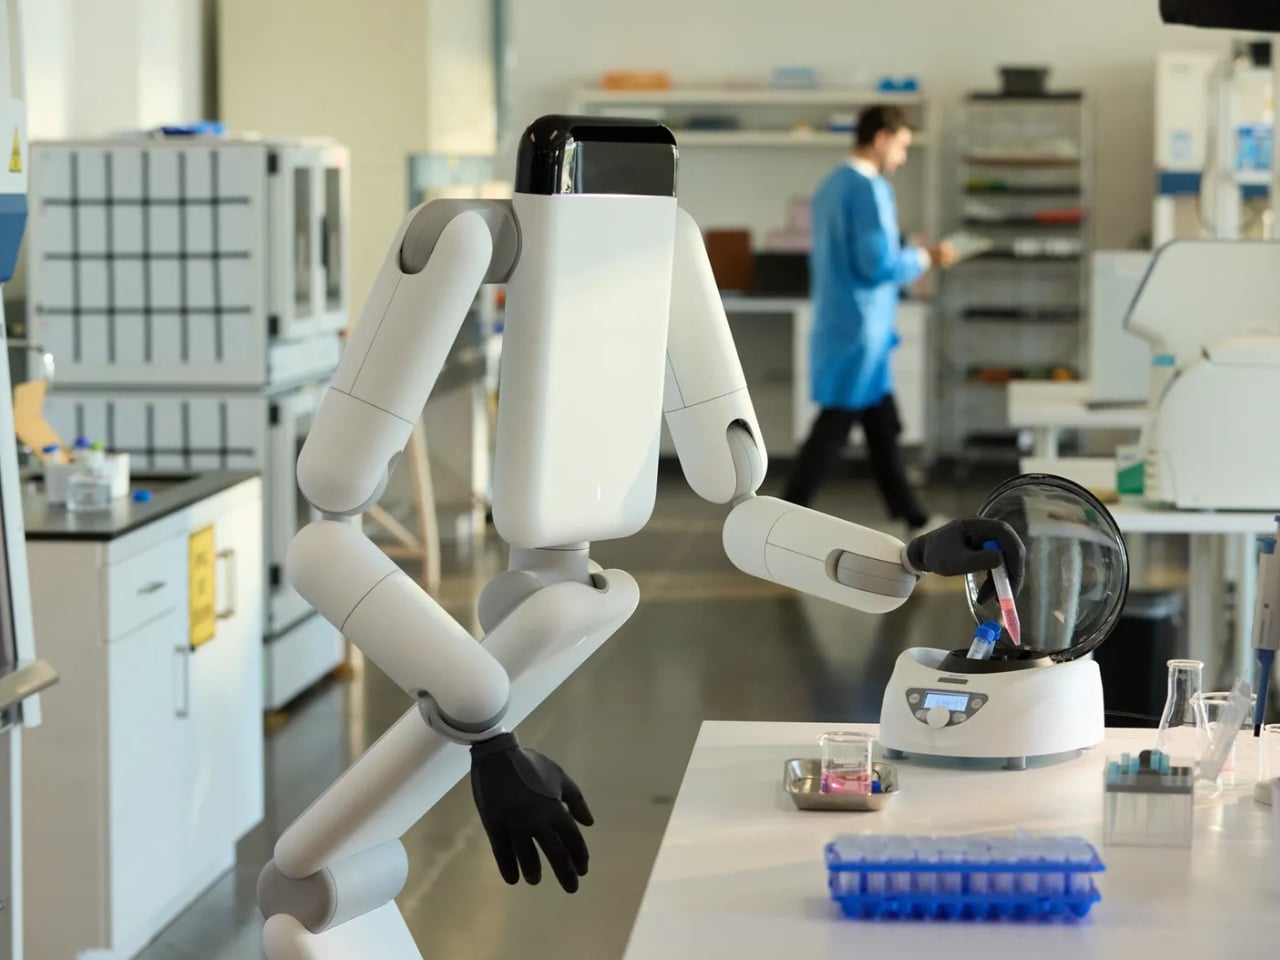
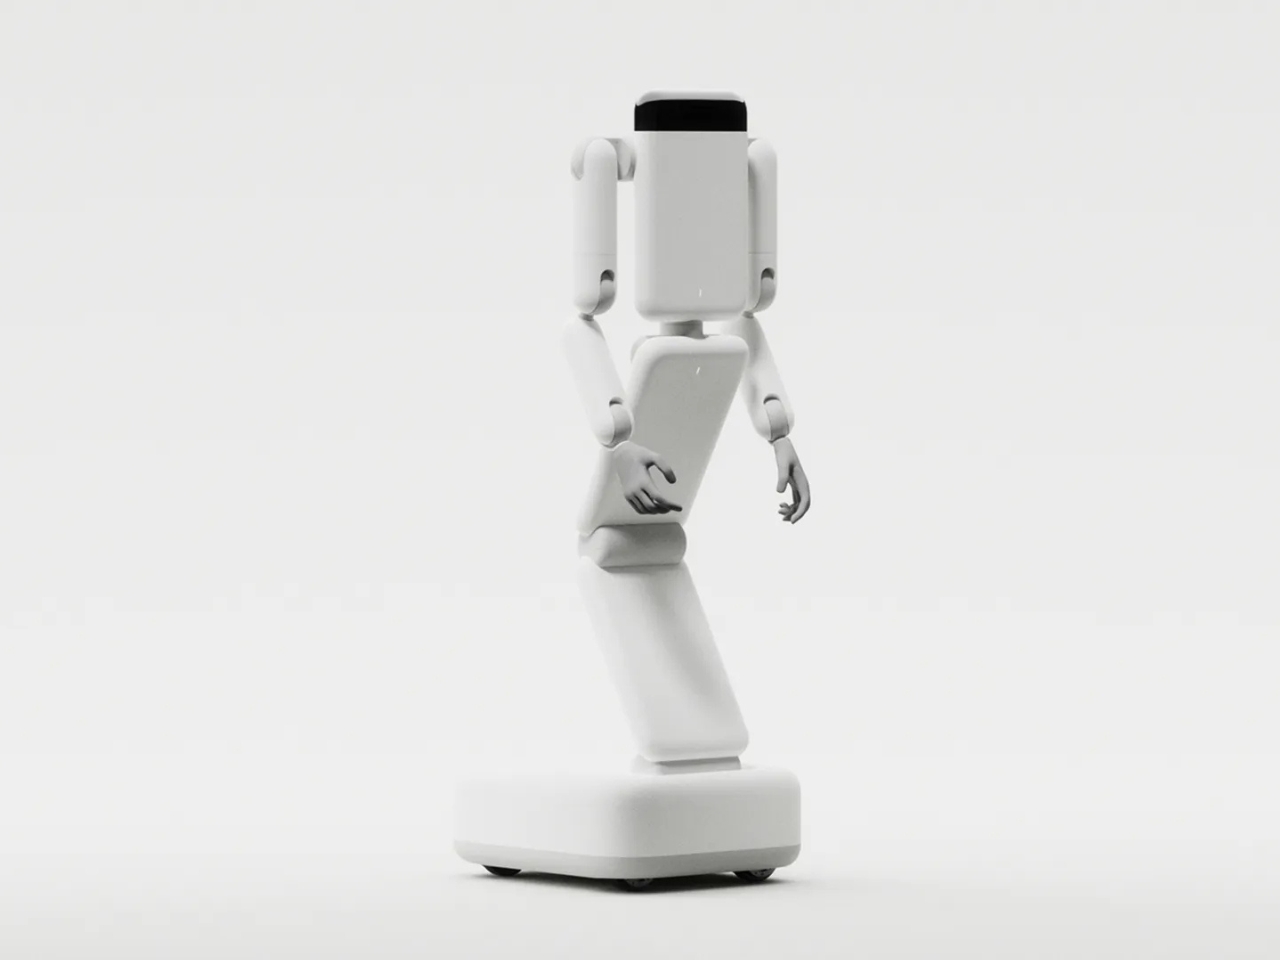
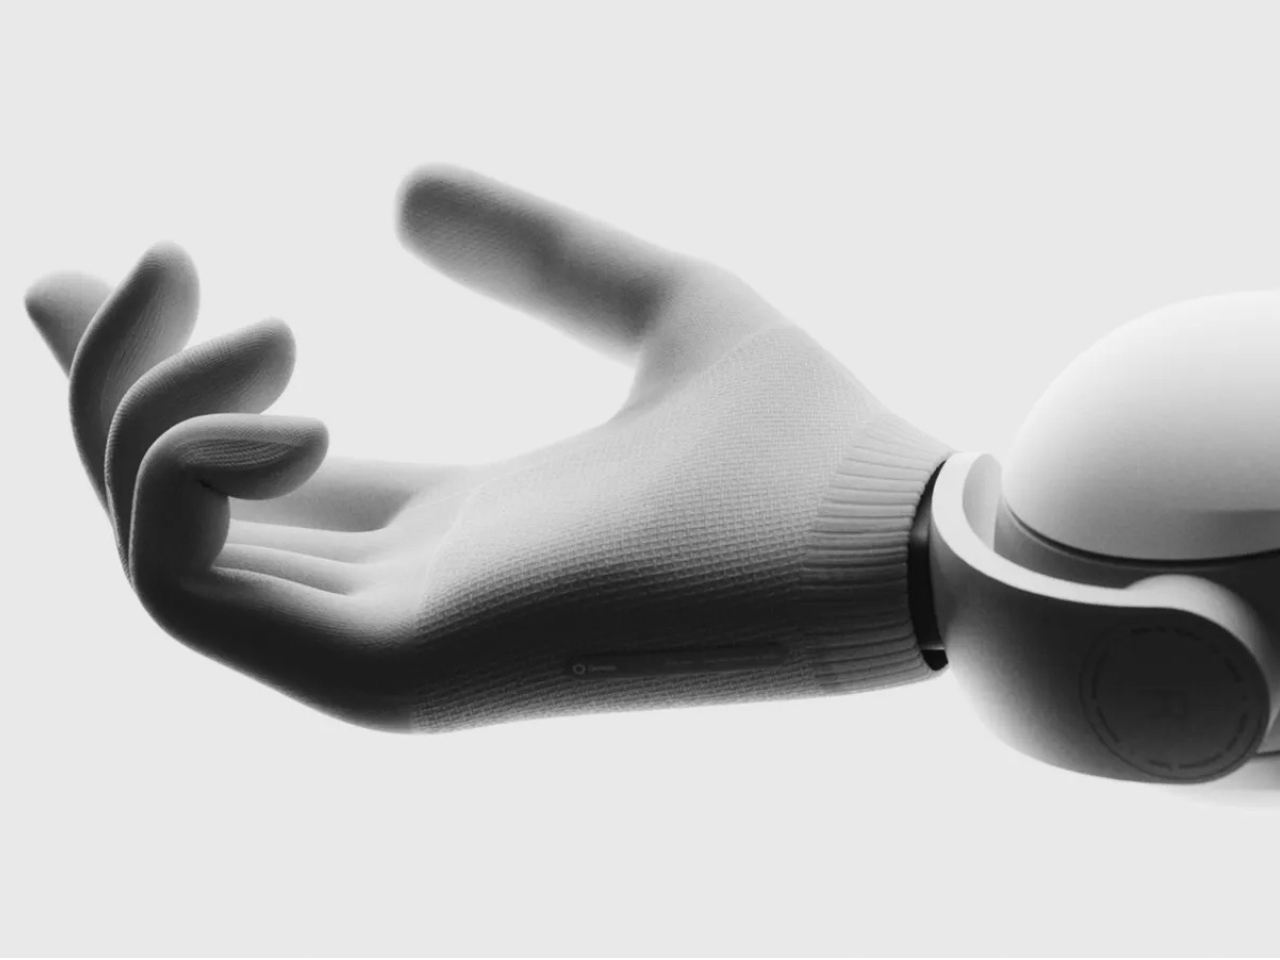
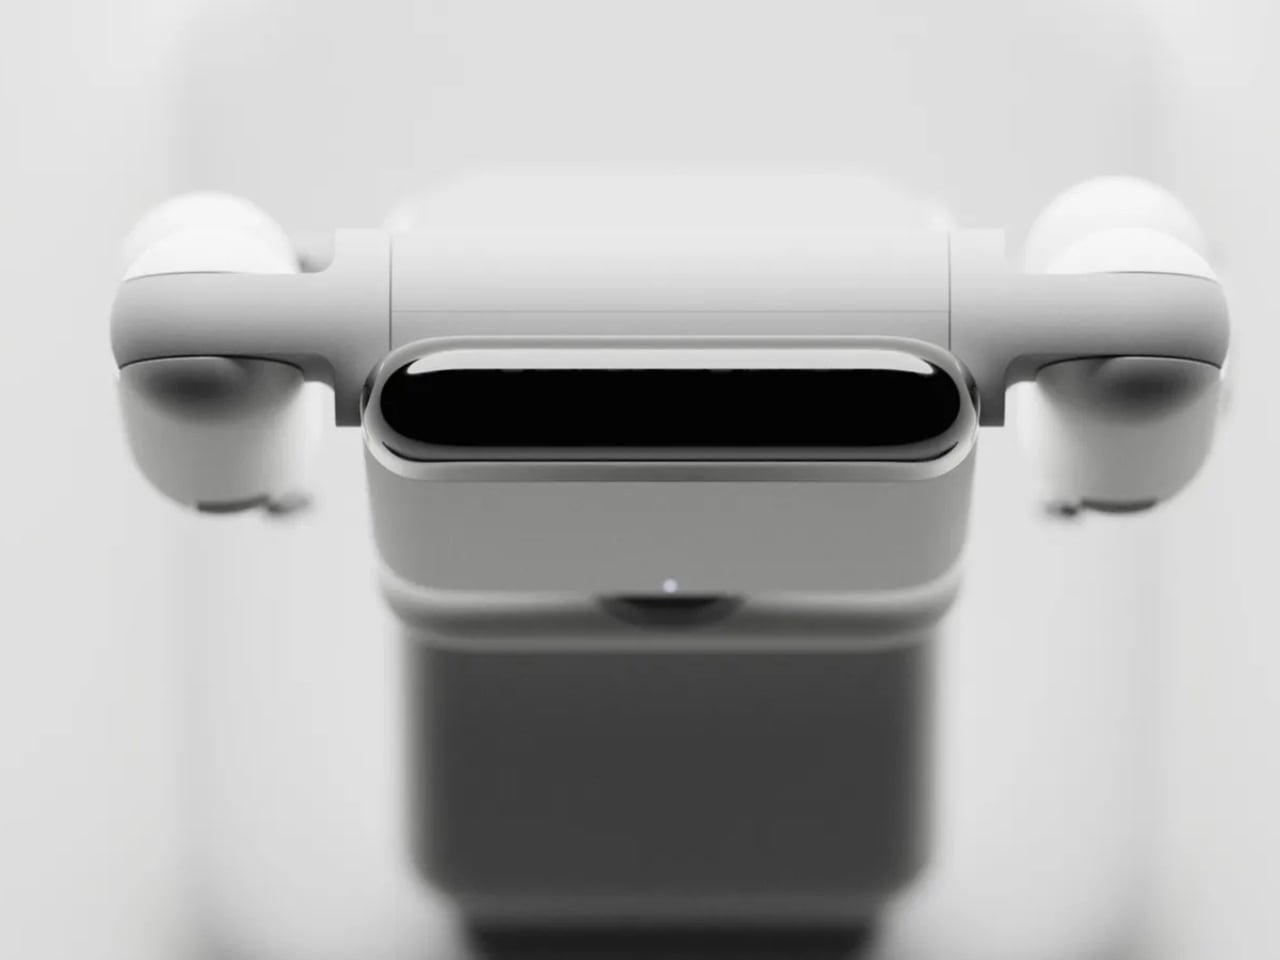
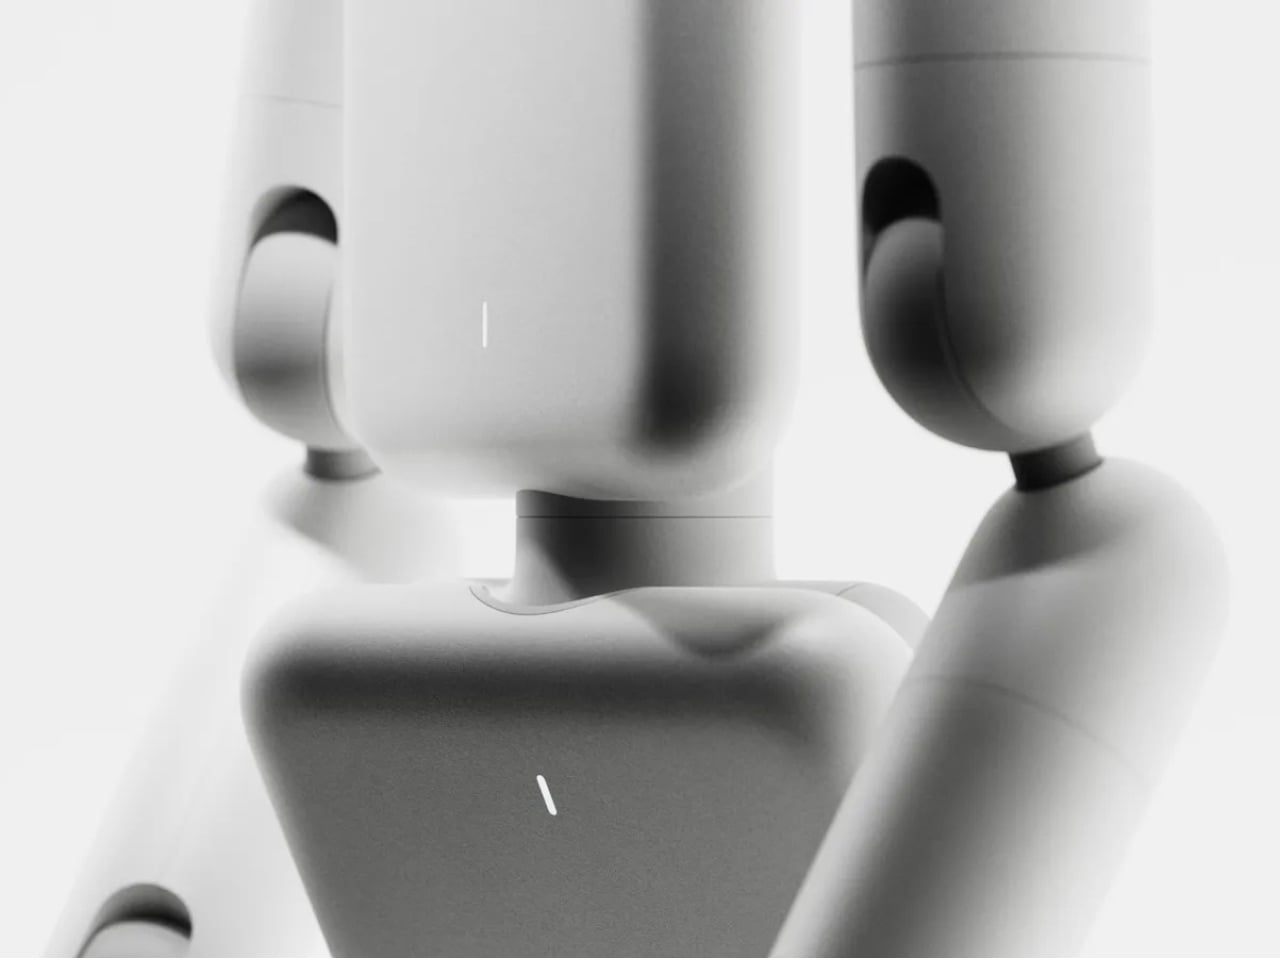
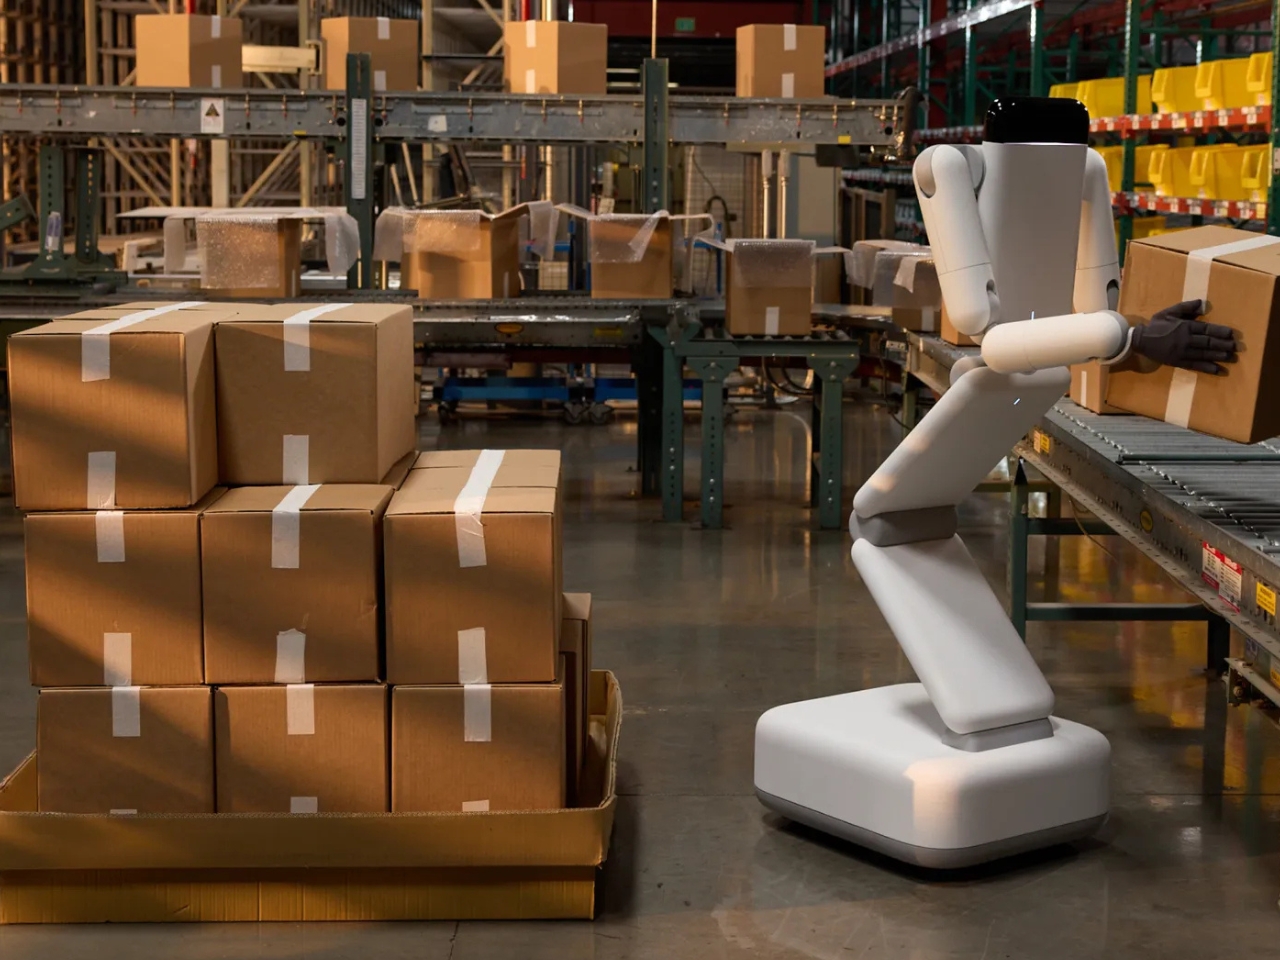
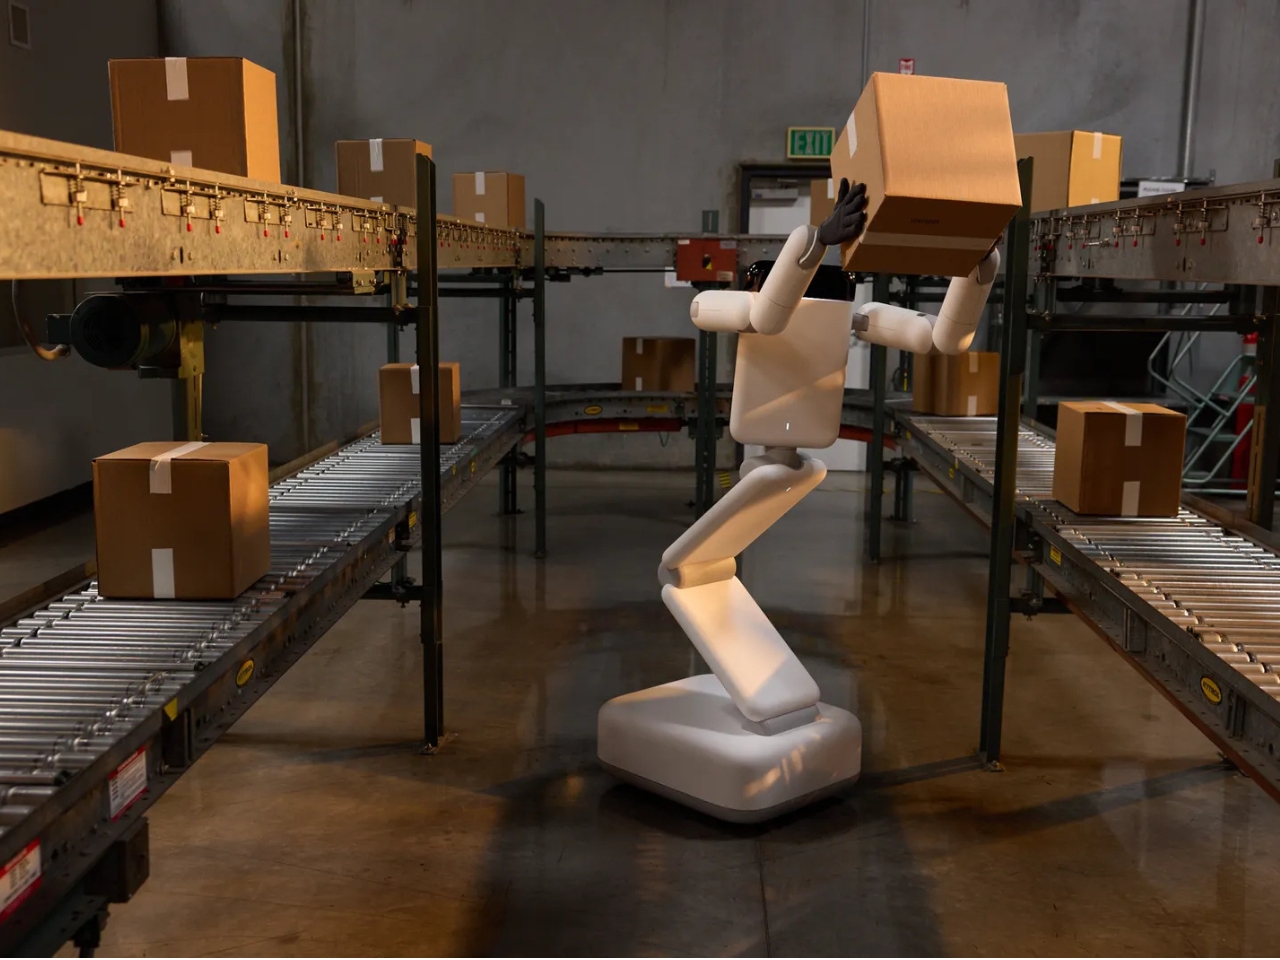
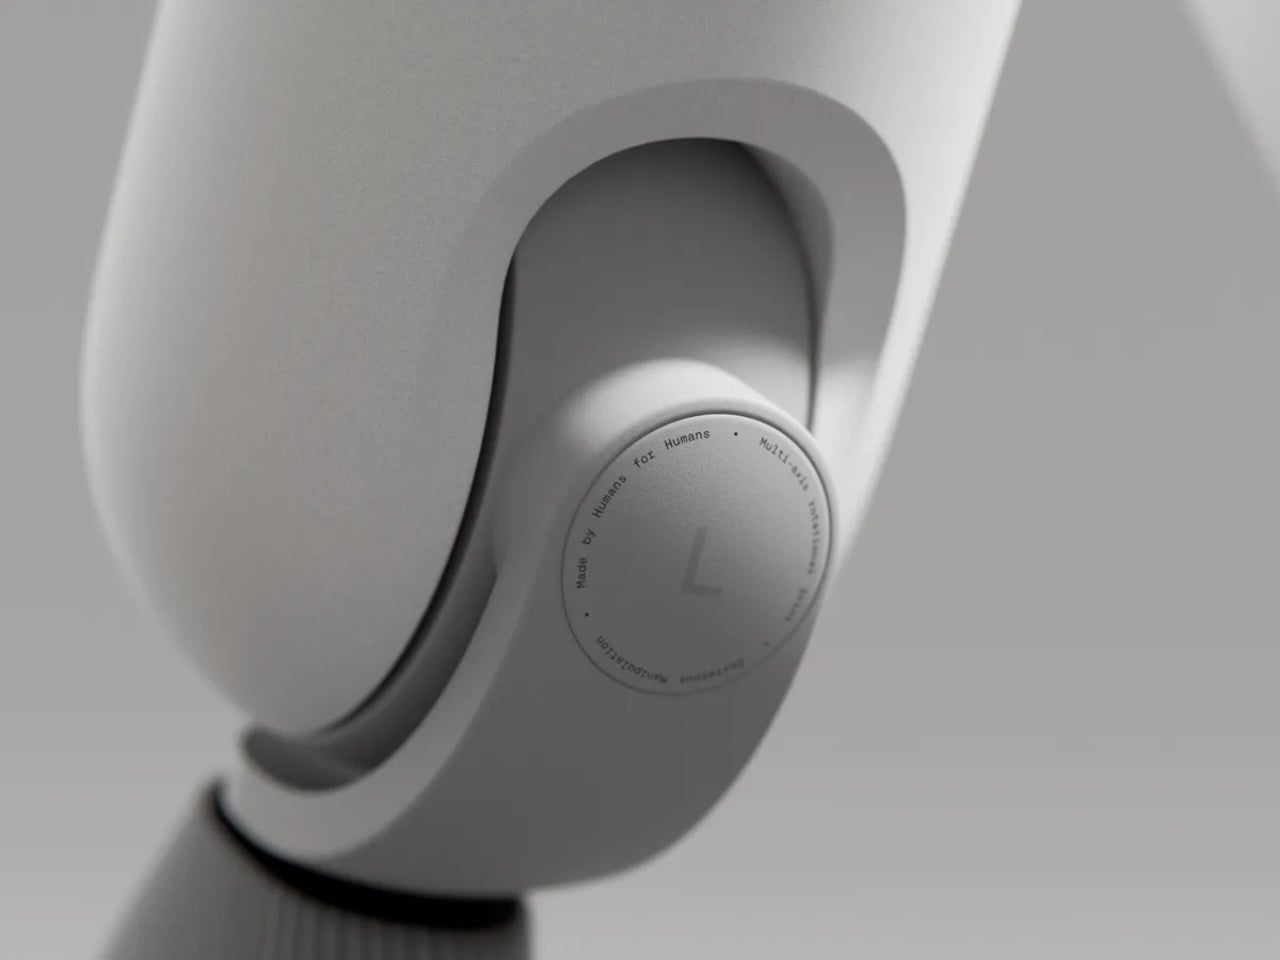
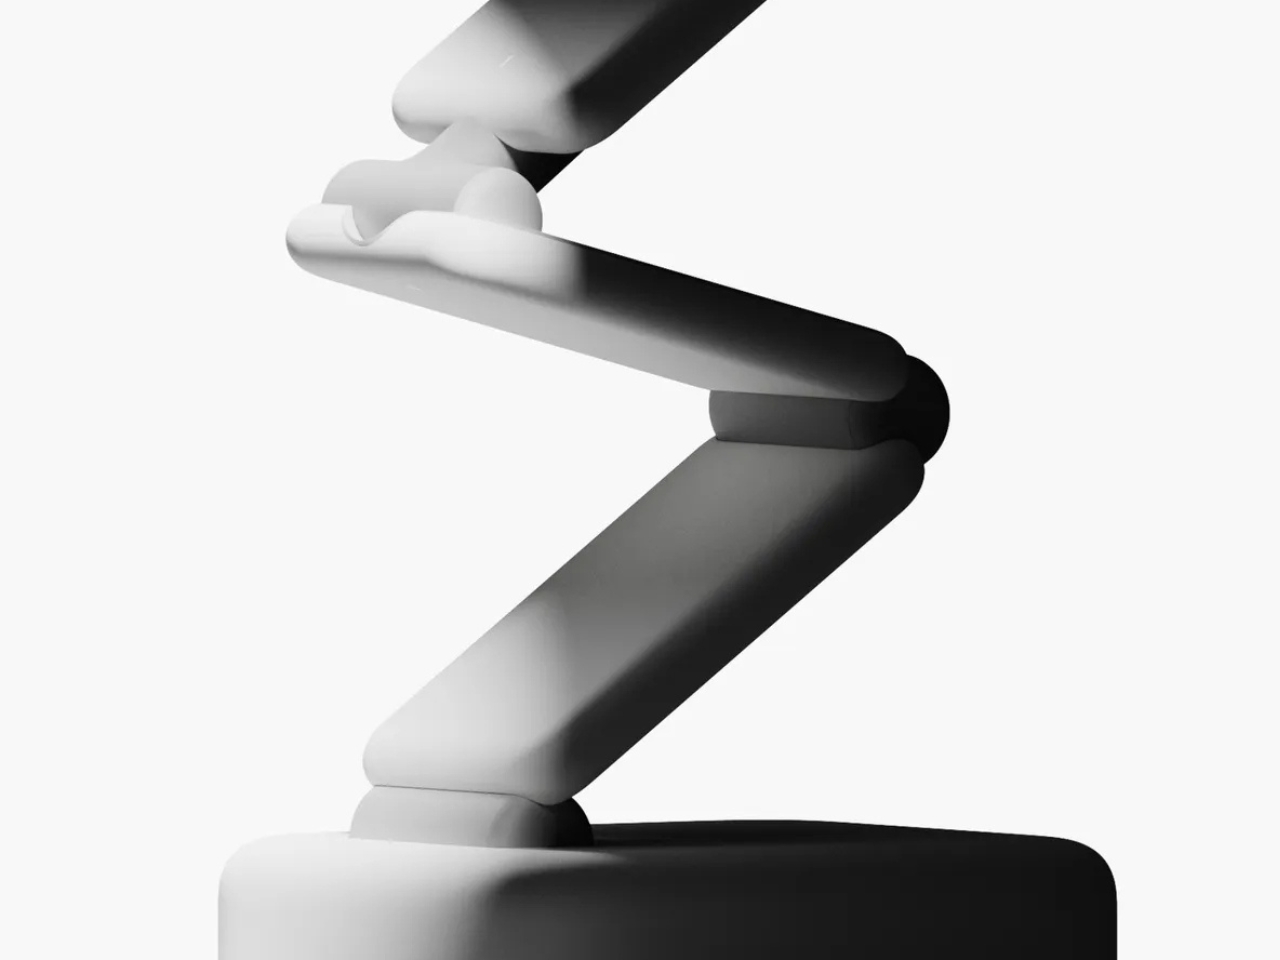
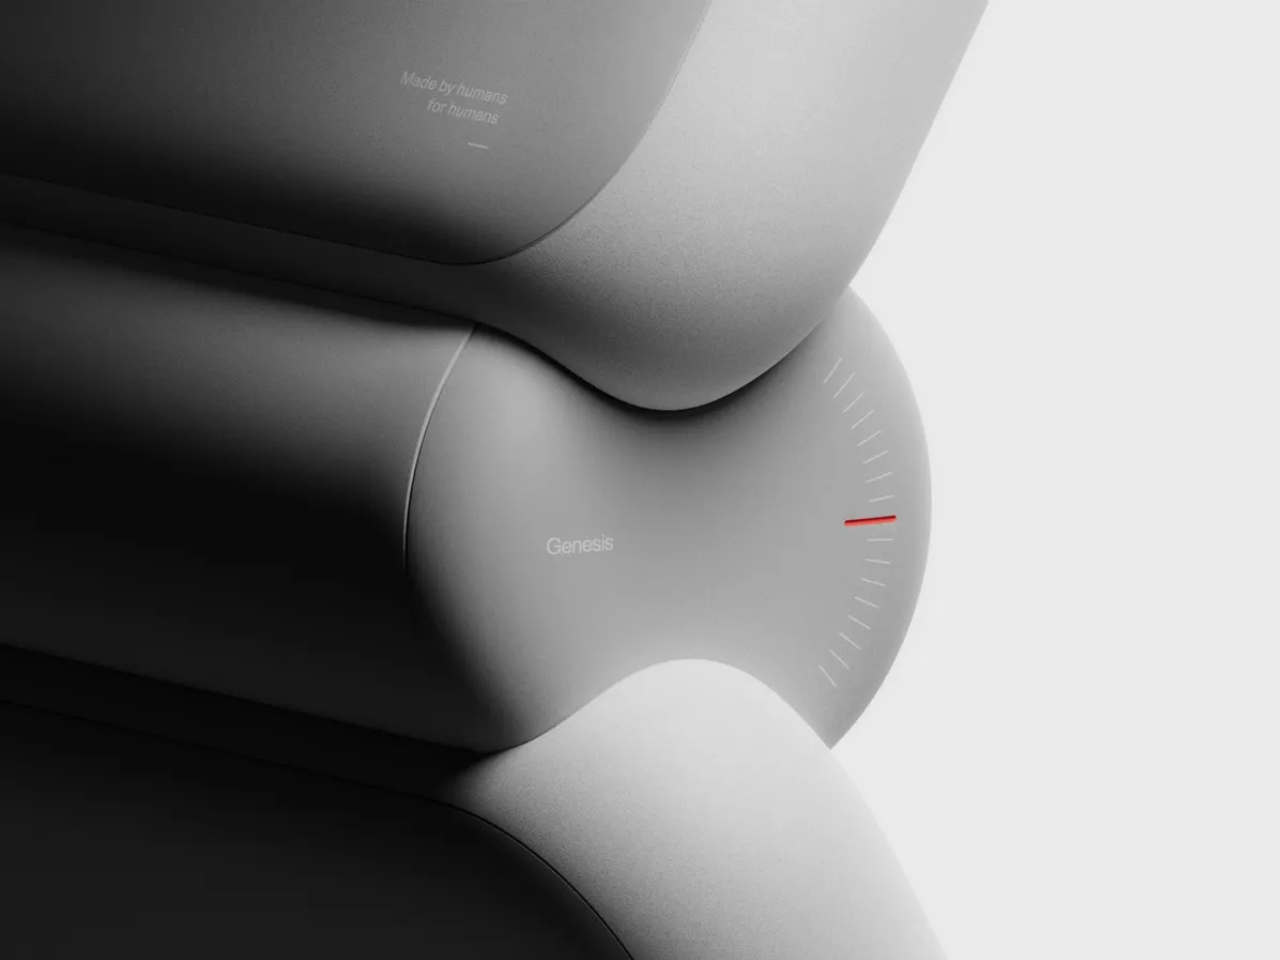
Unveiled this week, Eno is the debut robot from Genesis AI, a San Carlos-based startup that quietly raised $105 million in seed funding and spent that time building something genuinely different. Eno doesn’t walk. It rolls. Its body is a minimalist, articulated tower rising from a wheeled base, with no face and no head in sight. The form adjusts its height and reach as needed, folds down for storage, and carries a pair of proprietary dexterous hands designed to move with the kind of precision and range that human hands are capable of. The result looks more like a sleek industrial sculpture than any robot you’ve seen at a tech keynote.

Designer: Genesis AI

That feels completely intentional. Genesis AI’s head of design, Daniel Hundt, has said that Eno was built by asking a single question first: what does the robot actually need to be? The answer stripped away everything decorative and kept everything functional. No face, because a face isn’t a prerequisite for doing work well. No legs, because legs add cost, complexity, and a surprising number of ways for something to go wrong. What remained was a form built around capability, not aesthetics trying to pass as capability. That’s a meaningful distinction in an industry that sometimes confuses the two.

Eno runs on GENE, Genesis AI’s proprietary robotics-native AI foundation model, and the two were developed together as a single integrated system. This matters more than it might initially seem. A lot of robots in this space are essentially off-the-shelf AI bolted onto hardware that wasn’t designed with it in mind. GENE and Eno were built to complement each other, which means the robot can reason through multi-step tasks, adapt when conditions change, and plan across long time horizons rather than just responding to simple, pre-defined commands. That kind of sustained, adaptive thinking is what separates a useful robot from an expensive demo reel.

For those who want a deeper look at what’s happening under the hood, Genesis AI is offering an optional screen version of Eno featuring a cognitive interface that displays, in real time, what the robot is thinking and processing. It’s an unusual transparency move for a robotics company, and a genuinely smart one. Trust in AI systems tends to erode when people feel like they’re watching a black box make decisions. Showing the work, quite literally, is one way to build confidence in environments where precision matters, like hospitals, labs, or busy production floors.

Deployment is set to begin with industrial customers by the end of 2026, starting with manufacturing, logistics, and laboratory settings before moving into service industries like hotels and hospitals, with consumer and home use following down the line. That rollout sequence makes sense. Controlled industrial environments offer a much cleaner test case for a robot learning the real world than someone’s living room does, and it gives Genesis AI the chance to refine Eno where the stakes of a miscalculation are measured in efficiency rather than anything more personal.

Whether Eno ends up being the robot that finally makes good on the promise of general-purpose robotics remains to be seen. The industry has announced breakthroughs before and delivered timelines that stretched well past the original projections. But Eno feels different in at least one significant way: it isn’t trying to win you over with its looks. It’s making a functional argument, and that alone puts it in a category of its own right now. Sometimes the smartest design choice is knowing exactly what not to include.

The post Forget Humanoids: Eno Might Be the Robot We Actually Need first appeared on Yanko Design.
KEENON Humanoid Pours Drinks at GCS 2026, 100,000 Others Run Hotels

The robotics industry has a curious reputation problem. The machines getting the most attention, walking bipeds that do backflips, aren’t the ones driving real business value. By 2030, professional service robots are projected to account for $90 billion of a $161 billion global market, growing at 24.6% annually. That makes them the fastest-growing segment in robotics, which is a fact that barely makes the news.

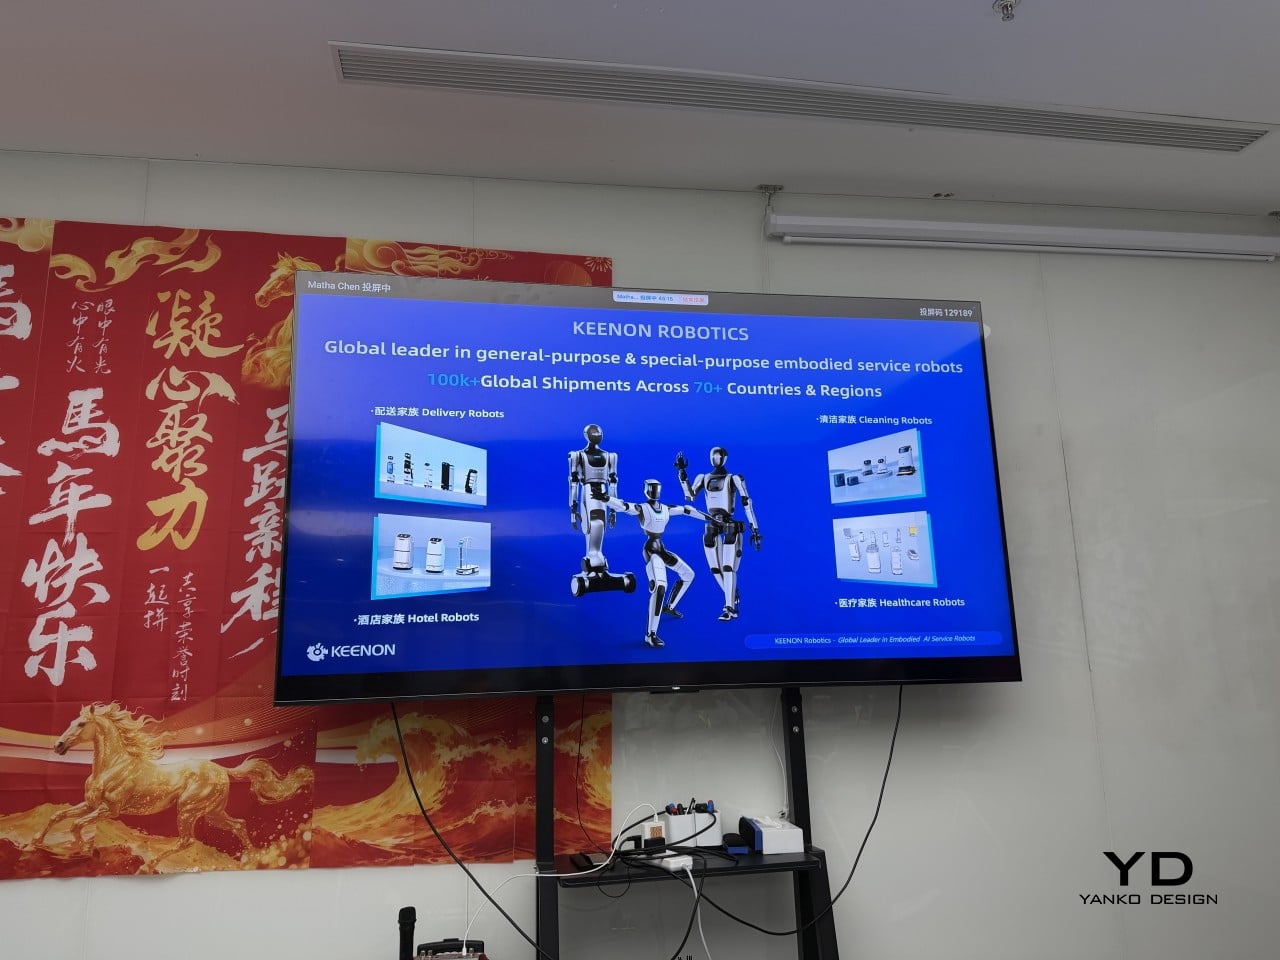
KEENON Robotics has known this for a while. Founded in 2010, the Shanghai-based company didn’t wait for the hype cycle; it built the service delivery robot category from the ground up. Today, with over 100,000 units shipped across more than 60 countries, KEENON holds the number-one global market share in commercial service robots for the third consecutive year, according to IDC 2025.

Designer: KEENON Robotics

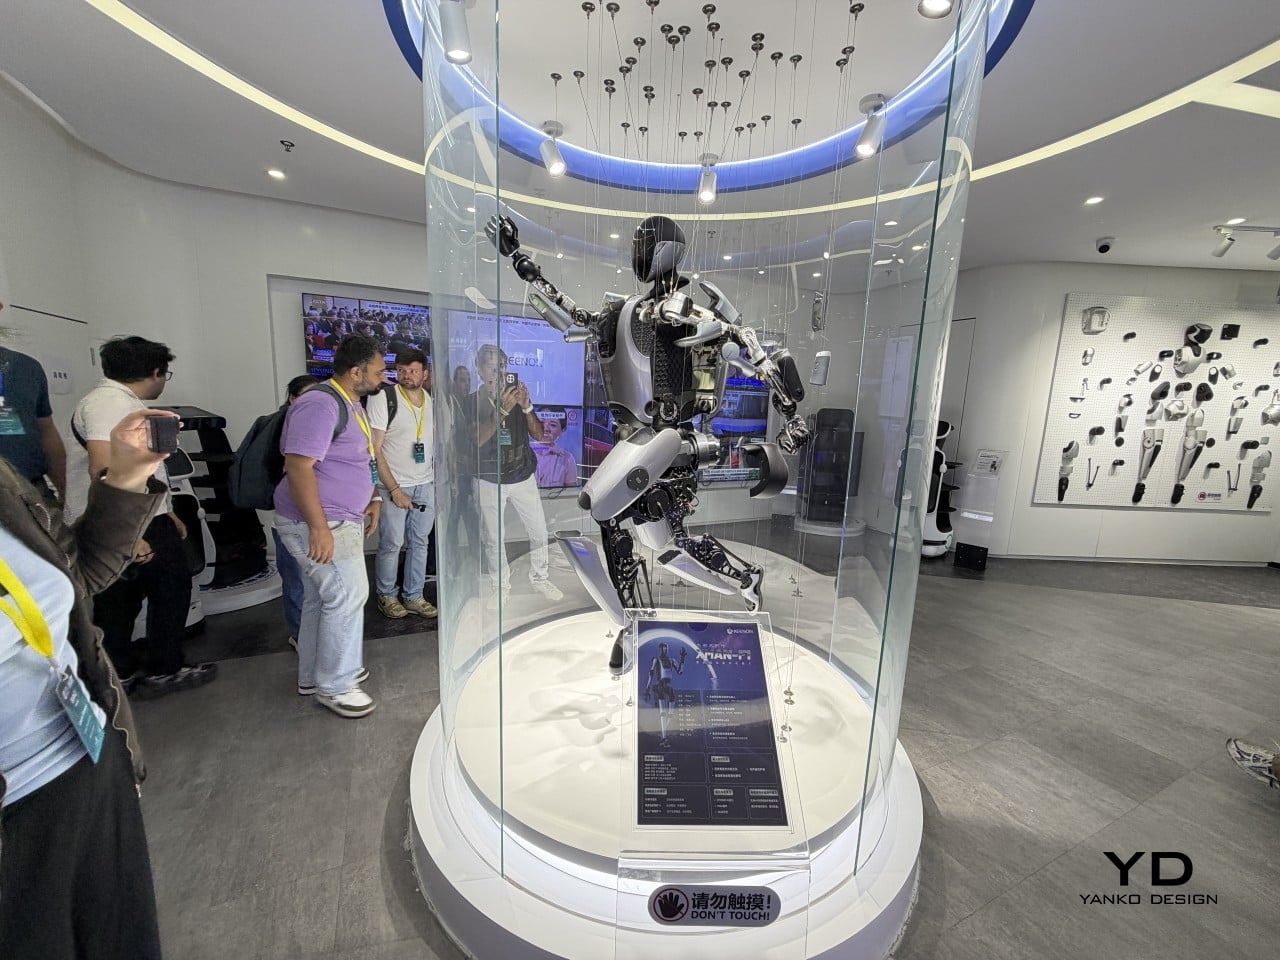
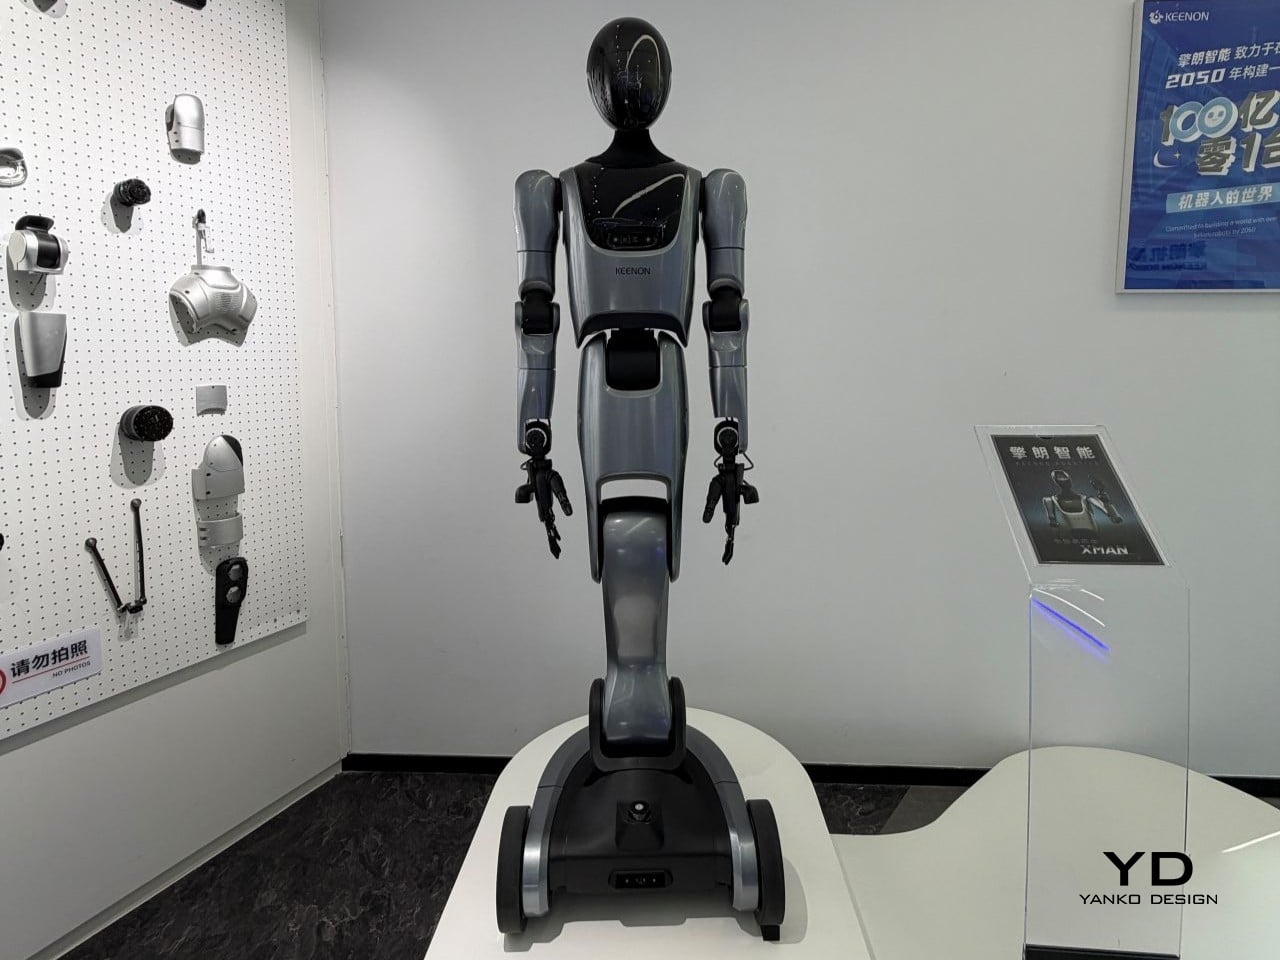
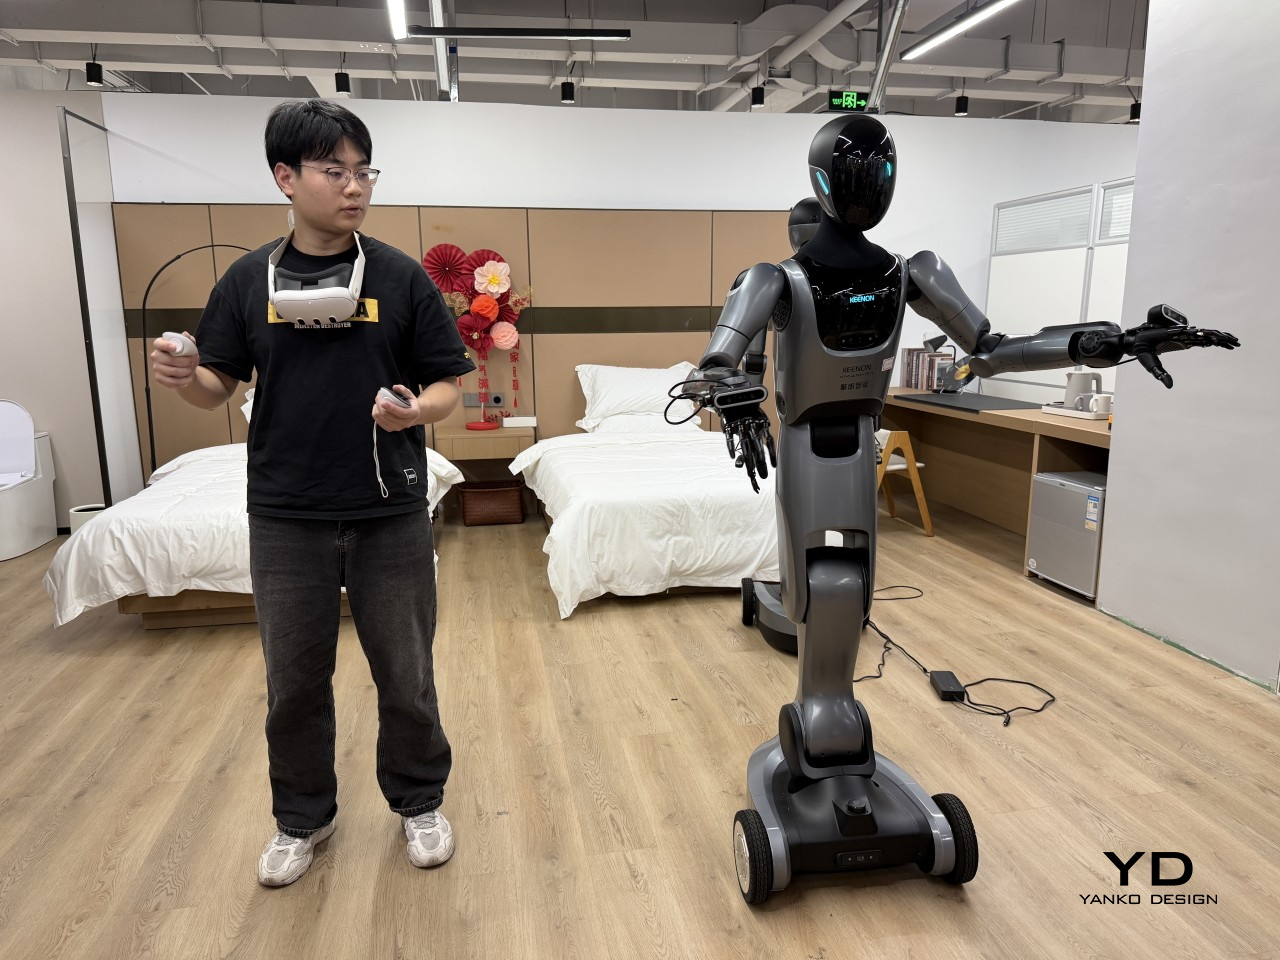
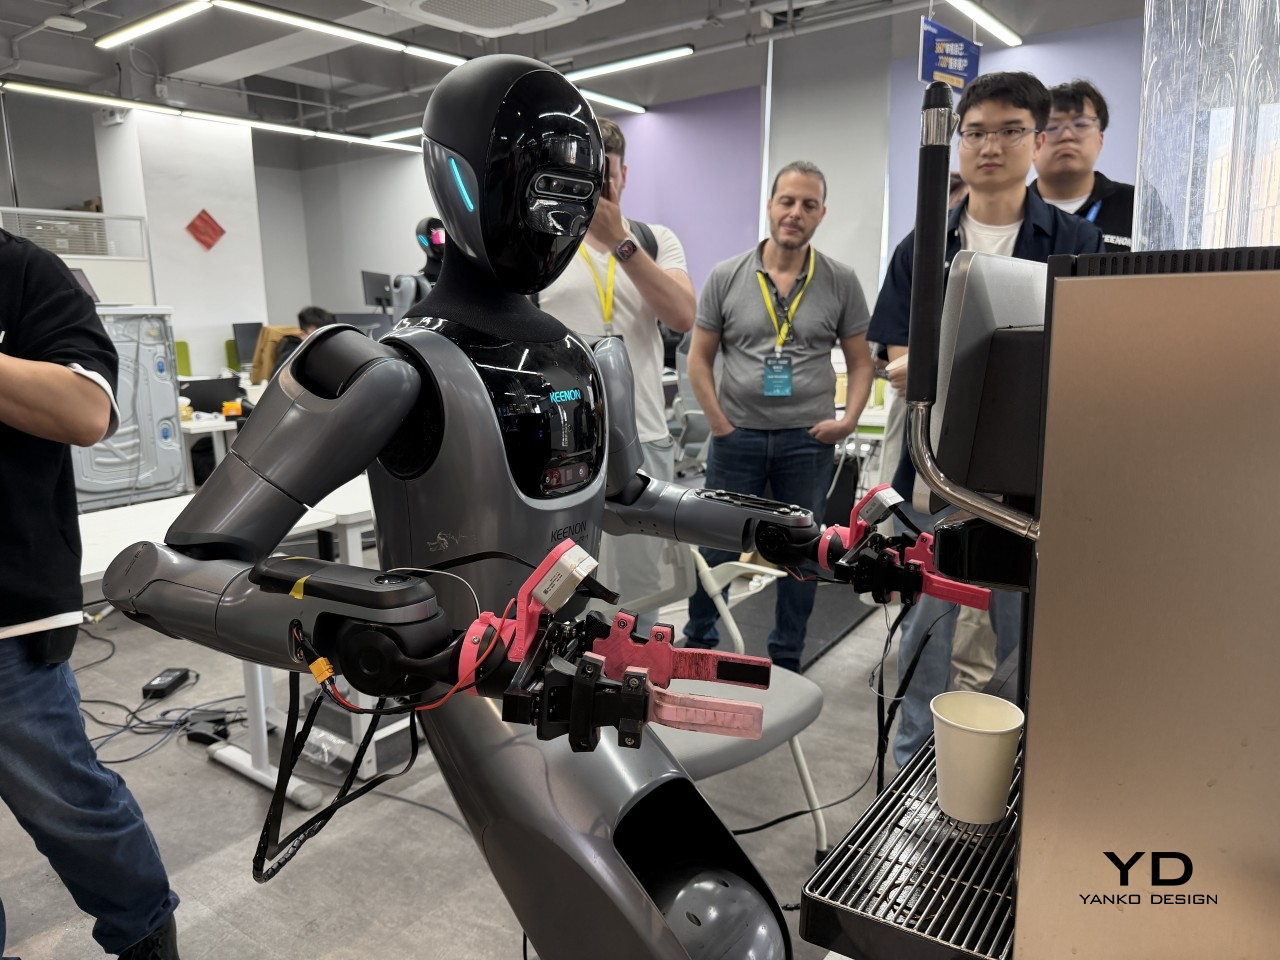
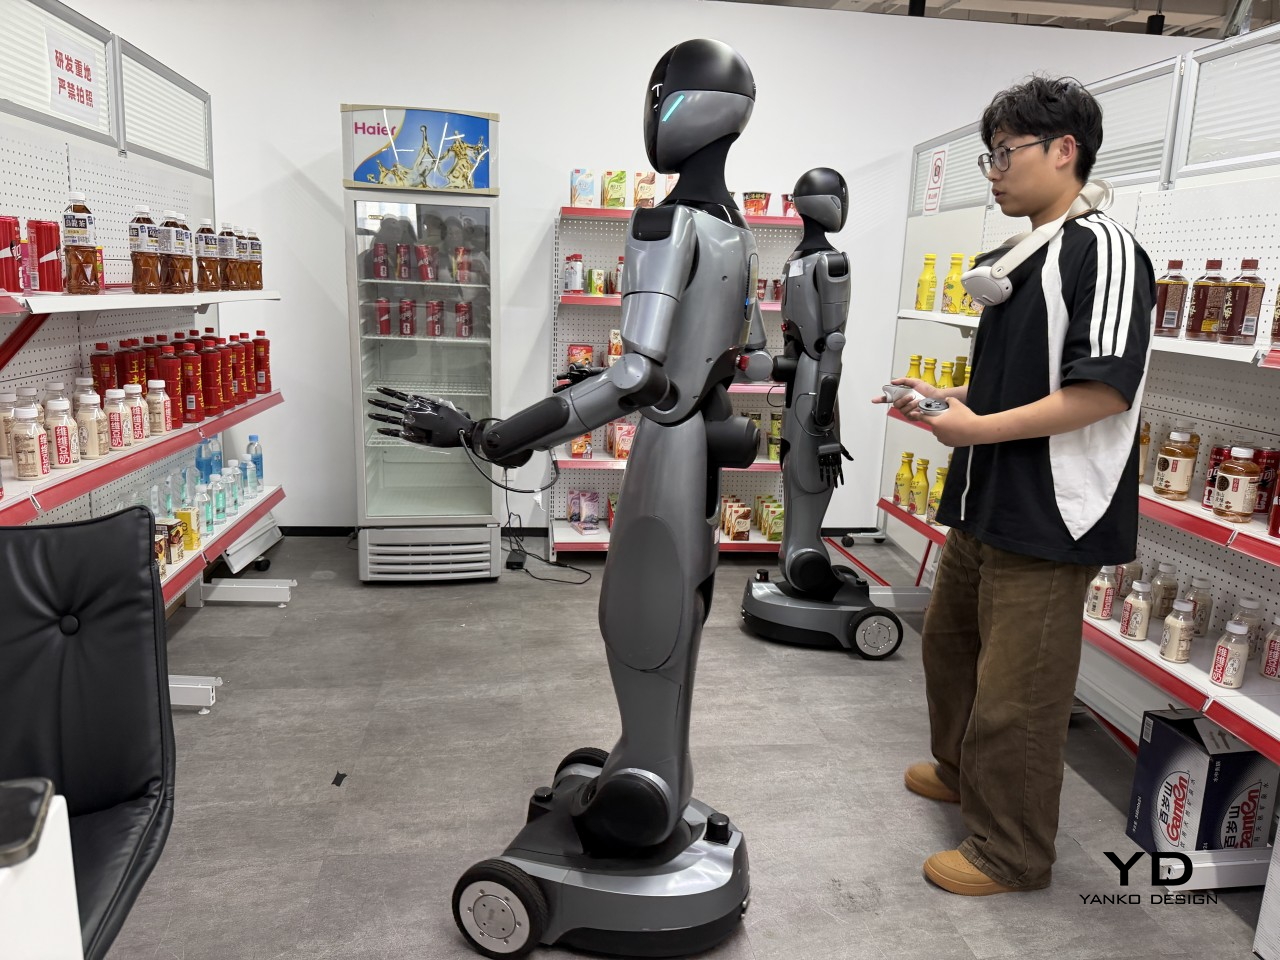
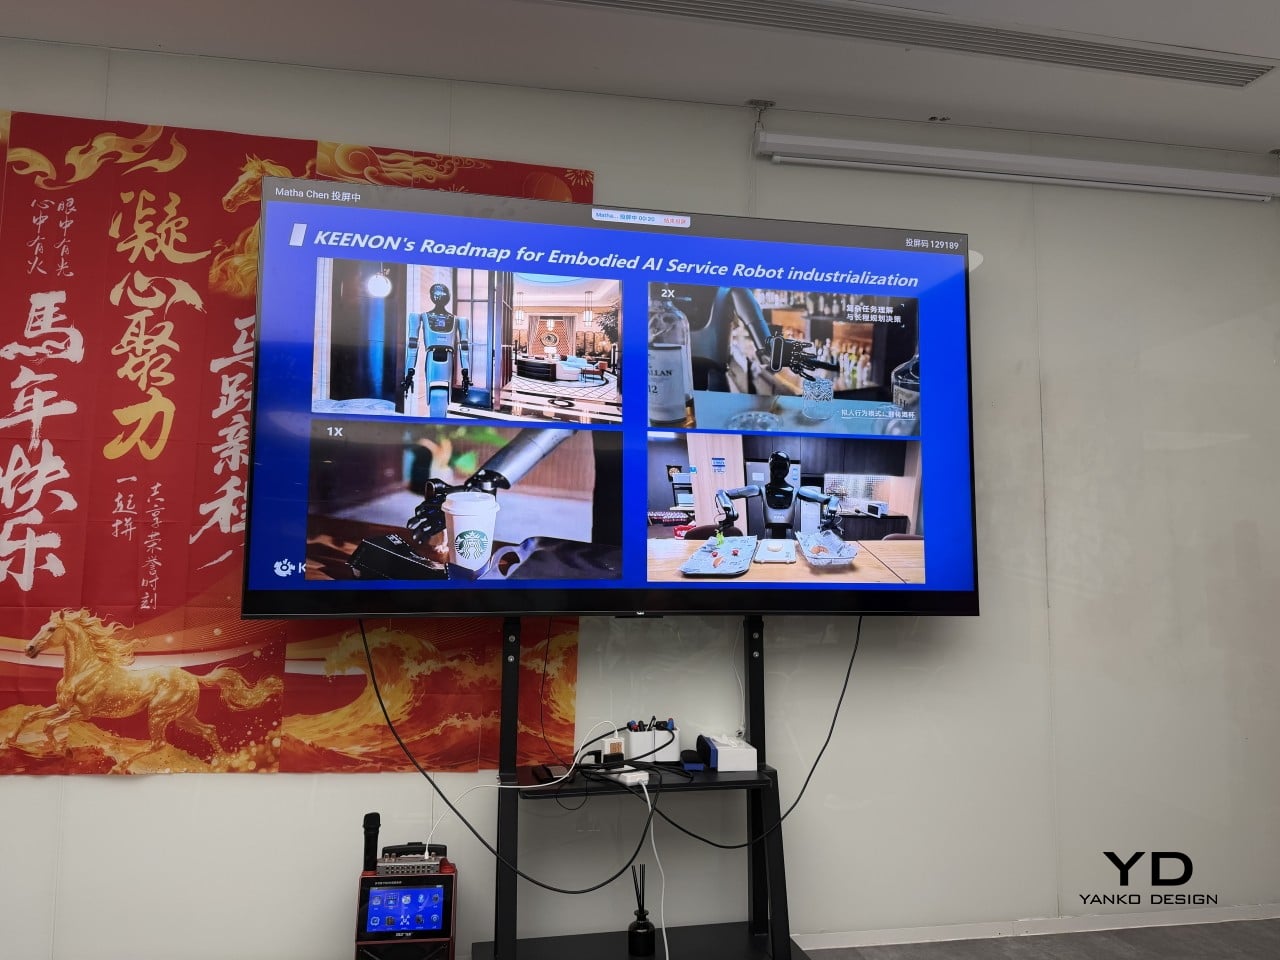
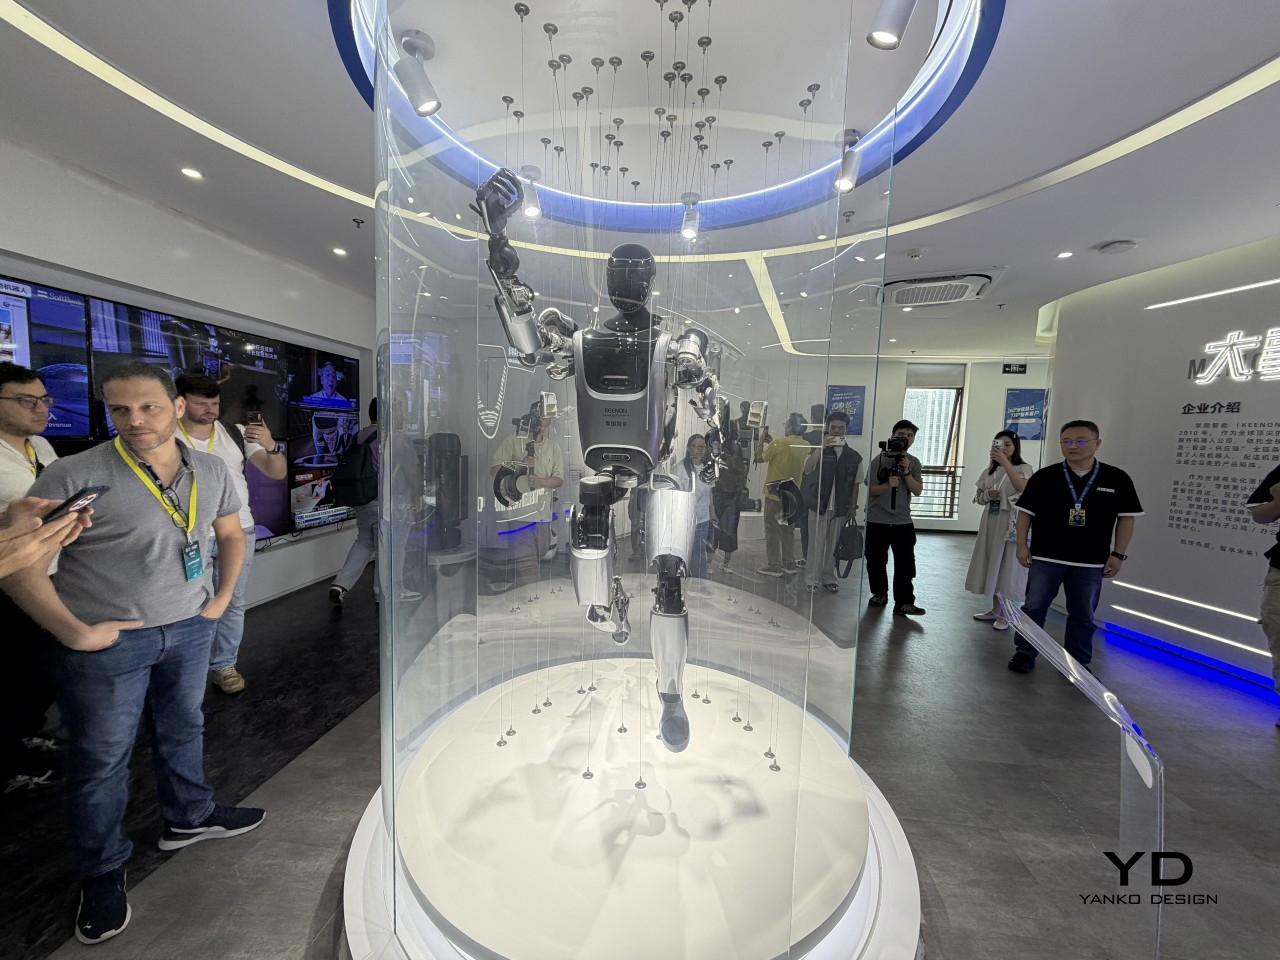
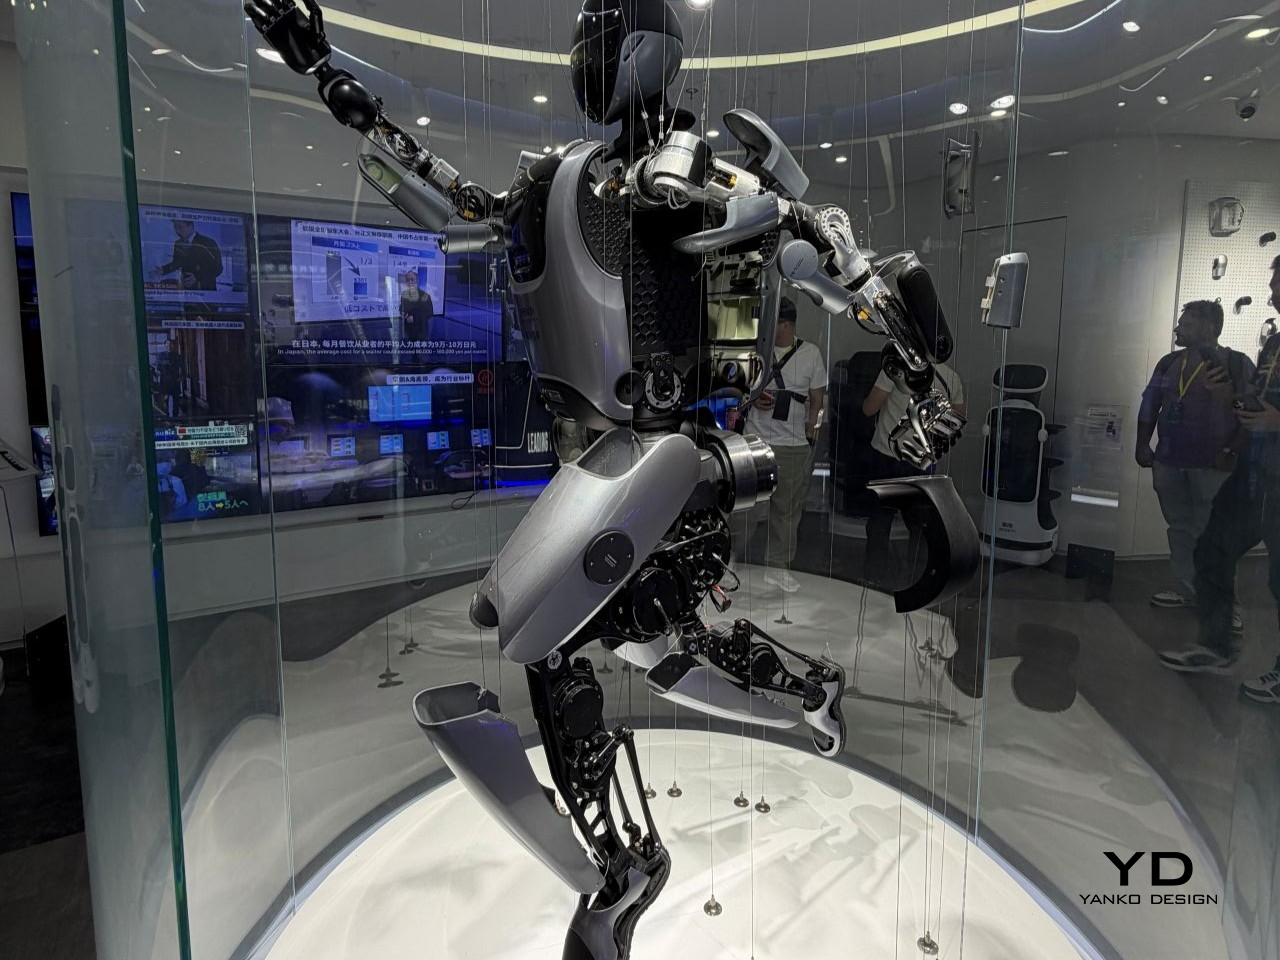
At Global Connect Show 2026, the star of KEENON’s booth was the XMAN-R1, a wheeled humanoid robot that makes popcorn, pours drinks, and hands out snacks. It’s the kind of demo that stops foot traffic, and it’s meant to. Underneath the theatrics, though, is a robot packing 275 TOPS of AI processing power, dual 7-DoF arms, and precision dexterous hands built for human-level manipulation.

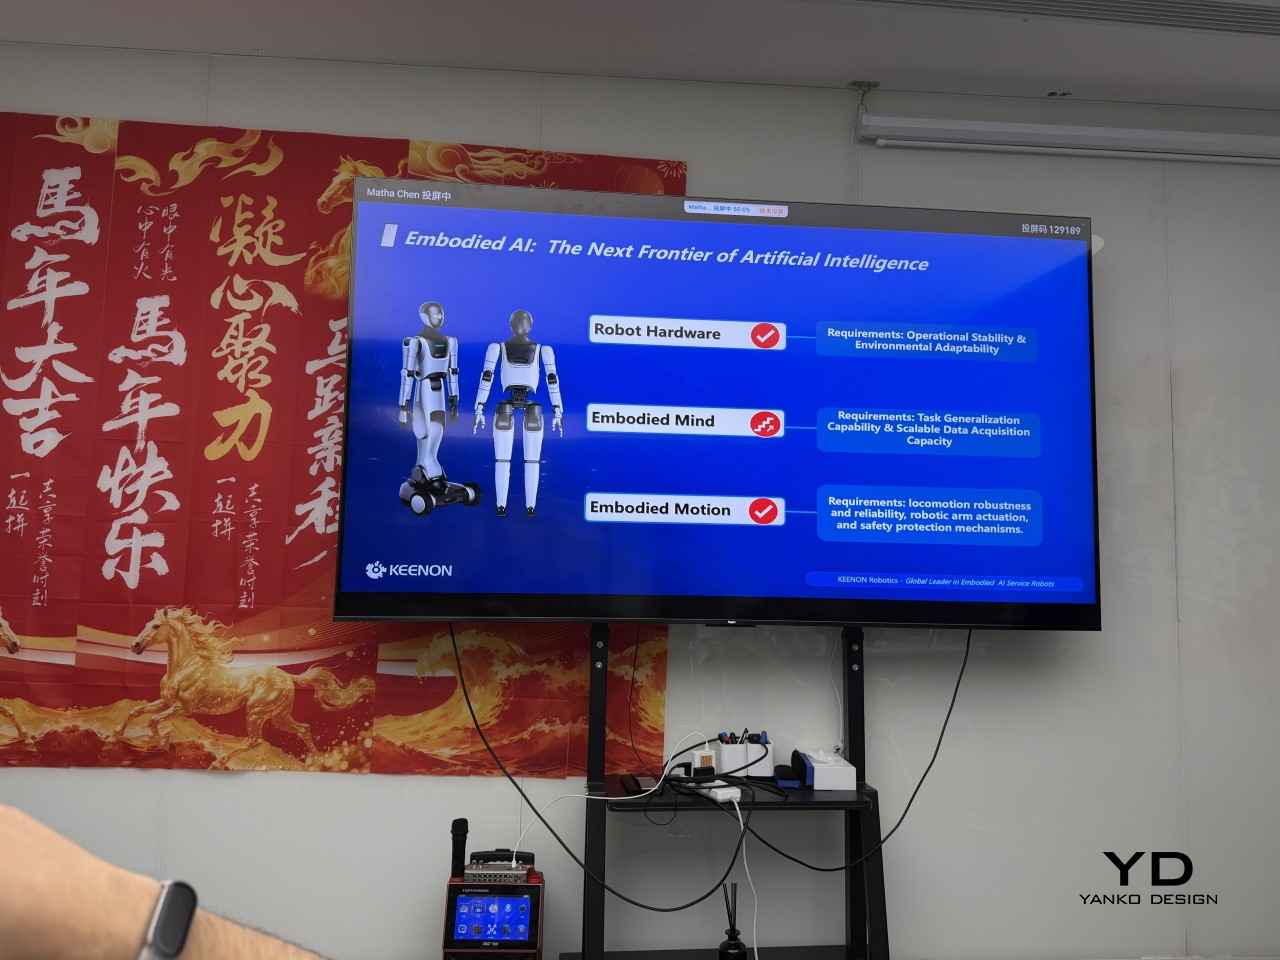
What the demo doesn’t show is how much work went into teaching a robot to grab a cup. KEENON estimates that a single action of that kind requires at least 1,000 data points. A full coffee-making sequence demands over 20,000. That gap between what looks effortless and what it actually costs computationally is one of the clearest explanations of where physical AI sits right now.

KEENON is remarkably candid about this. Their own assessment puts the current “mind age” of humanoid robots at roughly three years old, which, if you think about it, explains a lot about why they move so deliberately. True general-purpose humanoid deployment is still at least five years out by their estimation. The “Model T” framing they use is apt; these are early machines, not finished ones.

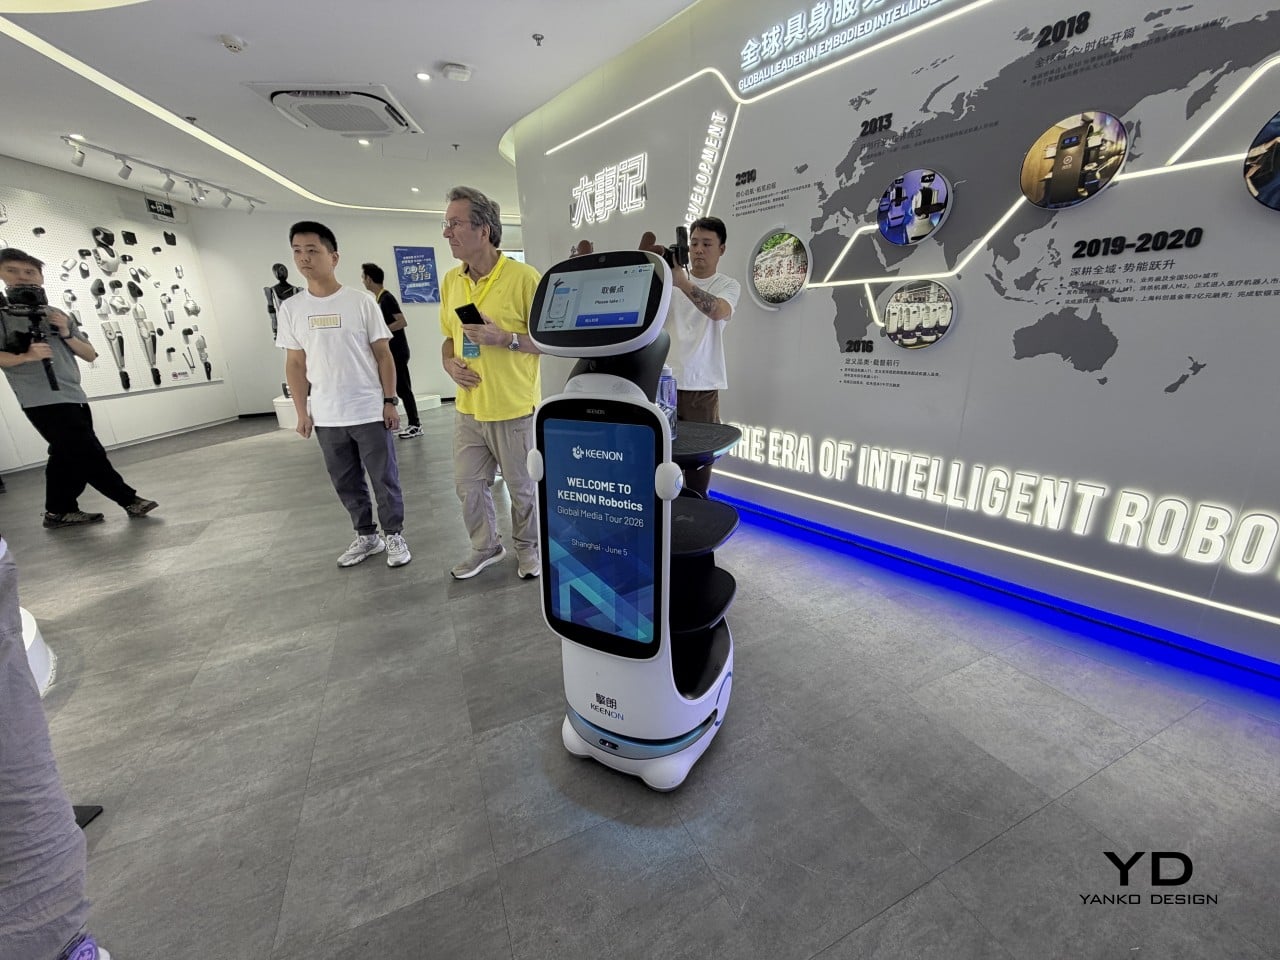
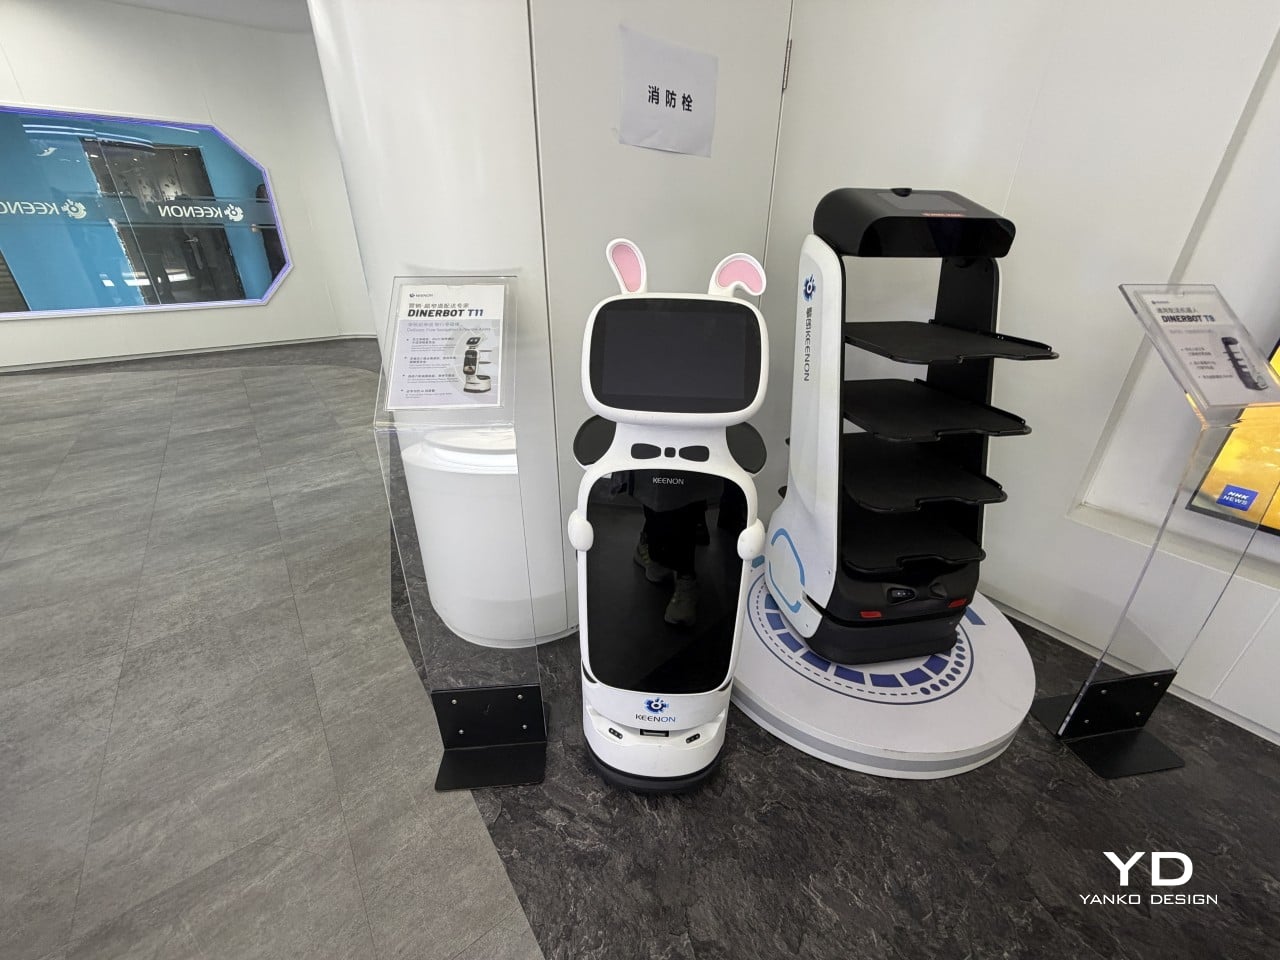
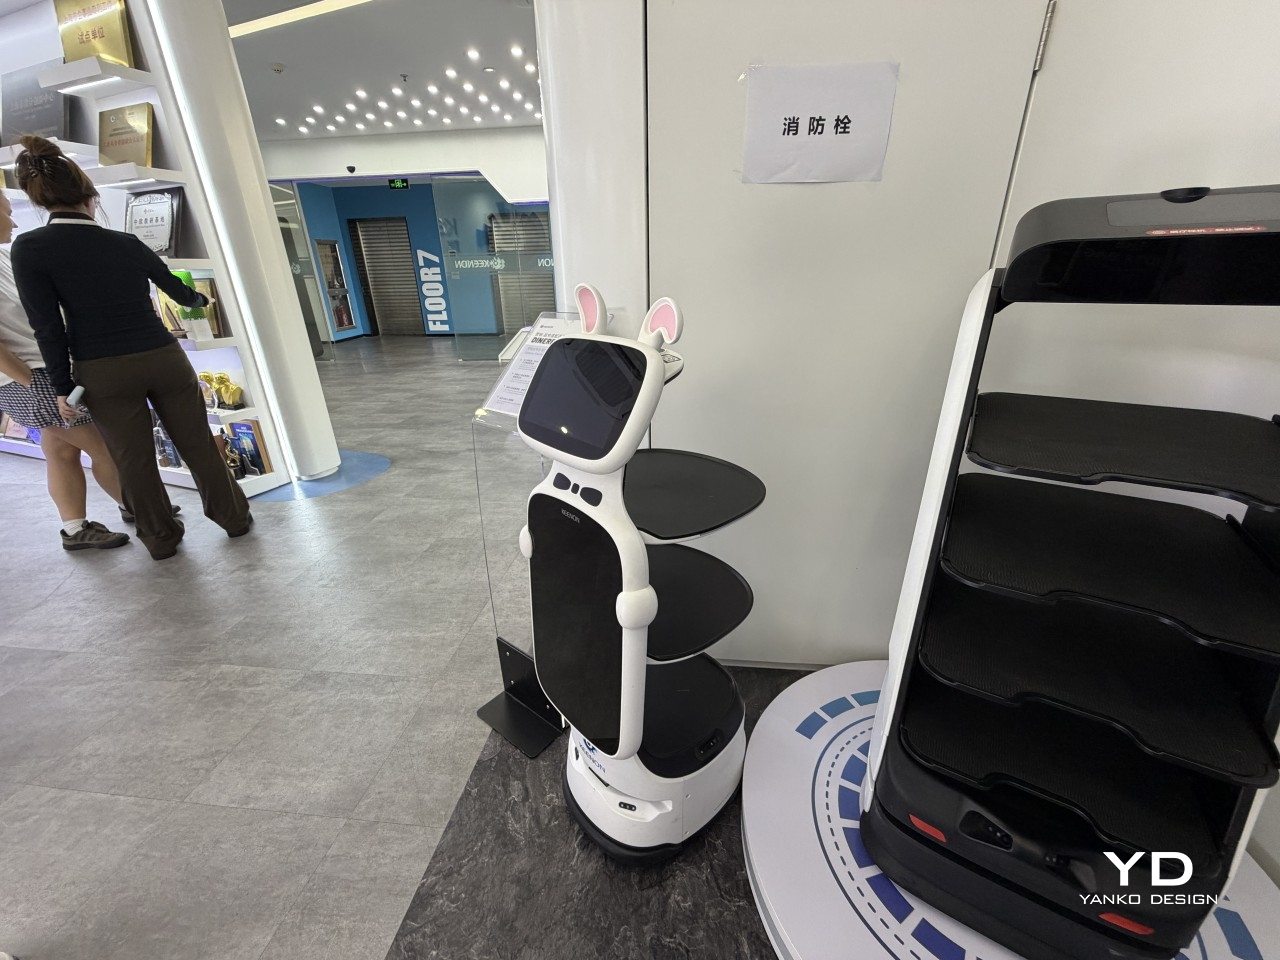
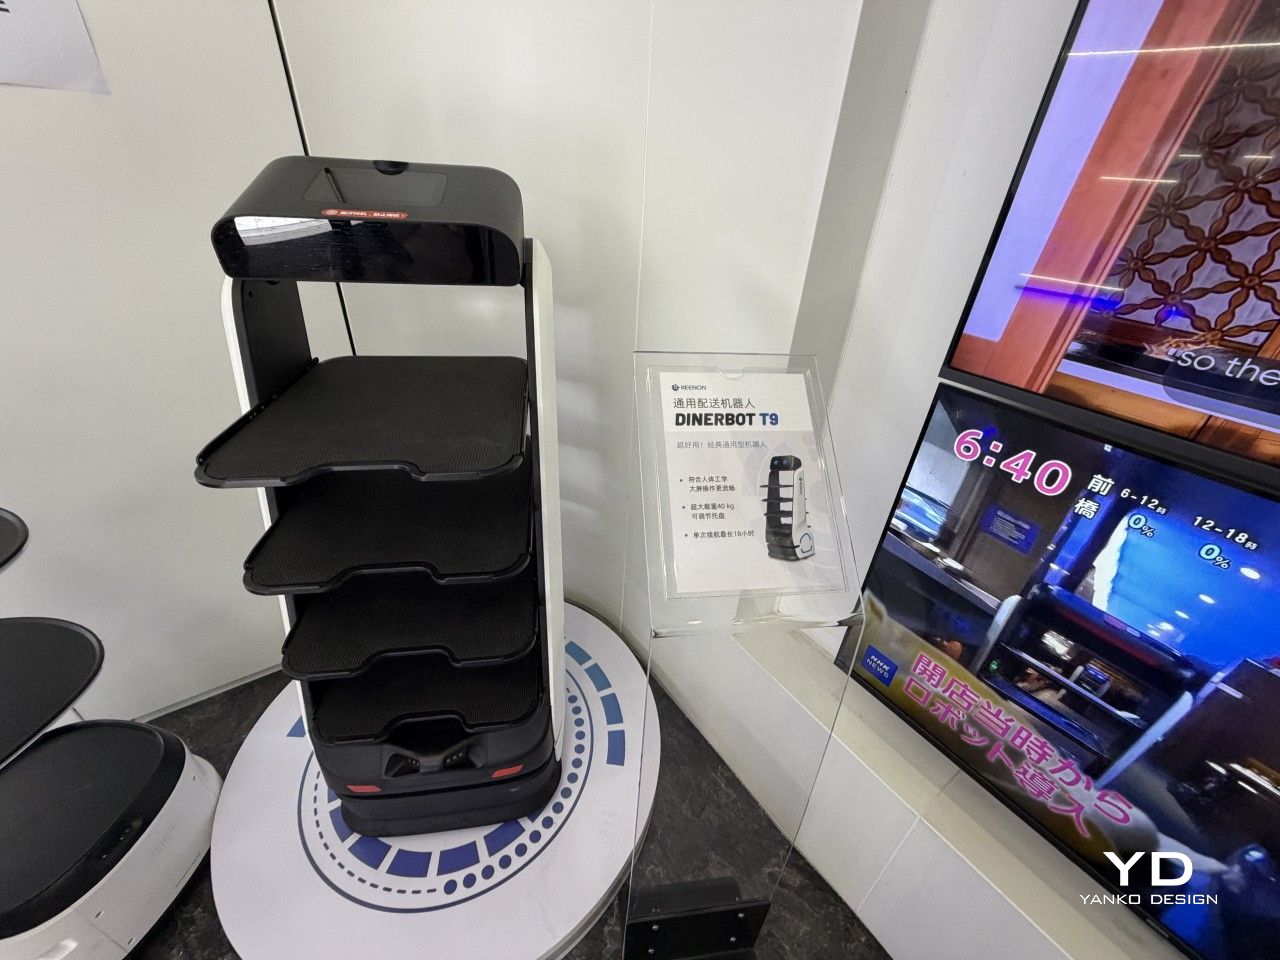
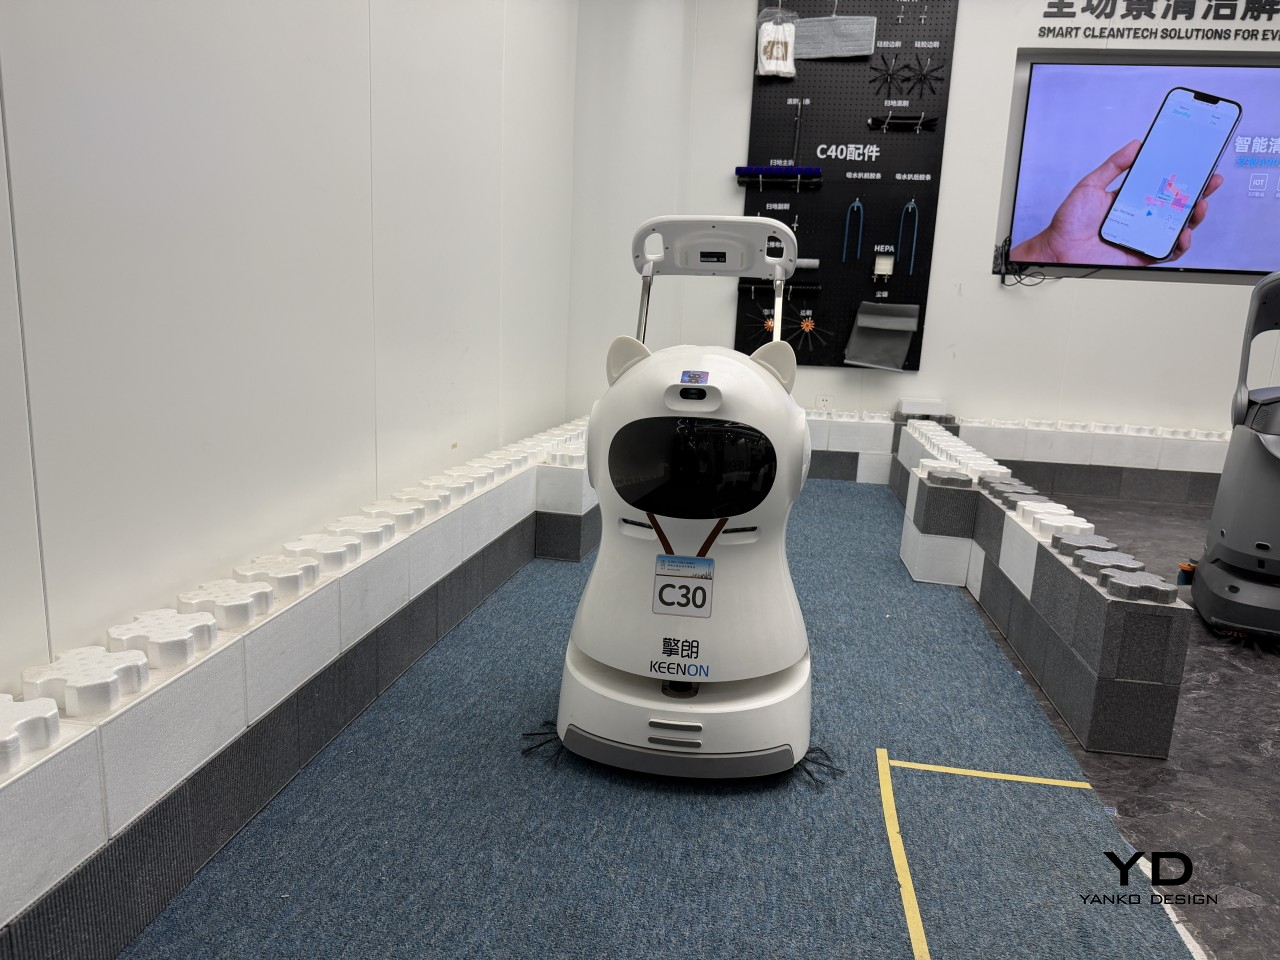
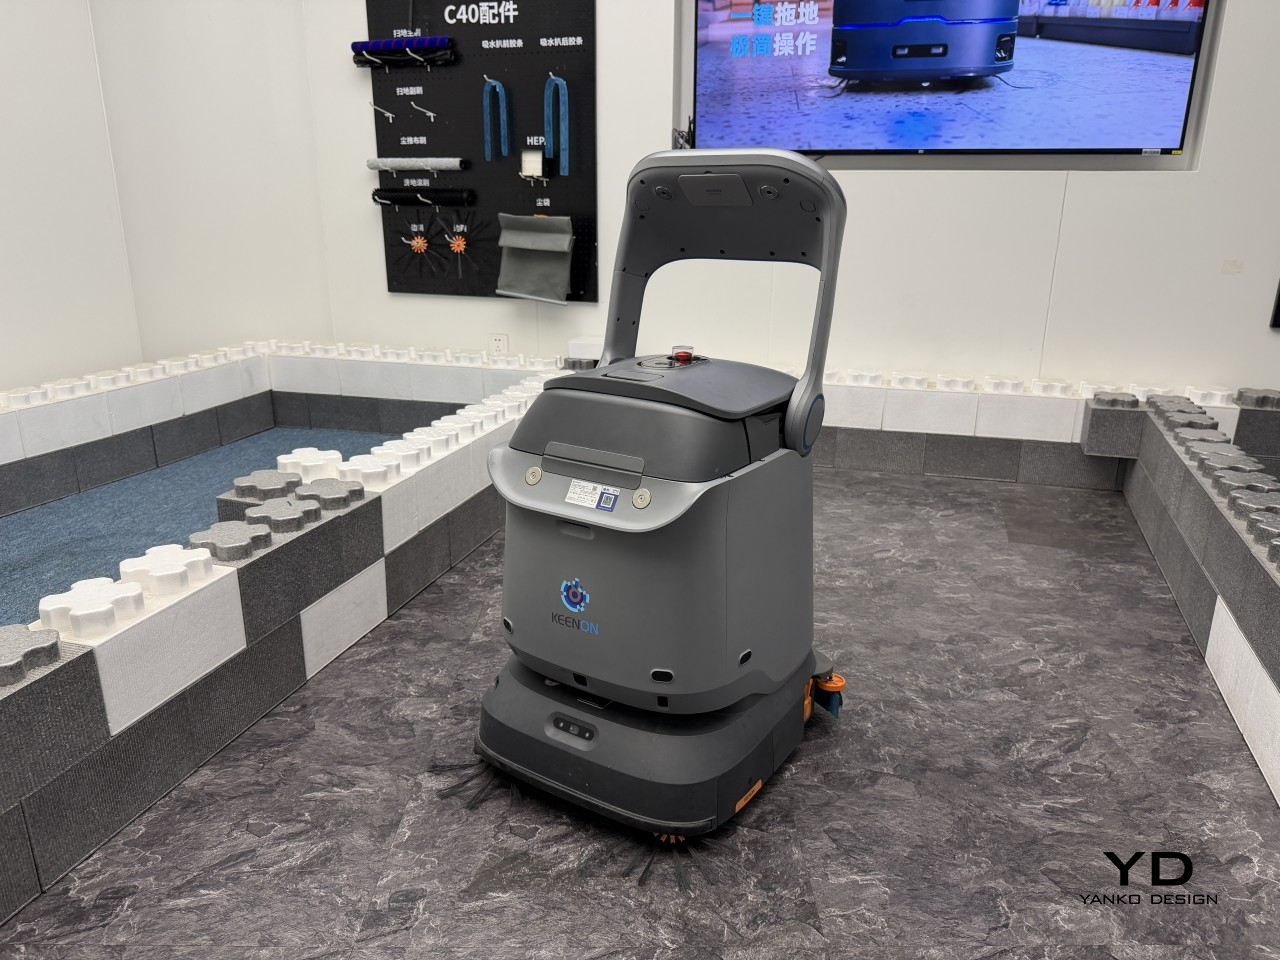
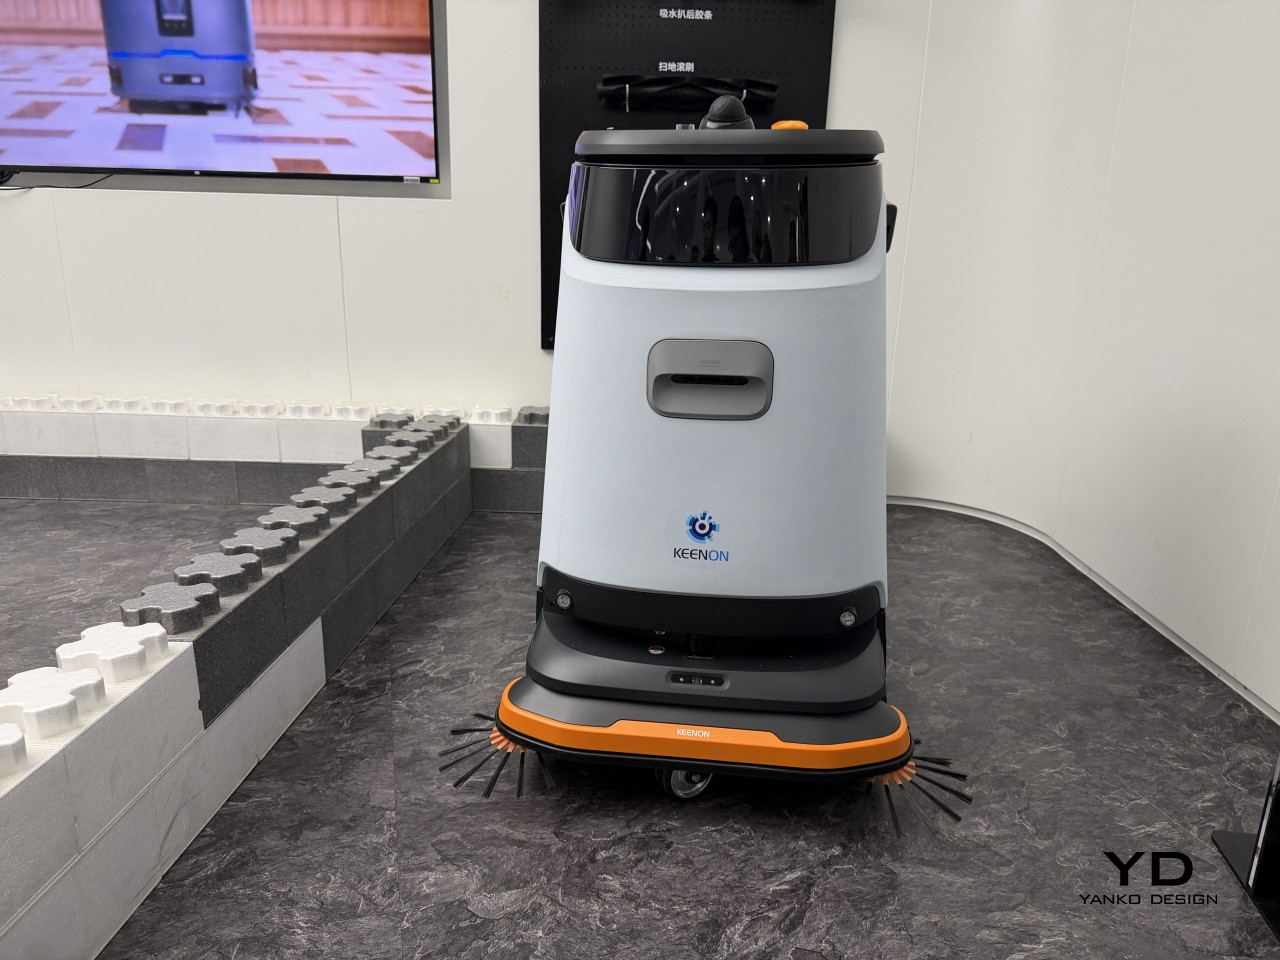
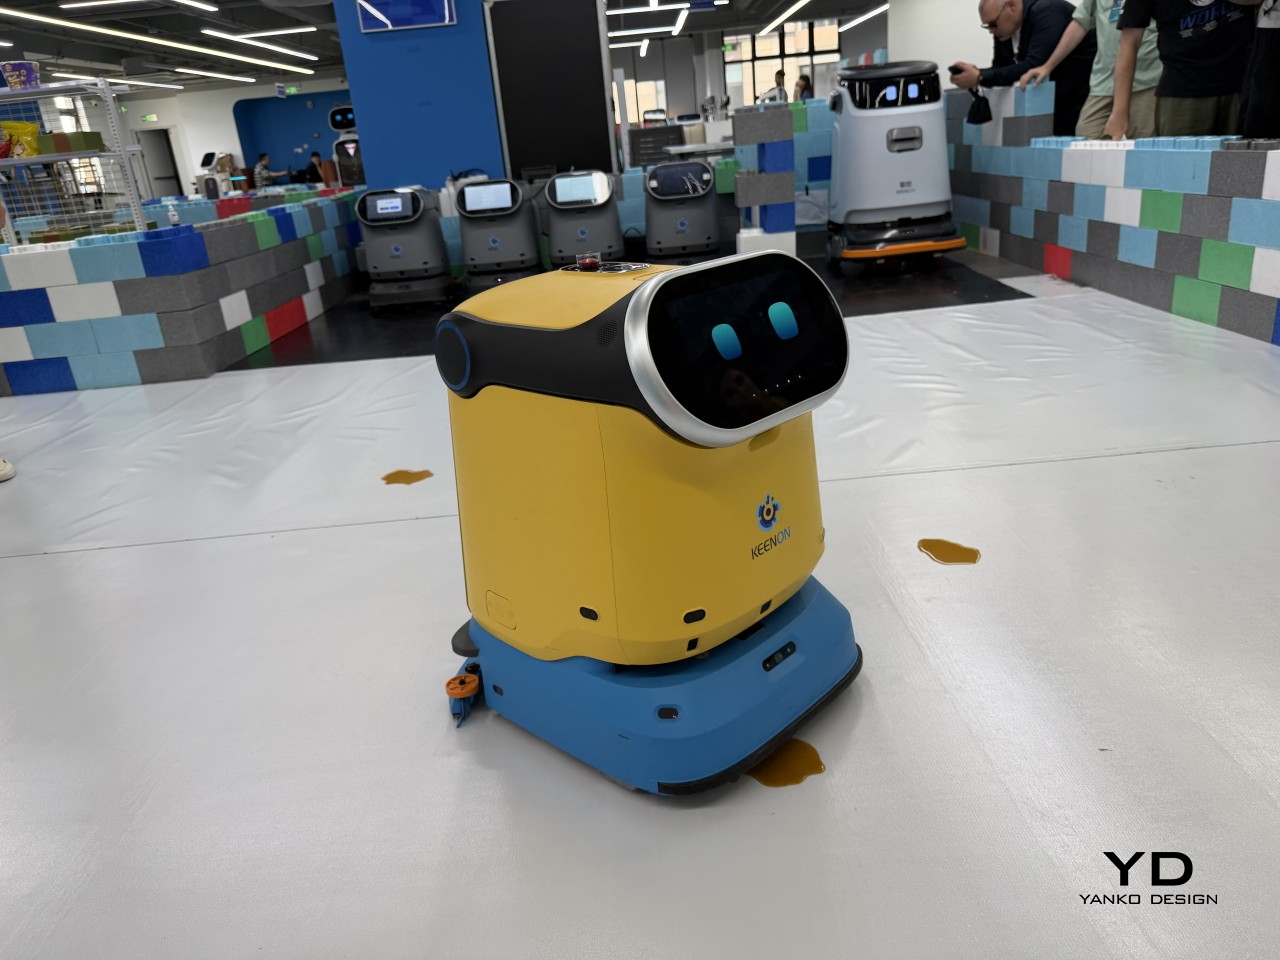
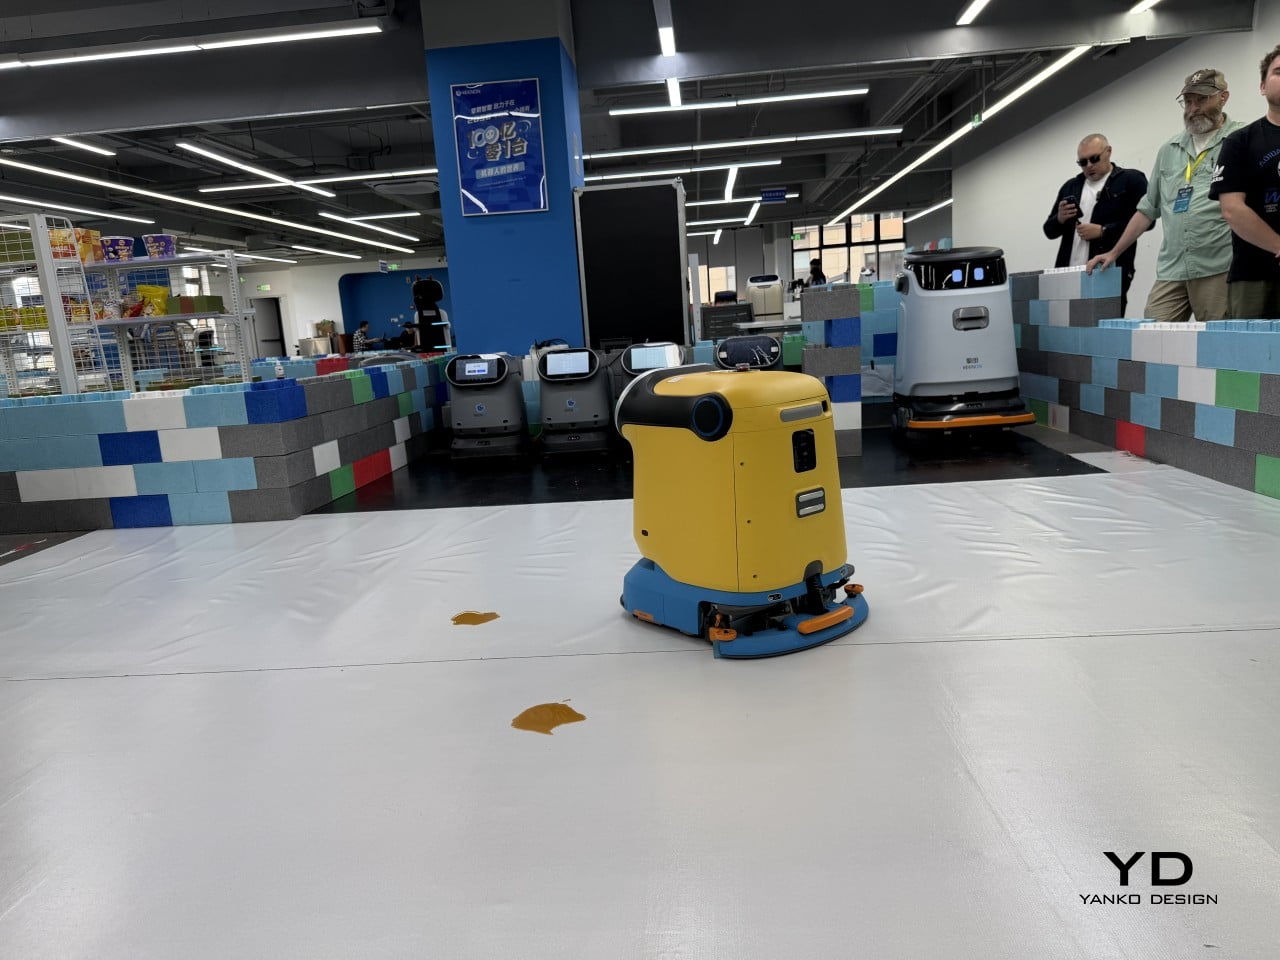
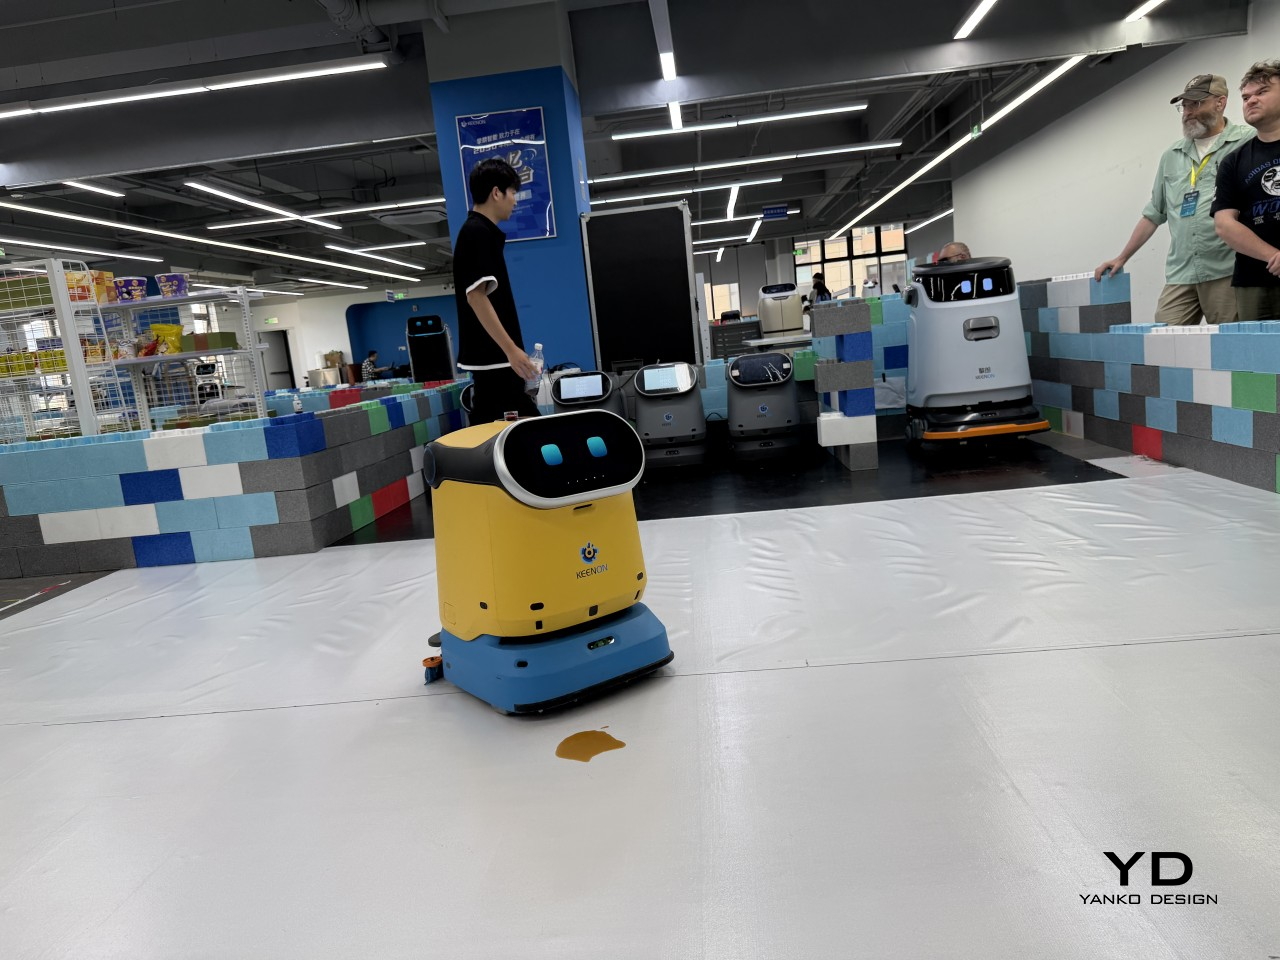
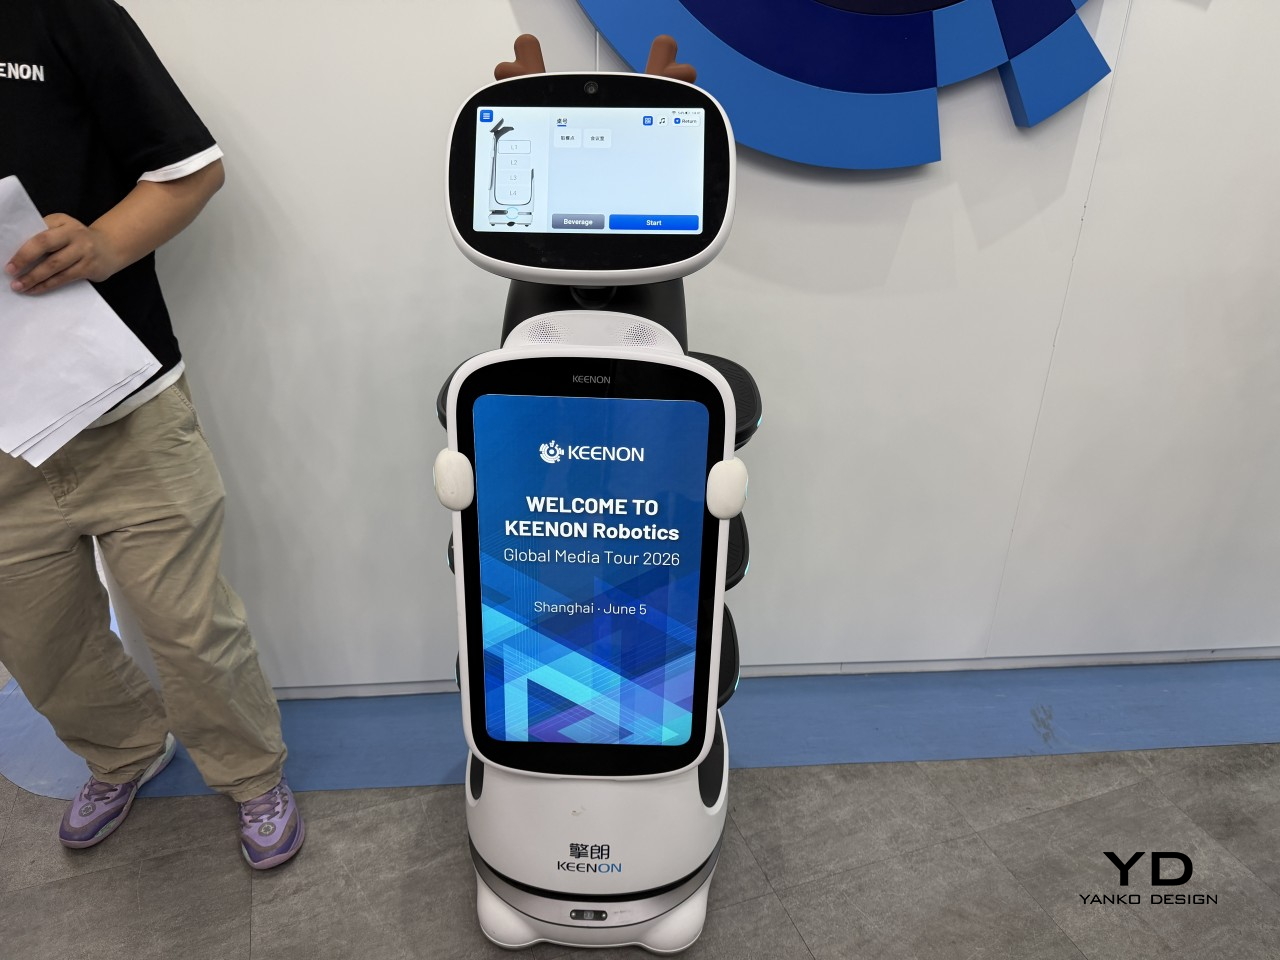
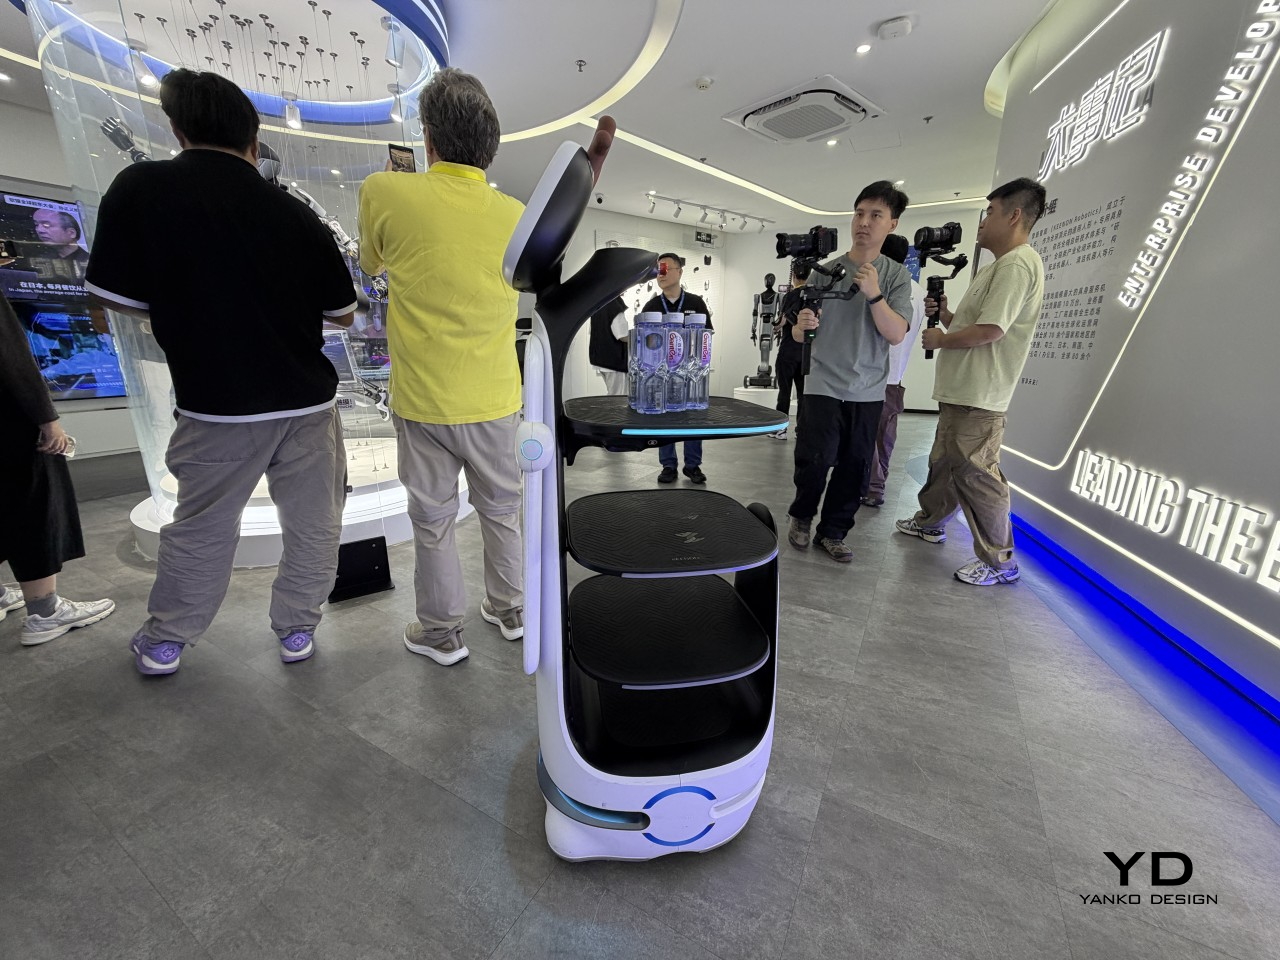
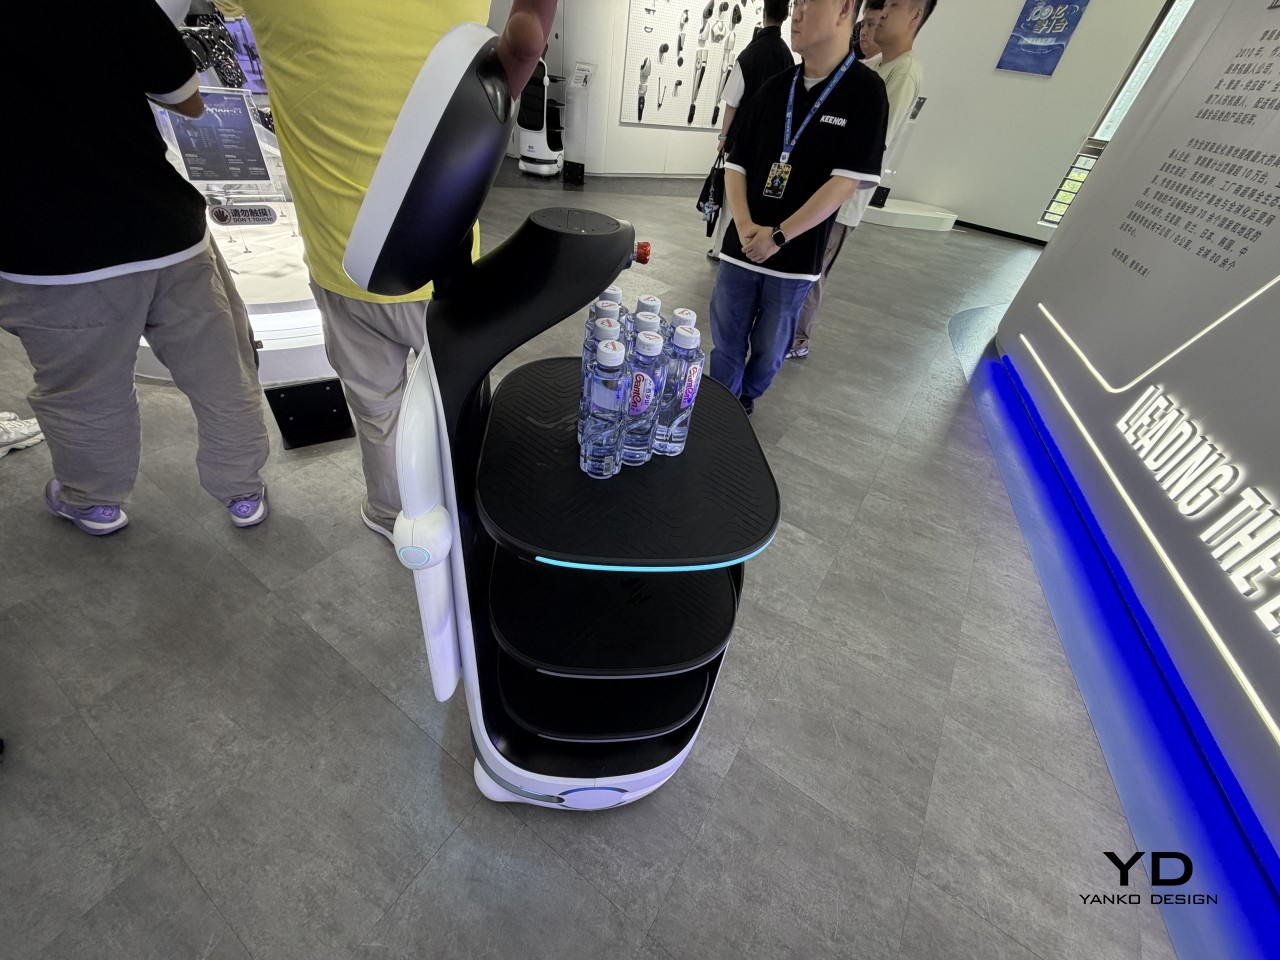
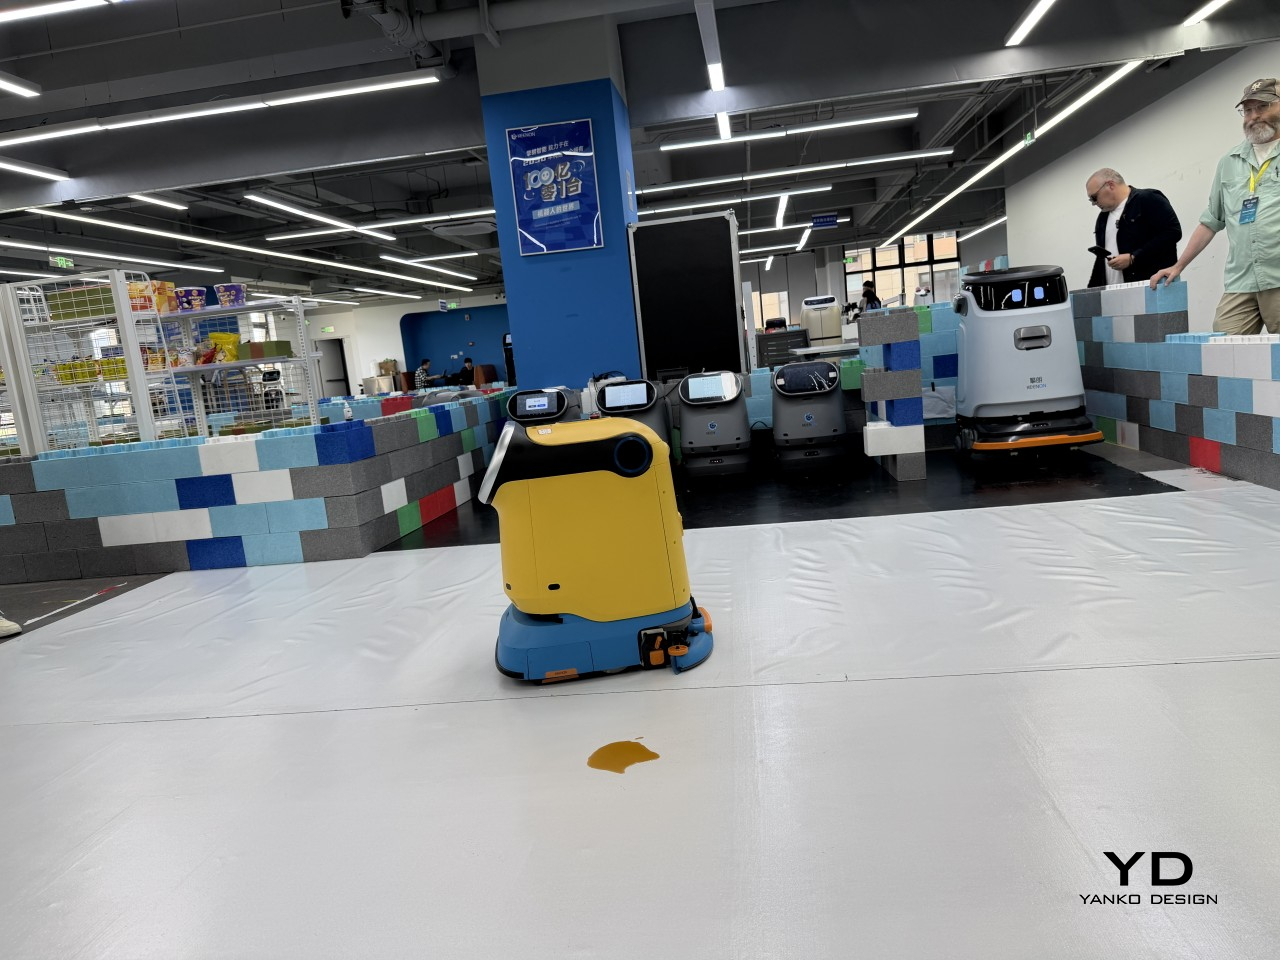
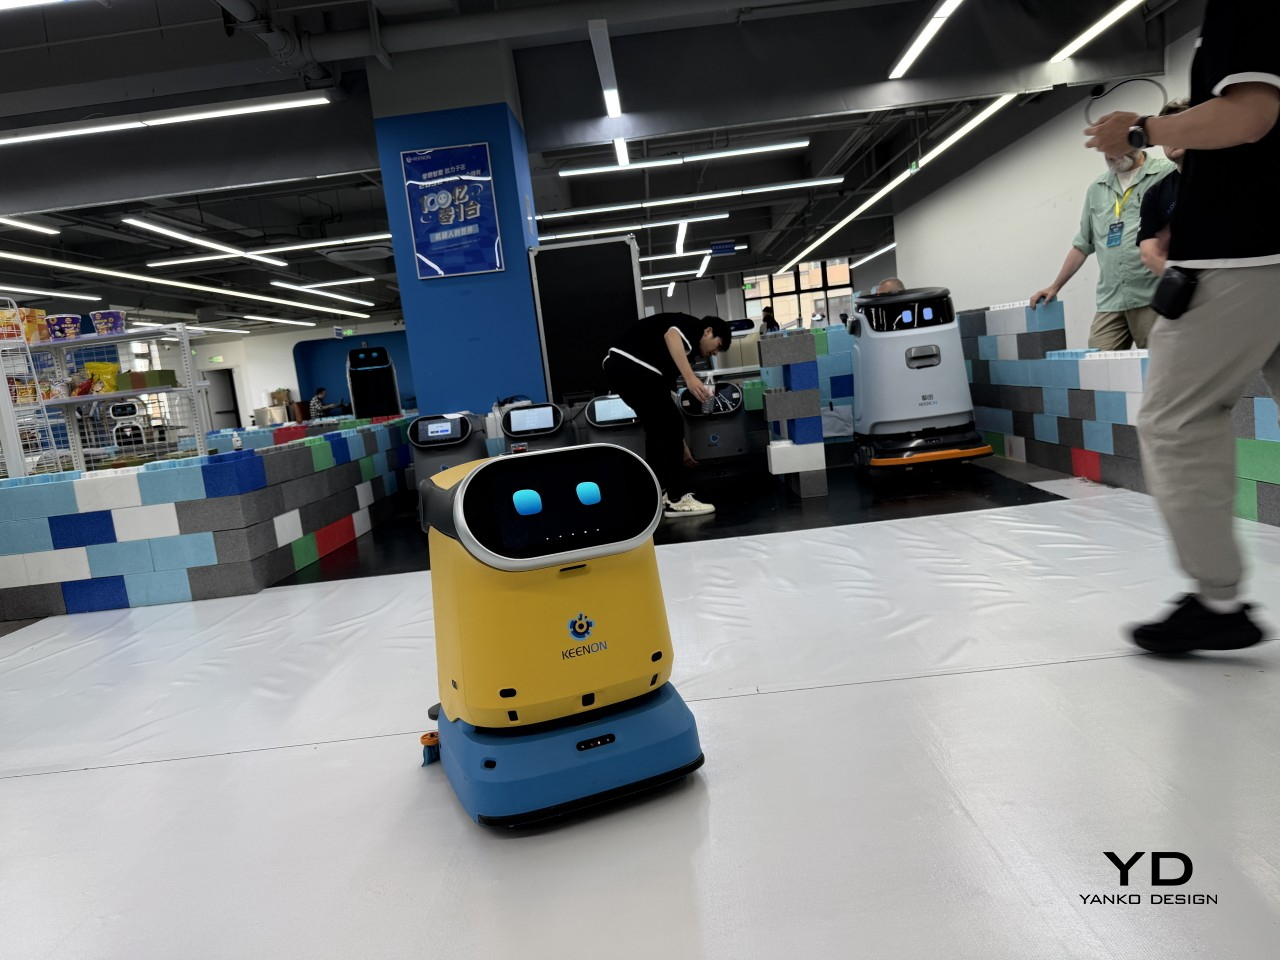
That candor is also what makes KEENON’s established product line feel more credible. While the XMAN-R1 gets the headlines, KEENON’s delivery and cleaning robots have been running inside hotels, restaurants, hospitals, airports, and casinos across more than 600 cities globally. Their DINERBOT T10 can carry up to 40 kg, fits through a 59 cm passage, and operates for up to eight hours on a single charge.

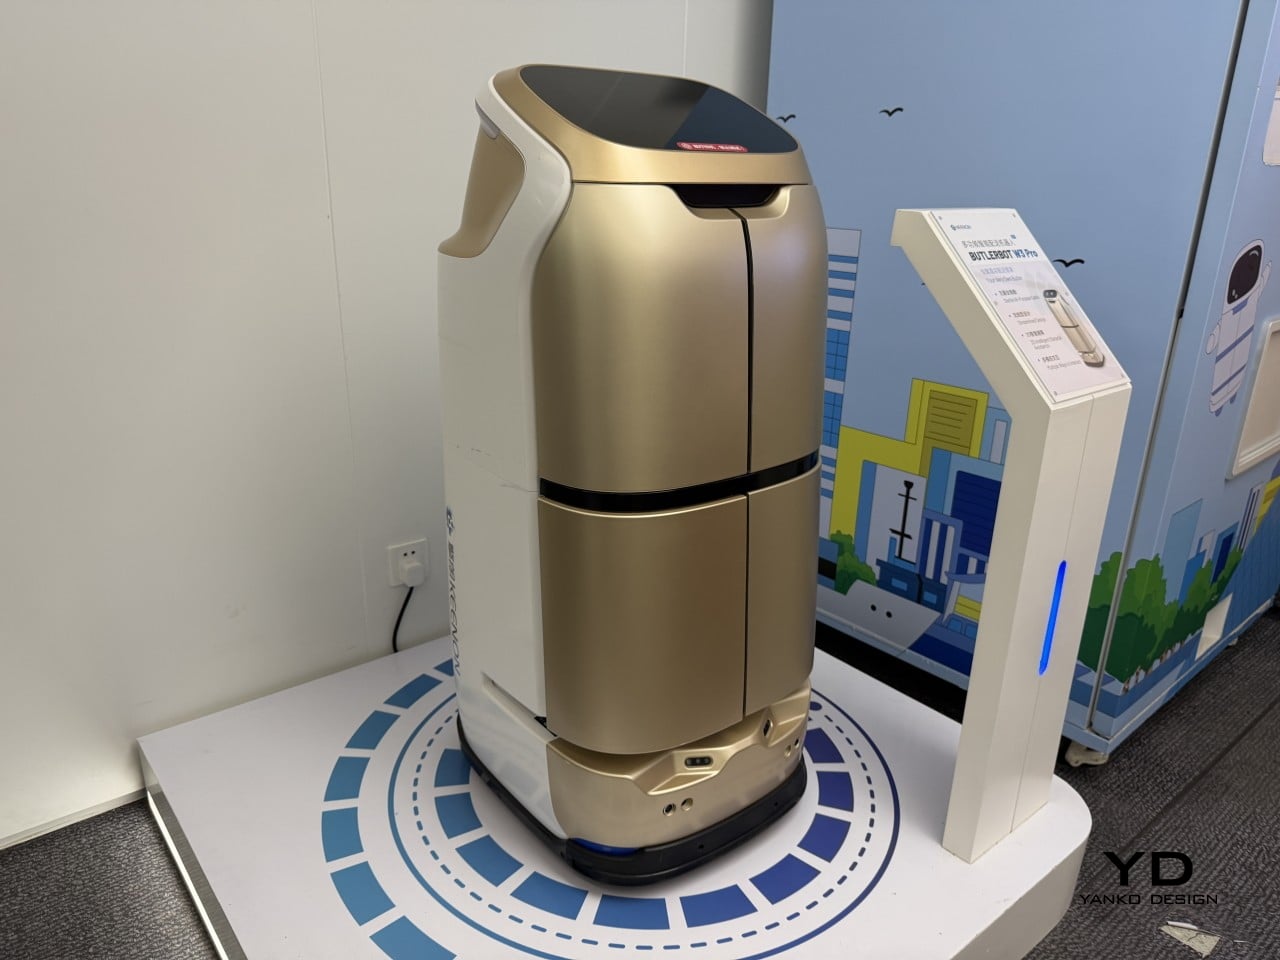
A good example of what that looks like in practice is Shangri-La Hong Kong, where KEENON runs six different robot types across eight units within a single hotel. Delivery bots handle contactless room service; cleaning robots run scheduled cycles through lobbies and corridors; logistics carriers shuttle linens and supplies behind the scenes. None of this required the hotel to restructure its operations around the robots.

Part of why that integration works comes down to a deliberate design choice. KEENON chose not to make its service robots look human. The compact, rounded bodies, soft voices, and animated screen faces are intentional, because how a robot looks determines whether people trust it. Western audiences carry Terminator-shaped anxieties; Asian audiences grew up with characters like Doraemon. The design has to work for both.

The XMAN-R1 at the Global Connect Show is KEENON’s way of signaling where the product line is heading. Alongside it, the company also offers the bipedal XMAN-F1, a full-body humanoid with 43 degrees of freedom that takes the same task-driven approach. Both run on KEENON’s KOM 2.0 platform and are designed to work alongside existing robots like the DINERBOT T10 rather than replace them.

What KEENON actually has over the wave of humanoid startups entering the market is something harder to replicate than a robot body. With 100,000 units running across 70+ countries, the company has been accumulating proprietary operational data at a scale most competitors haven’t even started to approach. Every delivery, every corridor, every cup poured feeds back into that picture, one data point at a time.

The post KEENON Humanoid Pours Drinks at GCS 2026, 100,000 Others Run Hotels first appeared on Yanko Design.
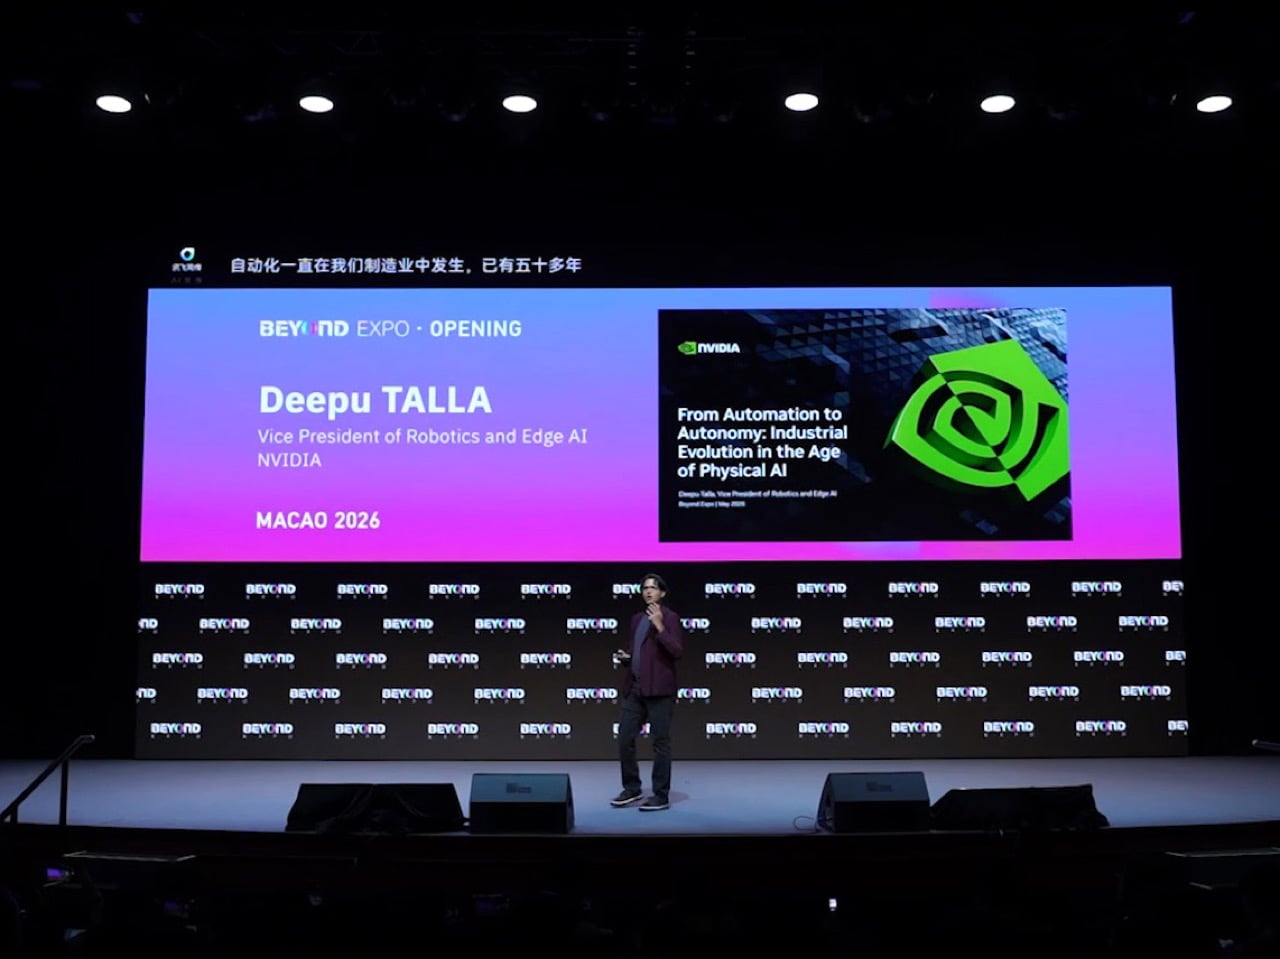
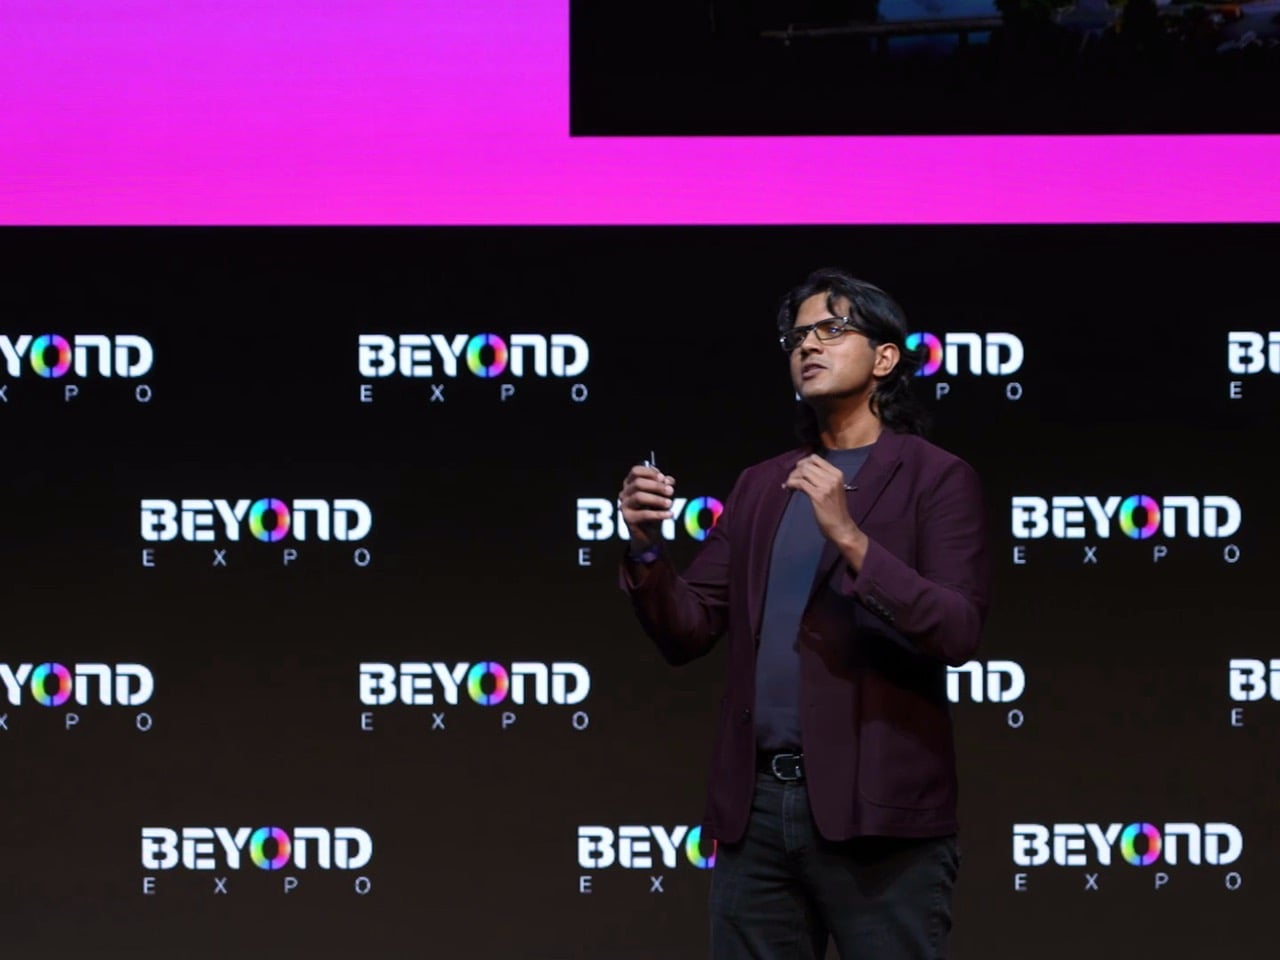
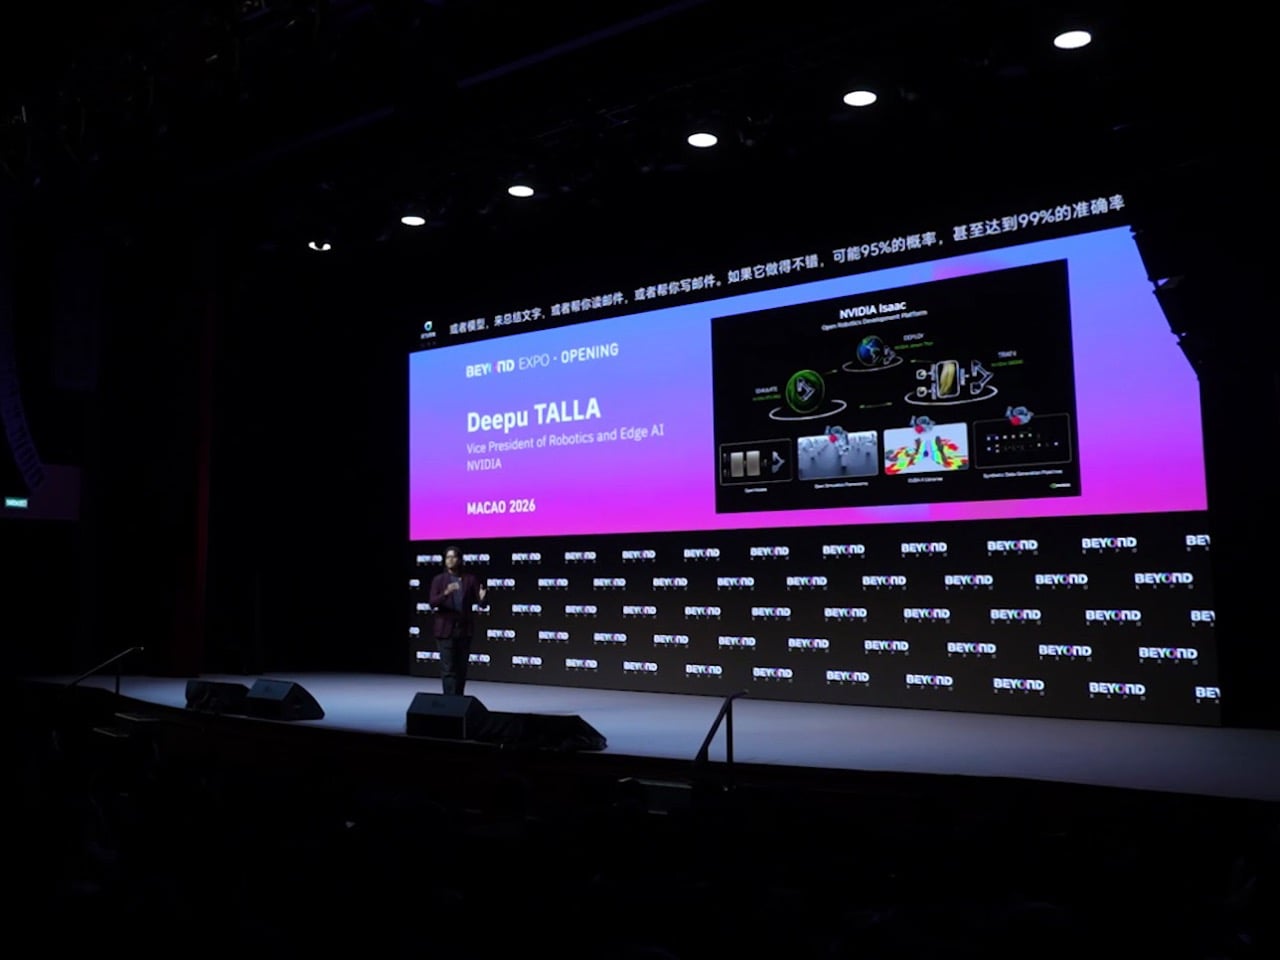
Every Robot You’ll Ever Own Has 3 Separate Brains: Nvidia VP explains how AI Thinks at BEYOND Expo 2026

A robot on a factory floor may look self-contained, but Deepu Talla says its intelligence is distributed across a hidden chain of machines. At BEYOND Expo 2026, the NVIDIA executive broke robotics down into a deceptively simple formula: three computers. One handles the heavy lifting of training the robot brain, another tests that brain in simulation, and a third lives inside the physical robot, making decisions in real time.

It is a framework that helps explain why robotics has moved so slowly, and why the field suddenly feels ready to accelerate. In language that cut through the usual keynote fog, Talla argued that AI in the physical world plays by harsher rules than chatbots or image tools. A text model can be 95 percent right and still be useful. A robot moving through a warehouse, a street, or a hospital has to perform with a completely different standard. In human terms, it is a little like splitting intelligence into learning, dreaming, and reacting, then assigning each function to a different machine.

That first machine is where the robot’s intelligence is forged. Talla described it as the computer used to train the robot brain, the heavy compute layer where models absorb data, patterns, and behaviors at massive scale. This is where a machine learns how the physical world works, long before it ever enters one. If that sounds abstract, the second computer makes it easier to picture. This is the simulation layer, the place where a robot rehearses reality in a safer, faster, cheaper environment, running through scenarios again and again until its behavior becomes reliable enough to trust.

The third computer is the one that actually lives inside the robot. It is the real-time brain, the system that has to perceive the world, make sense of it, and respond instantly. This is where Talla’s argument becomes especially sharp. In digital AI, a model can get close and still be useful because a human can smooth over the rough edges. In robotics, the rough edges are where accidents happen. A machine moving through a factory, a roadway, or a hospital has to work with a far tighter tolerance for error, because the physical world offers fewer second chances.

That is also why NVIDIA sees robotics as far bigger than a niche category. Talla pointed out that almost 80 percent of the world’s GDP sits in physical industries like manufacturing, logistics, retail, and transportation. These are sectors where intelligence has to leave the screen and interact with objects, spaces, and people. NVIDIA’s role, in his telling, is to provide the underlying architecture for that shift. The company may not build robots itself, but it wants to supply the stack beneath them, from training infrastructure and simulation tools to the compute that powers action on the edge.

The post Every Robot You’ll Ever Own Has 3 Separate Brains: Nvidia VP explains how AI Thinks at BEYOND Expo 2026 first appeared on Yanko Design.
FutureWave’s Furny home robot talks to you by moving, not by talking

Most home robots ask a lot from the room they inhabit. They arrive with screens, speakers, wake words, and personalities, all requiring acknowledgment from whoever happens to be nearby. The interaction model is fundamentally borrowed from smartphones: alerts, prompts, and responses delivered through layers of interface. The result is a machine that demands attention in a space that already has more than enough competition for it.

Brussels-based studio Futurewave took a different position with Furny, a domestic robot concept presented at the last Milan Design Week 2026. Rather than building something with a face, a voice, and a screen, the team asked whether a robot in the home could communicate through posture and movement alone, the way furniture communicates presence and purpose without saying anything at all.

Designer: Futurewave

The answer is a furniture-sized object with a movable head that expresses itself entirely through physical behavior. When something happens nearby, the head tilts. When the robot is ready to act, it orients toward the task. When it’s waiting, it recedes into a posture that reads as neutral, almost still. The timing, direction, and intensity of each shift are calibrated to communicate specific states: focus, readiness, attention, and reaction. There are no pixels involved in any of it.

Deliberately avoiding humanoid proportions was a foundational decision. Furny doesn’t mimic the way a person or animal moves. The gestures it uses are abstract enough to feel designed rather than imitated, which makes them easier to read in context without triggering the uncanny valley that tends to follow robots built on biological templates. The visual restraint also helps it belong in a room. It reads as an object with behavior, rather than a character out of place.

The research behind the project draws on work in expressive movement design for non-anthropomorphic robots, a field that looks at how physical states and intentions can be conveyed through spatial behavior without resorting to screens or voice. Furny’s head doesn’t speak for it. The way the body holds itself does. The robot signals what it’s about to do before it does it, which is a meaningful distinction from machines that simply act and leave the explanation for an app notification afterward.

Futurewave also built Furny within a manufacturable framework, which separates it from most conceptual robot work. The project integrates industrial design, embedded electronics, and software-controlled motion systems in a way that points toward practical production rather than exhibition only. That framing is important because the most interesting thing about Furny isn’t the movement vocabulary itself but the argument it makes about what a domestic robot is supposed to be.

The prevailing assumption has been that robots become more useful as they become more capable of mimicking human interaction. Furny pushes back on that. A robot that remains quiet when nothing’s needed, reads the room through its posture, and signals intention before acting doesn’t interrupt the household. It becomes part of it, the way a good piece of furniture does, present and purposeful without drawing attention to itself until the moment calls for it.

The post FutureWave’s Furny home robot talks to you by moving, not by talking first appeared on Yanko Design.
Argus Just Showed Up With 20 Eyes, 20 Legs, and No Rules

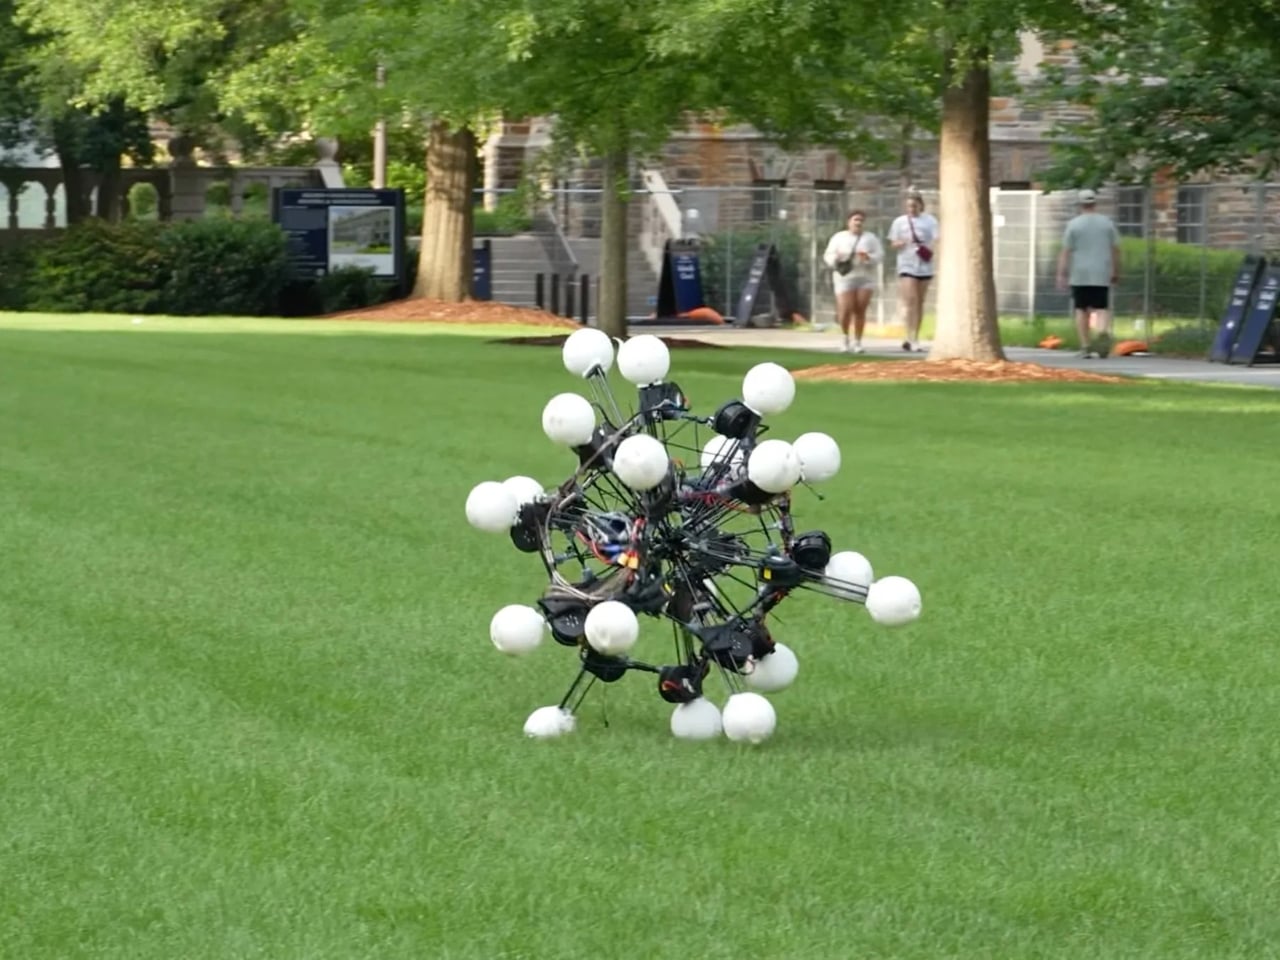
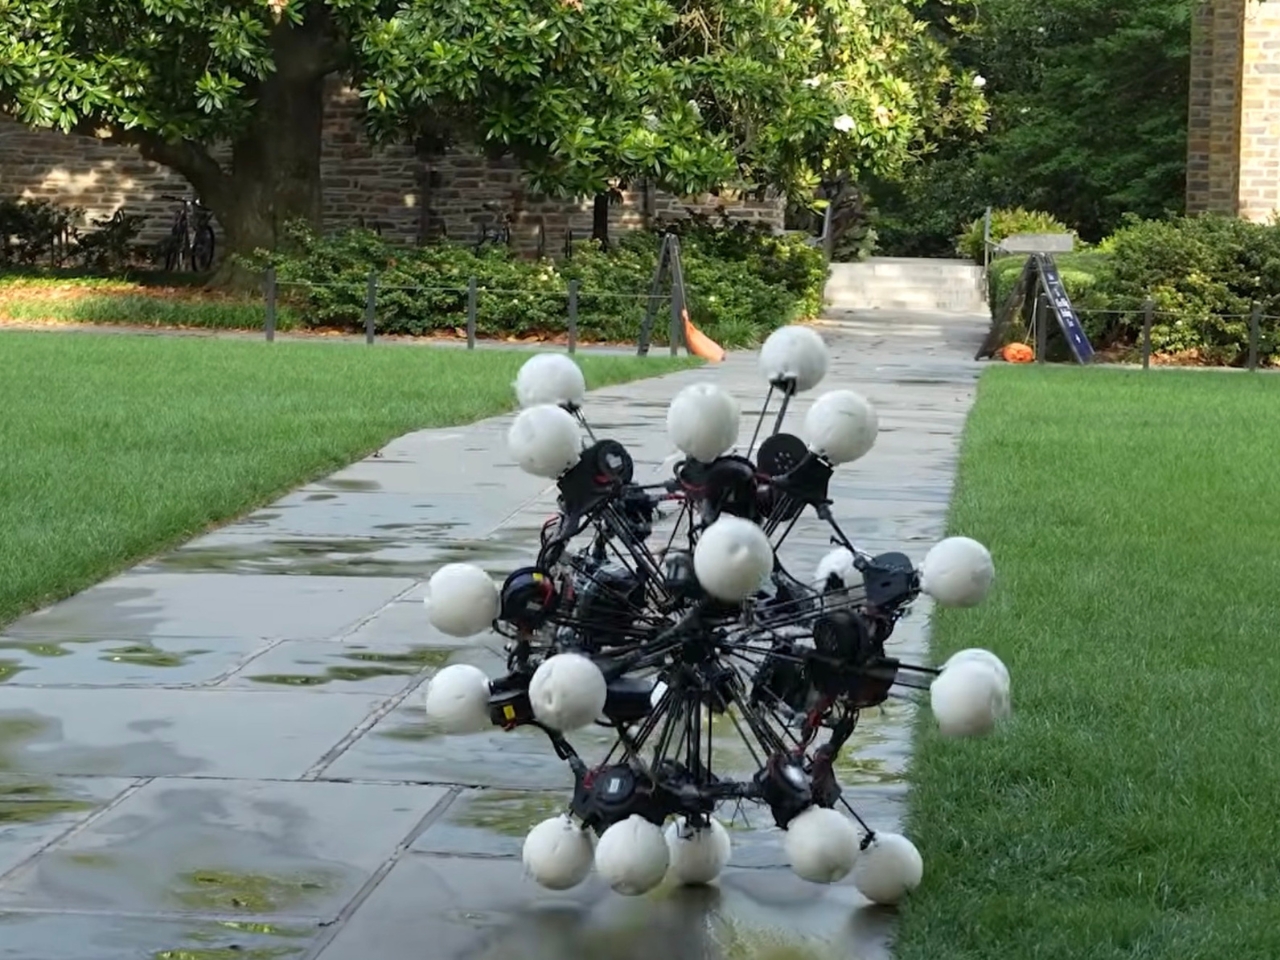
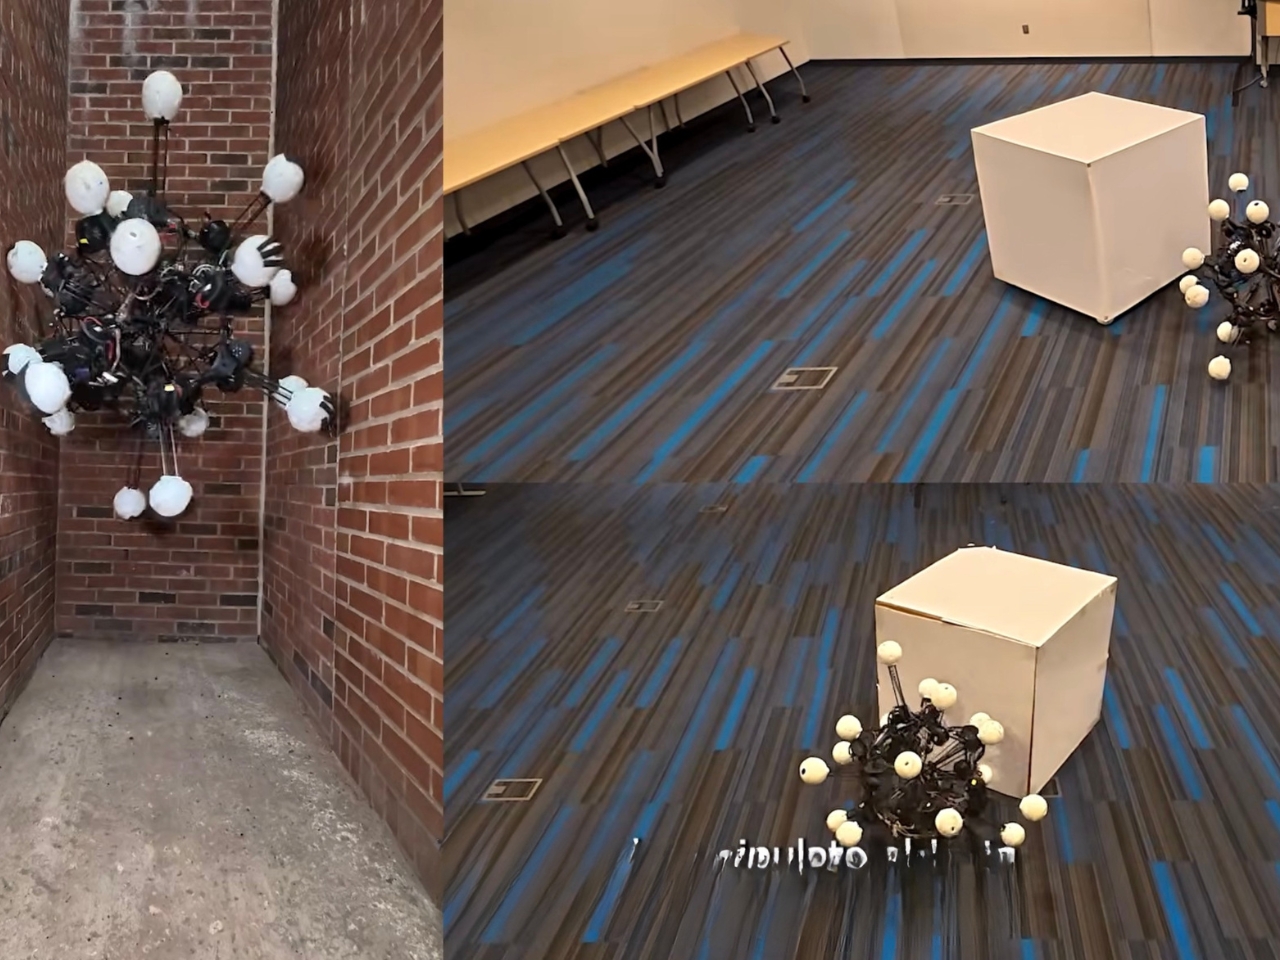
The moment you see Argus rolling across a college lawn, you feel a kind of awe that’s equal parts scientific admiration and mild existential discomfort. It doesn’t look like a robot. It doesn’t look like anything you’ve seen before, actually. It looks like a sea urchin crossed with a fever dream, or if you’ve spent any time on the internet in the last few years, it looks exactly like what happens when someone renders a biblically accurate angel and sends it out to navigate uneven terrain.

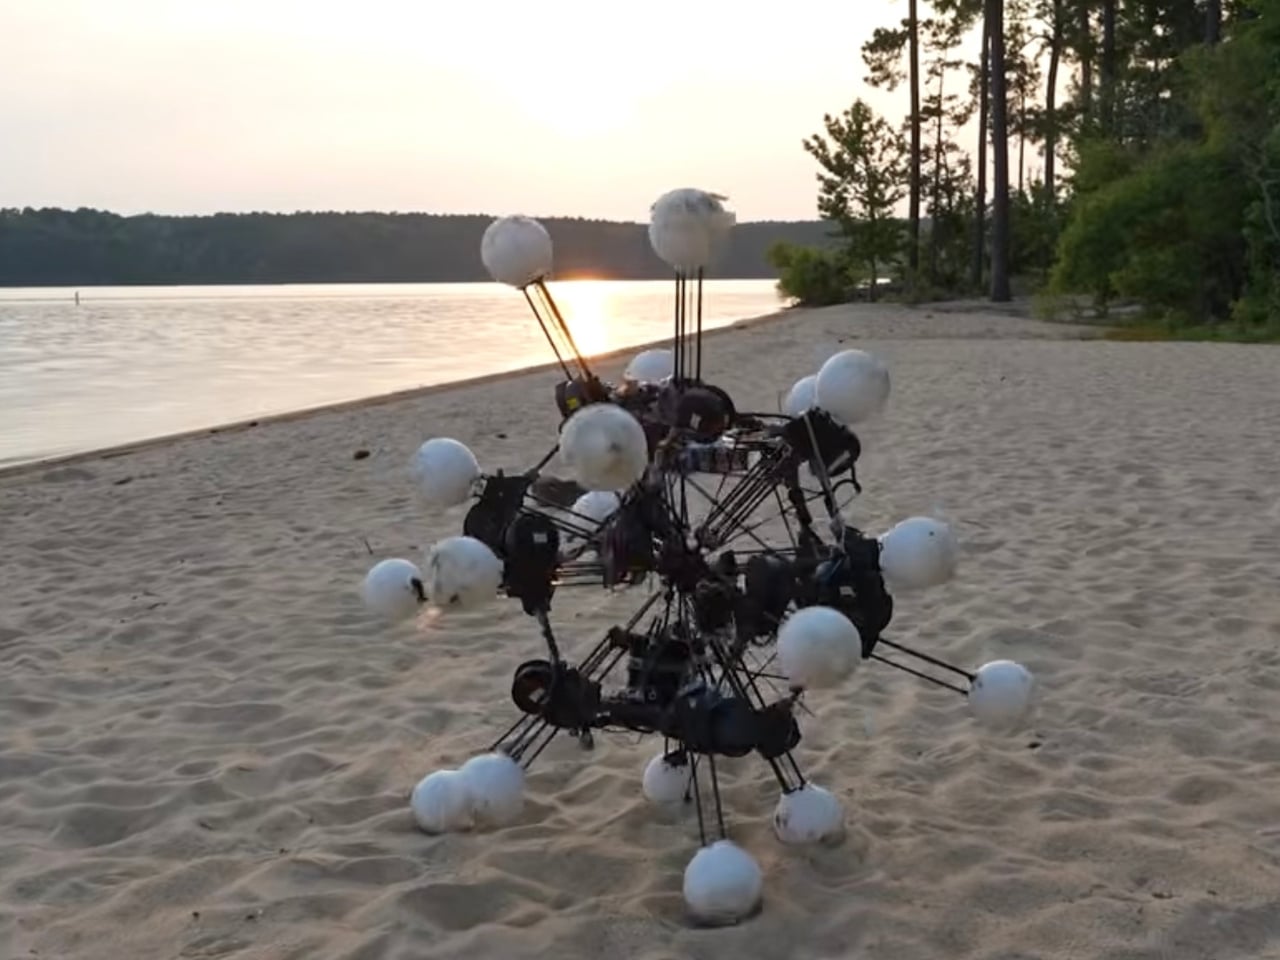
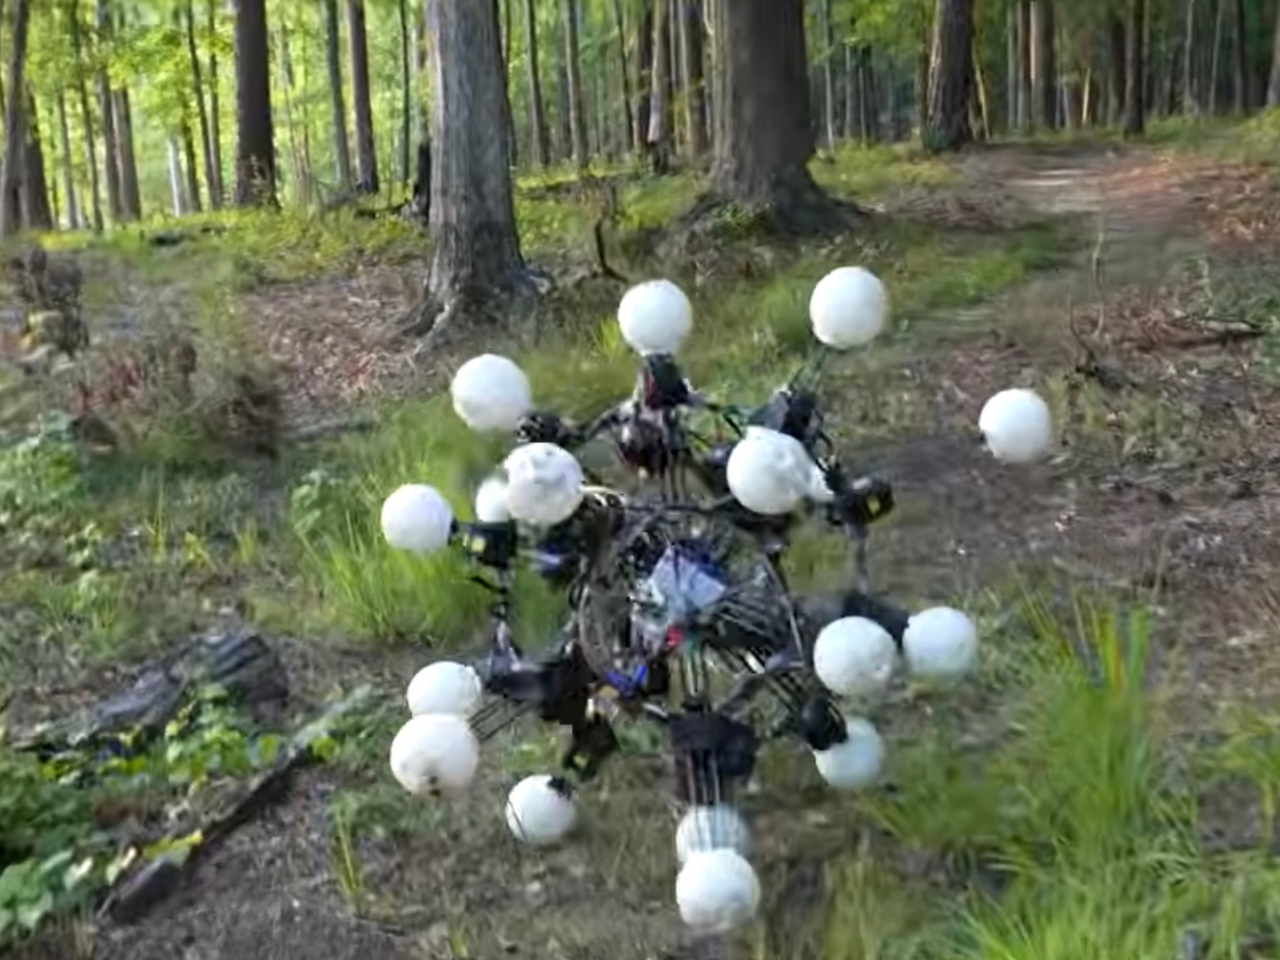
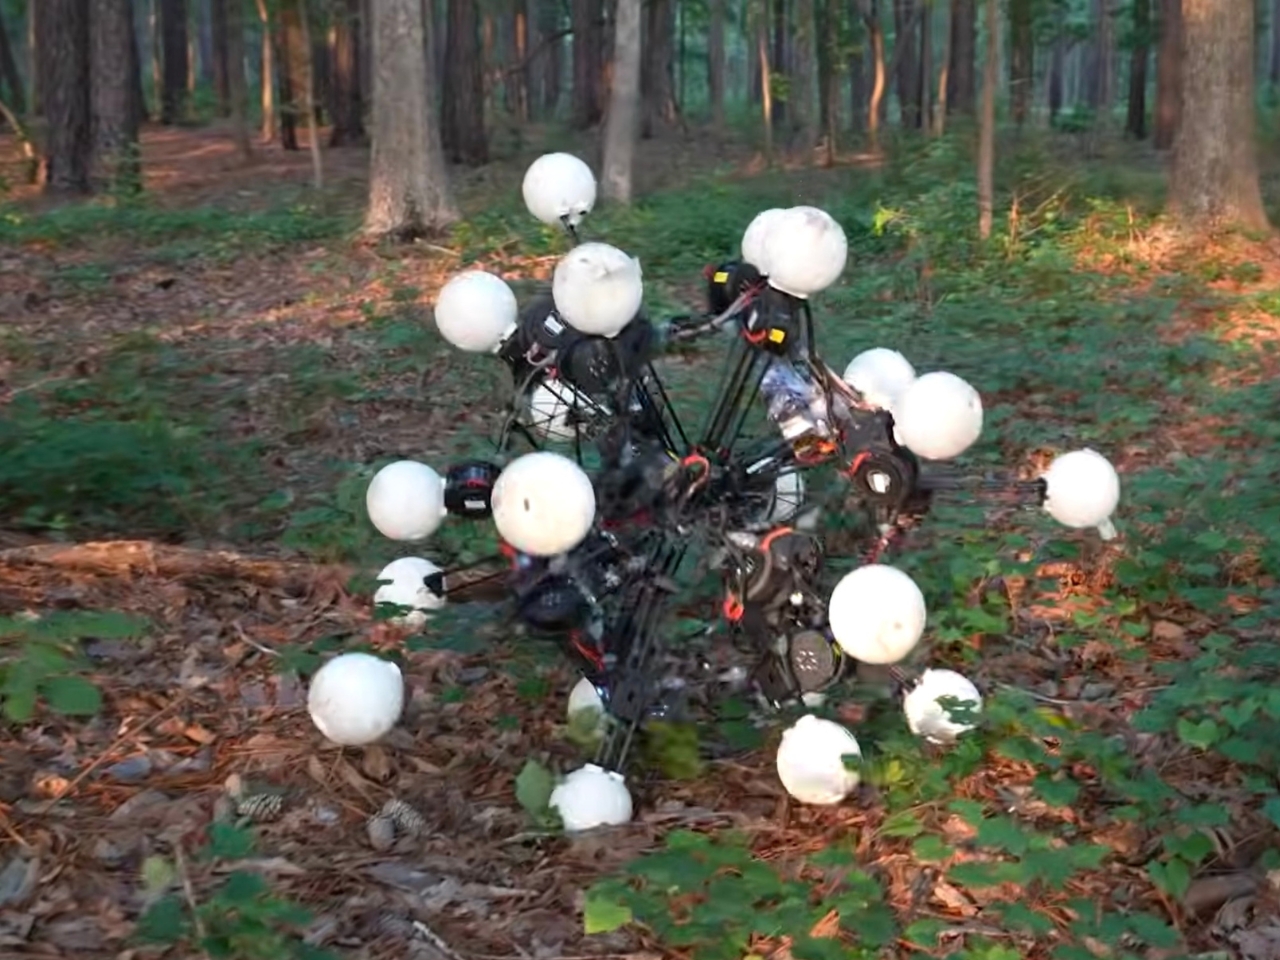
That’s not an exaggeration. The internet made the comparison almost immediately after Duke University’s General Robotics Lab unveiled Argus, and the parallel holds up. In the Book of Ezekiel, the ophanim, a type of divine being, are described as wheels covered in eyes, seeing in all directions simultaneously. Argus, named after the Greek mythological giant with a hundred eyes, does essentially the same thing, minus the divine mandate. It has 20 legs, each one telescoping and tipped with a camera, arranged at the vertices of a regular dodecahedron. No blind spots. No preferred orientation. No front or back.

Designer: Duke University General Robotics Lab

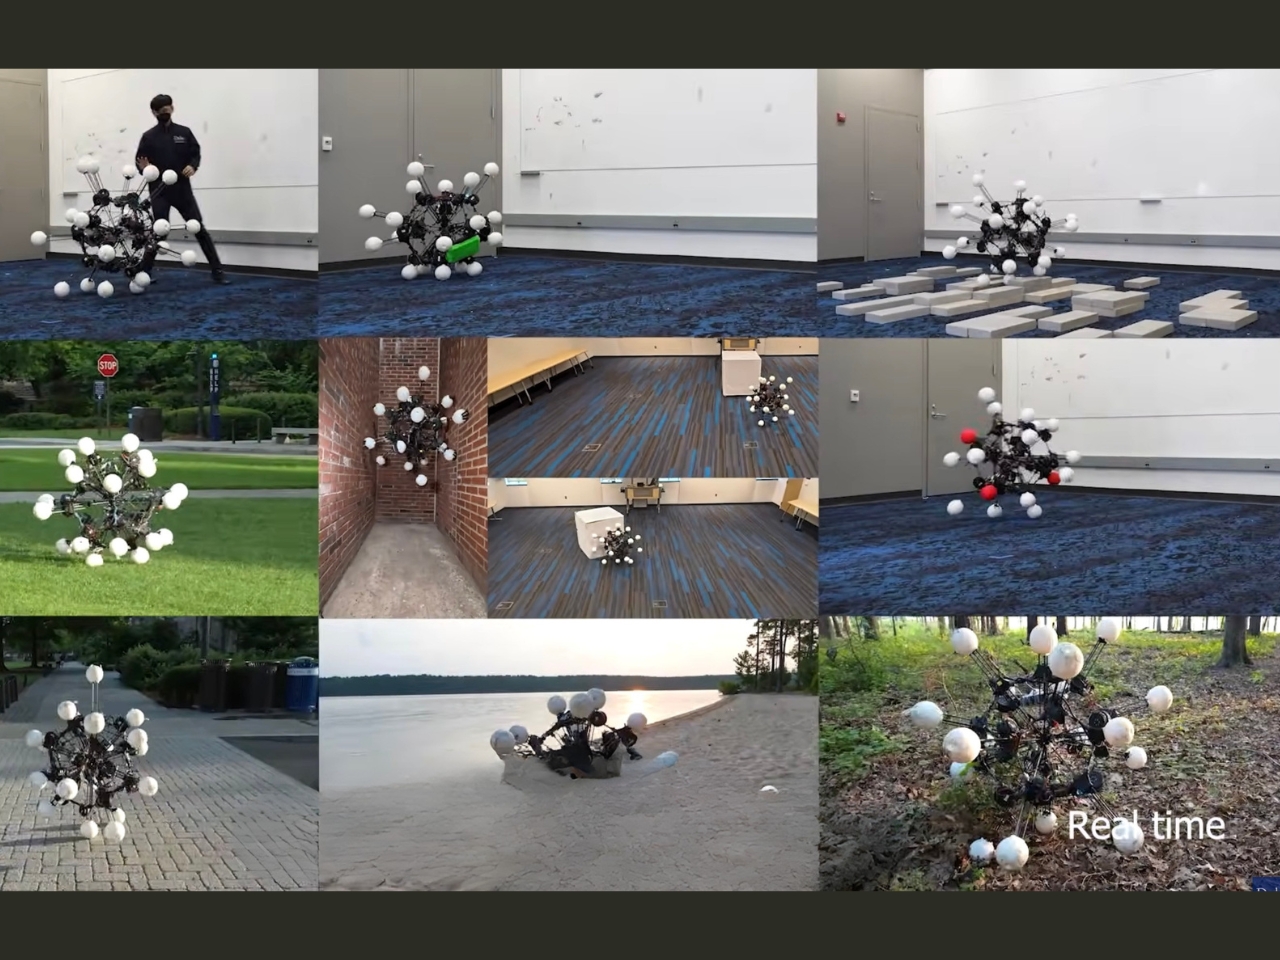
That last part is what keeps pulling me in, design-wise. We’ve spent decades building robots that mirror the logic of our own bodies: two legs, bilateral symmetry, a definitive forward direction. It made intuitive sense. We move front-to-back, so we assumed machines should too. Argus rejects that assumption entirely. The team at Duke built it around a principle they’re calling dynamic symmetry, which refers to how uniformly a robot can accelerate in any direction. Most robots are strongest and most efficient when moving the way they were designed to move. Argus has no such preference. It moves sideways, backward, forward, and diagonally with the same ease, which sounds like a minor technical distinction until you watch it roll through rough terrain, navigate around trees, and absorb collisions without losing its course. That’s when you realize how significant the gap is.

The design precedent here matters more than it might seem. Robotics has long borrowed from nature by mimicking the shapes that evolution produced: bipedal forms for humanoids, quadruped frames for terrain bots, insect geometries for swarm machines. But Argus is borrowing something different from nature. It’s borrowing from the radial logic of starfish and sea urchins, creatures that don’t have a front because every direction is equally valid. The Duke researchers describe Argus as an “existence proof,” a demonstration that a robot built for dynamic symmetry isn’t just theoretically interesting but practically deployable. Postdoctoral researcher Boxi Xia put it directly: “It produces a robot you can deploy in the wild, on uneven ground and in clutter, even in low-gravity settings.”

Low-gravity settings. That detail is doing a lot of quiet work in this conversation. The practical applications being discussed range from disaster response and search-and-rescue operations to planetary exploration, environments where the rules of conventional locomotion break down fast and all-directional agility becomes the difference between success and failure. A humanoid robot in a collapsed building still has to worry about which way it’s facing. Argus doesn’t.

I’ll admit the design is deeply strange to look at. It is not sleek. It is not elegant in any conventional sense. It doesn’t have the clean industrial confidence of Boston Dynamics’ machines or the deliberate anthropomorphism of recent humanoid models. It looks a little chaotic, frankly, like it was assembled by someone working from a very different set of aesthetic values, someone less interested in how the thing looks than in what the thing can do. And maybe that’s the point. Beauty in engineering doesn’t always wear the shape we expect. Sometimes it rolls across a lawn on 20 legs, sees absolutely everything, and changes the conversation entirely.

Argus is the kind of design that reminds you why robotics is still worth watching. Not because of what it looks like, but because of what it means for how we think about movement, perception, and the assumptions we’ve been quietly building into machines all along.

The post Argus Just Showed Up With 20 Eyes, 20 Legs, and No Rules first appeared on Yanko Design.
Michigan Built a $4,000 Robot You Can Rebuild from Scratch

The Ship of Theseus is one of philosophy’s most enduring thought experiments: if you replace every plank of a ship, one by one, is it still the same ship? Researchers at the University of Michigan decided that rather than debating the question in a classroom, they’d build it. And then they’d unbolt it, swap the legs, and build it into something else entirely.

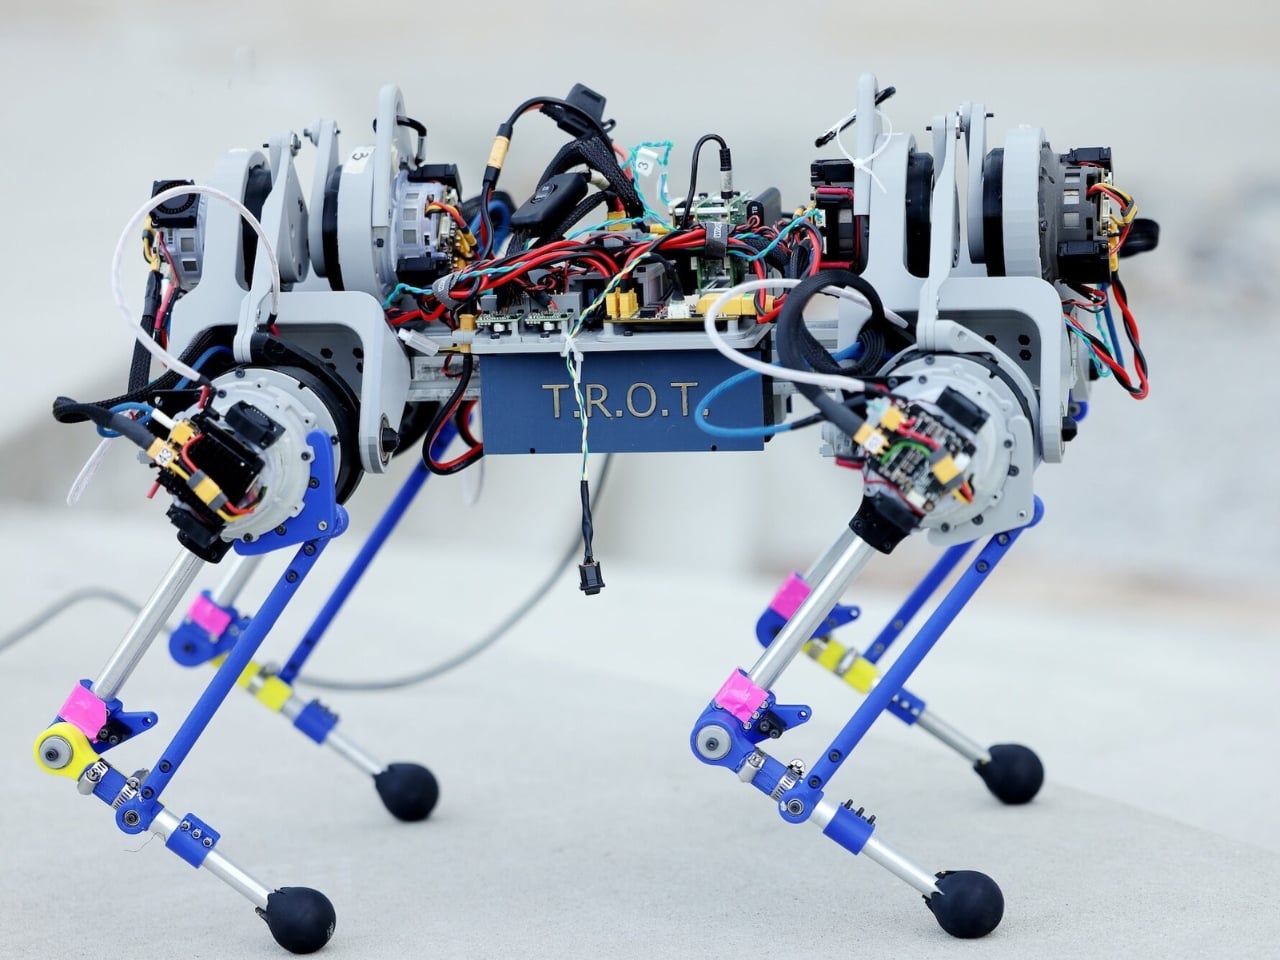
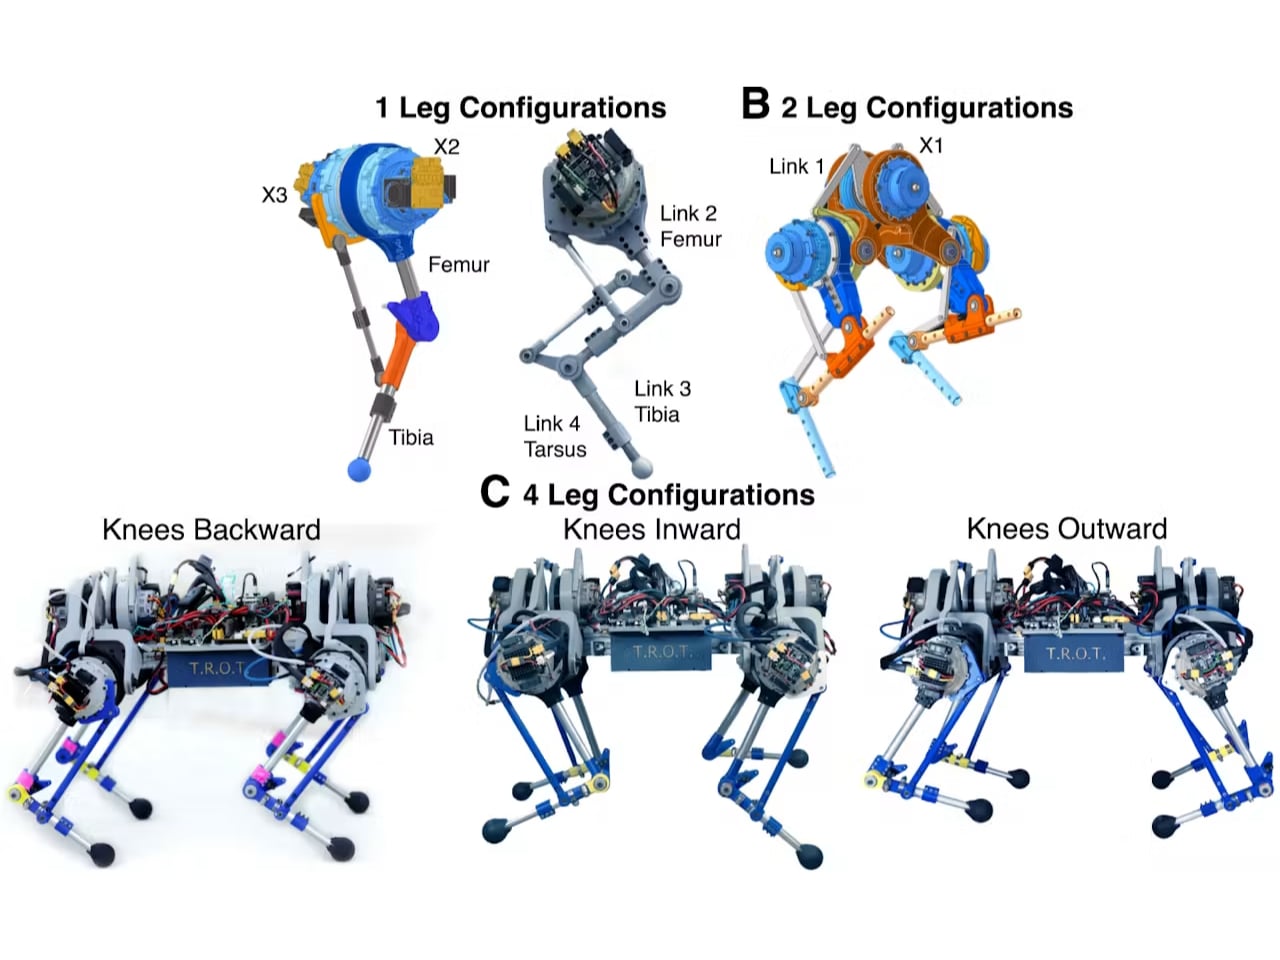
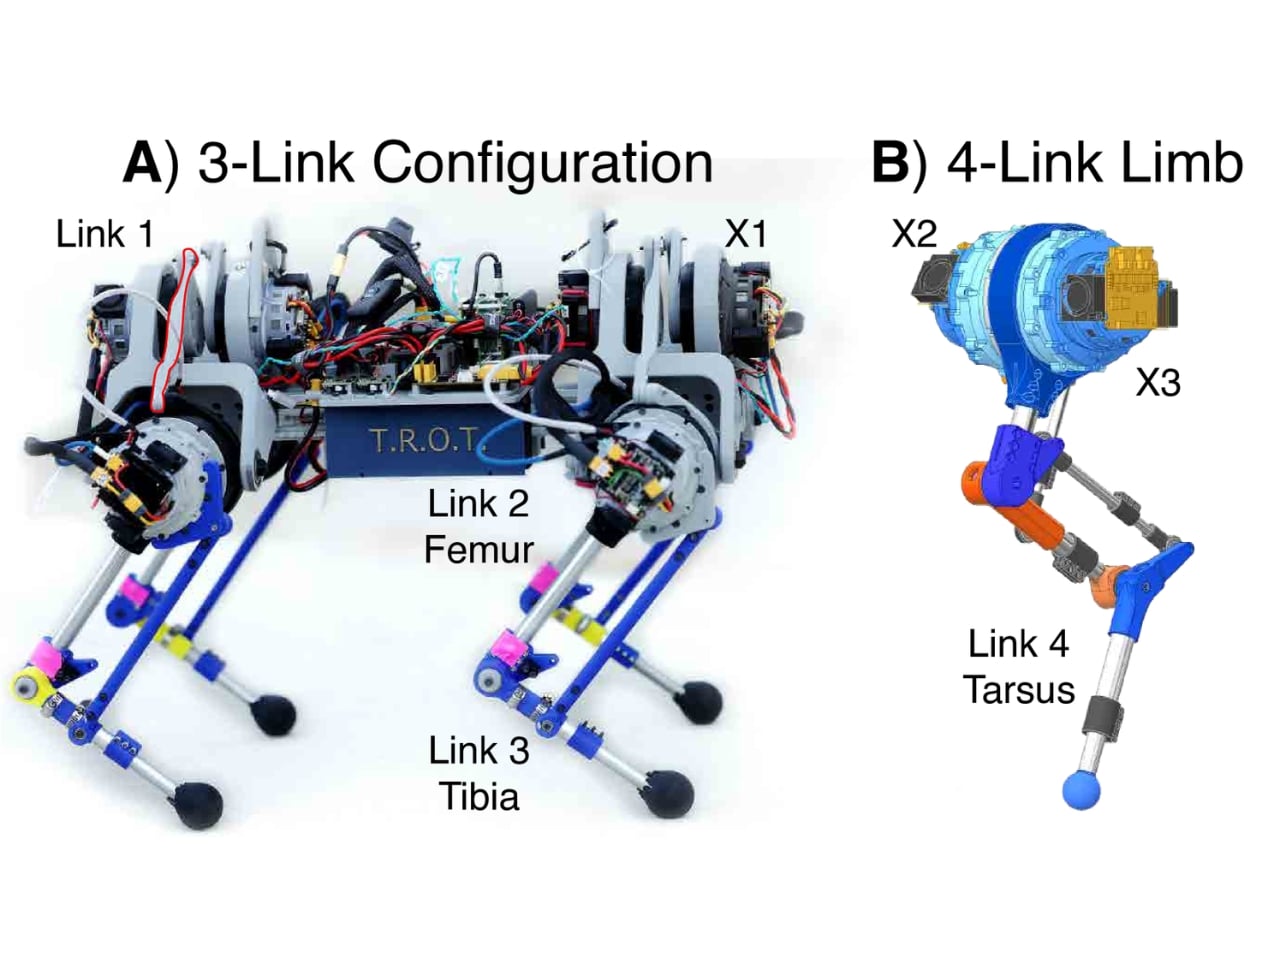
TROT (The Robot of Theseus) is a 10-kilogram, four-legged robot whose entire identity rests on impermanence. Its limbs unbolt. Its leg configurations swap between a two-link hopper, a three-link knee, and a three-link elbow orientation. You can rebuild the entire body plan over an afternoon and walk away with something that moves more like a gazelle than the dog-sized quadruped it started as. Same chassis. Same motors. About $4,000 in 3D-printed brackets and off-the-shelf parts. Its backdrivable motors even recover energy as they’re driven backward, mimicking the way tendons store and release force in a running animal.

Designer: University of Michigan

That $4,000 figure is worth sitting with. For context, Boston Dynamics’ Spot runs closer to $75,000. But TROT isn’t a budget Spot. It’s a different idea entirely. Where Spot is optimized for a fixed body plan and real-world deployment, TROT is optimized for being taken apart. It’s an experiment in the value of non-permanence, and that’s a much more interesting design brief than “make it do more things.”

The team, led by assistant professor Talia Moore, designed TROT to help biologists ask questions that physical animals can’t easily answer. What makes a cheetah fast isn’t just muscle. It’s also leg length, segment ratios, and joint geometry. Isolating those variables in a living animal is nearly impossible. But with TROT, you can swap out a femur extension, flip the knee orientation, and run the same locomotion test again the same afternoon, with consistent hardware and no ethical review board required. The robot has been used to compress roughly 60 million years of evolutionary locomotion variation into weeks of lab data. That’s the actual scientific utility, not a metaphor.

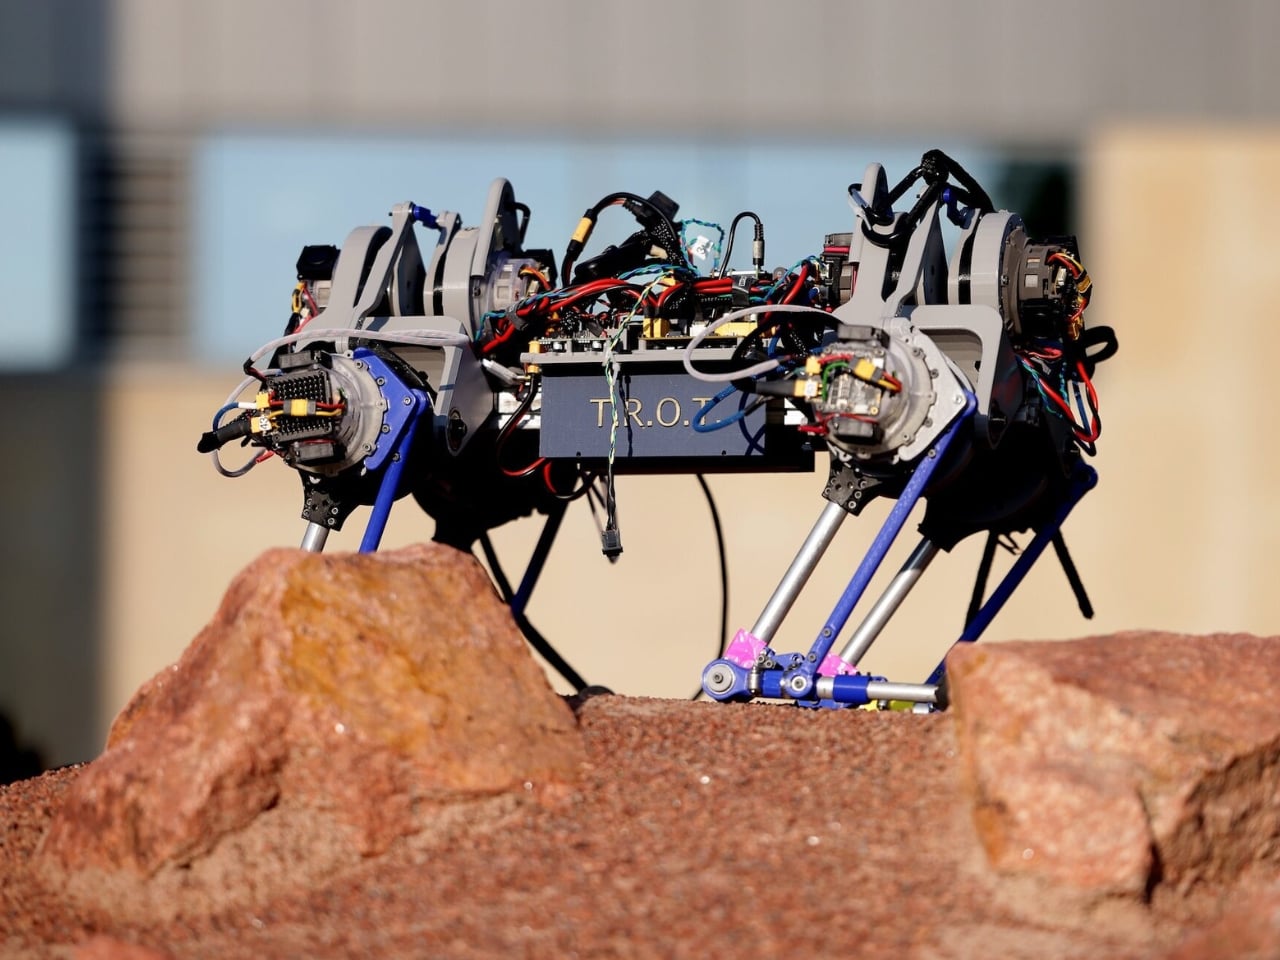
What tends to get under-reported in the science coverage is the design language itself. TROT’s visual aesthetic isn’t cleaned up or consumer-ready. You can see the 3D-print layer lines, the exposed wiring, the actuators bolted directly to the brackets. It looks like something built to be understood rather than admired, and I think that’s intentional. The exposed construction is a form of communication. It tells anyone looking at it: this is not precious. Change it. That’s a genuinely rare posture for a piece of research hardware.

The open-source dimension also runs deeper than posting a GitHub repo. The team released the CAD files, not just the control code. That’s a meaningful distinction. Code describes behavior; geometry describes intent. Sharing the brackets and print files means a biology lab at a smaller institution can reproduce TROT without needing a dedicated robotics engineering team. The knowledge transfer is embedded in the shape of the parts, and that changes who can participate in this kind of research.

TROT didn’t arrive alone. The first quarter of 2026 brought a quiet cluster of modular robotics research: Northwestern’s terrain-adapting writhers, a self-configuring quadruped paper in PNAS, and Nature’s SoftRafts, all landing within roughly eight weeks of each other. Robotin debuted a modular home robot ecosystem at CES 2026. Analysts have put the modular robotics market on track for $18.94 billion by 2029. None of this is coincidental. The field has been asking whether modularity in robotics could move past novelty. Q1 2026 looks like the answer arriving.

Most robots are designed to be finished. They ship in a fixed form, and any change is a cost: a repair, a retool, a failure. TROT is designed around the opposite logic. Its value increases each time a limb is swapped. Its usefulness is inseparable from its willingness to be reconfigured. Whether a robot that constantly changes its parts stays the same robot is still a philosophical question. Whether that approach produces better science, and better design thinking, is looking less and less like a question at all.

The post Michigan Built a $4,000 Robot You Can Rebuild from Scratch first appeared on Yanko Design.
Michigan Built a $4,000 Robot You Can Rebuild from Scratch

The Ship of Theseus is one of philosophy’s most enduring thought experiments: if you replace every plank of a ship, one by one, is it still the same ship? Researchers at the University of Michigan decided that rather than debating the question in a classroom, they’d build it. And then they’d unbolt it, swap the legs, and build it into something else entirely.

TROT (The Robot of Theseus) is a 10-kilogram, four-legged robot whose entire identity rests on impermanence. Its limbs unbolt. Its leg configurations swap between a two-link hopper, a three-link knee, and a three-link elbow orientation. You can rebuild the entire body plan over an afternoon and walk away with something that moves more like a gazelle than the dog-sized quadruped it started as. Same chassis. Same motors. About $4,000 in 3D-printed brackets and off-the-shelf parts. Its backdrivable motors even recover energy as they’re driven backward, mimicking the way tendons store and release force in a running animal.
Designer: University of Michigan

That $4,000 figure is worth sitting with. For context, Boston Dynamics’ Spot runs closer to $75,000. But TROT isn’t a budget Spot. It’s a different idea entirely. Where Spot is optimized for a fixed body plan and real-world deployment, TROT is optimized for being taken apart. It’s an experiment in the value of non-permanence, and that’s a much more interesting design brief than “make it do more things.”

The team, led by assistant professor Talia Moore, designed TROT to help biologists ask questions that physical animals can’t easily answer. What makes a cheetah fast isn’t just muscle. It’s also leg length, segment ratios, and joint geometry. Isolating those variables in a living animal is nearly impossible. But with TROT, you can swap out a femur extension, flip the knee orientation, and run the same locomotion test again the same afternoon, with consistent hardware and no ethical review board required. The robot has been used to compress roughly 60 million years of evolutionary locomotion variation into weeks of lab data. That’s the actual scientific utility, not a metaphor.

What tends to get under-reported in the science coverage is the design language itself. TROT’s visual aesthetic isn’t cleaned up or consumer-ready. You can see the 3D-print layer lines, the exposed wiring, the actuators bolted directly to the brackets. It looks like something built to be understood rather than admired, and I think that’s intentional. The exposed construction is a form of communication. It tells anyone looking at it: this is not precious. Change it. That’s a genuinely rare posture for a piece of research hardware.

The open-source dimension also runs deeper than posting a GitHub repo. The team released the CAD files, not just the control code. That’s a meaningful distinction. Code describes behavior; geometry describes intent. Sharing the brackets and print files means a biology lab at a smaller institution can reproduce TROT without needing a dedicated robotics engineering team. The knowledge transfer is embedded in the shape of the parts, and that changes who can participate in this kind of research.

TROT didn’t arrive alone. The first quarter of 2026 brought a quiet cluster of modular robotics research: Northwestern’s terrain-adapting writhers, a self-configuring quadruped paper in PNAS, and Nature’s SoftRafts, all landing within roughly eight weeks of each other. Robotin debuted a modular home robot ecosystem at CES 2026. Analysts have put the modular robotics market on track for $18.94 billion by 2029. None of this is coincidental. The field has been asking whether modularity in robotics could move past novelty. Q1 2026 looks like the answer arriving.

Most robots are designed to be finished. They ship in a fixed form, and any change is a cost: a repair, a retool, a failure. TROT is designed around the opposite logic. Its value increases each time a limb is swapped. Its usefulness is inseparable from its willingness to be reconfigured. Whether a robot that constantly changes its parts stays the same robot is still a philosophical question. Whether that approach produces better science, and better design thinking, is looking less and less like a question at all.

The post Michigan Built a $4,000 Robot You Can Rebuild from Scratch first appeared on Yanko Design.